[Imprint][Data Privacy Statement][E-Mail]
View long theorem info.
View the proof.
Back to main index.
View the specification.
View theorem base summary,
View theorem base listing,
the used properties by spec,
the dependency list,
the symbol table,
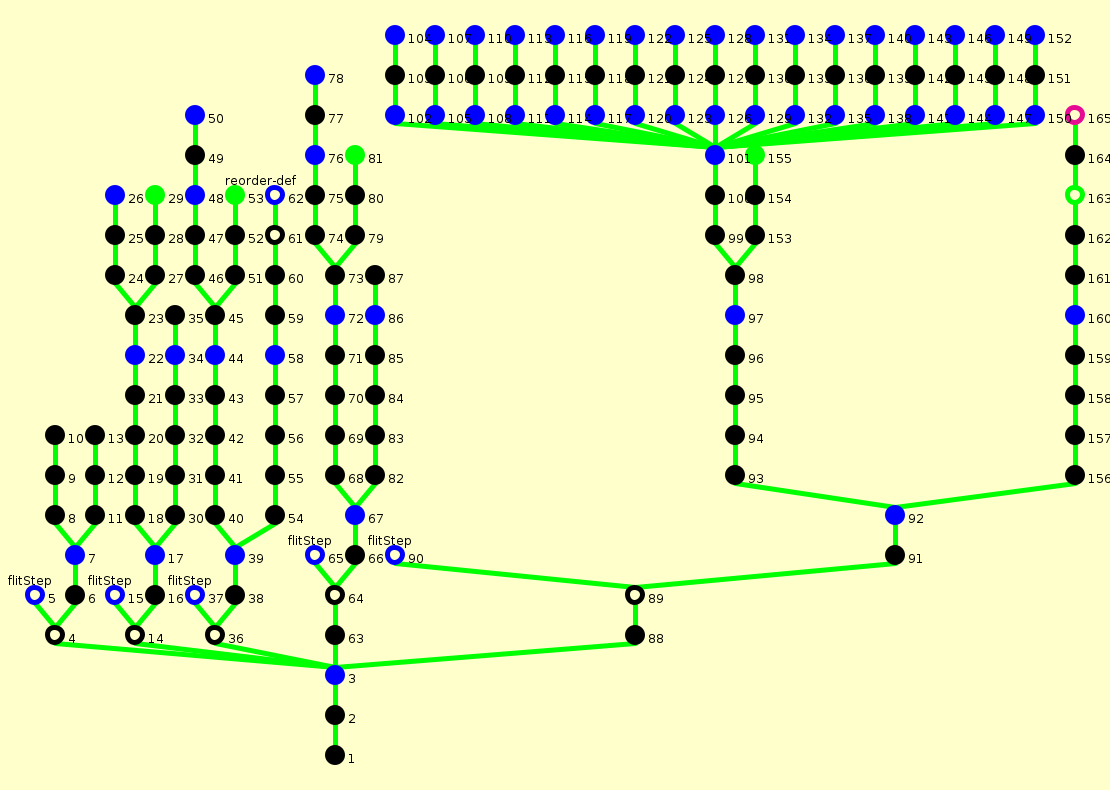
Proof step 1 from proof step-absstep-CRASH-globalCRASH (conclusion)
(back to tree)
| FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)),
abs(mkstate(gs, lsf, pcf), mkstate(ags, alsf, apcf))
⊦ ∃ ags0, alsf0, apcf0.
flitpscStep(mkstate(ags, alsf, apcf), globalPSCCRASH, mkstate(ags0, alsf0, apcf0)) ∧ abs(mkstate(gs0, lsf0, pcf0), mkstate(ags0, alsf0, apcf0)) |
System applied rule normalize
And obtained the following new goals
- Proof step 2:
FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), abs(mkstate(gs, lsf, pcf), mkstate(ags, alsf, apcf)),
flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0))
⊦ ∃ ags0, alsf0, apcf0.
flitpscStep(mkstate(ags, alsf, apcf), globalPSCCRASH, mkstate(ags0, alsf0, apcf0)) ∧ abs(mkstate(gs0, lsf0, pcf0), mkstate(ags0, alsf0, apcf0))
Rule argument
Additional information
Proof step 2 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), abs(mkstate(gs, lsf, pcf), mkstate(ags, alsf, apcf)),
flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0))
⊦ ∃ ags0, alsf0, apcf0.
flitpscStep(mkstate(ags, alsf, apcf), globalPSCCRASH, mkstate(ags0, alsf0, apcf0)) ∧ abs(mkstate(gs0, lsf0, pcf0), mkstate(ags0, alsf0, apcf0)) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 3:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ gs.pmem = gs0.pmem ∧ 0 = gs0.fctr(l) ∧ reorder(λ l. [], gs0.pq, gs0.rfo) ∧ ∅ = gs0.fwriters(l0)
∧ labs(gs0, lsf0(t), pcf0(t), mkFLITPSCgs(gs.pmem, λ l. [], λ l. 0, λ l. ∅, λ l. ∅), alsf(t), (apcf(t) = idle ⊃ idle;crashed))
Rule argument
Additional information
Used simplifier rules:
abs-def: ⊦ abs(mkstate(gs, lsf, pcf), mkstate(ags, alsf, apcf))
↔ gabs(gs, lsf, pcf, ags, alsf, apcf)
∧ (∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)));
gabs-def: ⊦ gabs(gs, lsf, pcf, ags, alsf, apcf)
↔ ags.mem = gs.pmem ∧ ags.ctr = gs.fctr ∧ reorder(ags.p, gs.pq, gs.rfo)
∧ ags.writers = gs.fwriters;
⊦ mkFLITPSCgs(mem, p, ctr, writers, writers0).writers = writers; (s)
⊦ mkFLITPSCgs(mem, p, ctr, writers, writers0).p = p; (s)
⊦ mkFLITPSCgs(mem, p, ctr, writers, writers0).ctr = ctr; (s)
⊦ mkFLITPSCgs(mem, p, ctr, writers, writers0).mem = mem; (s)
⊦ globalPSCCRASH ≠ globalPSCPERSIST_FO(l); (s)
⊦ globalPSCCRASH ≠ globalPSCPERSIST_W(l); (s)
⊦ ¬ pre(gs, ls, pc, globalPSCCRASH); (s)
⊦ lstep(gs, ls, pc, a, gs0, ls0, pc0)
↔ pre(gs, ls, pc, a) ∧ ls0 = lstepf(gs, ls, pc, a) ∧ gs0 = gstepf(gs, ls, pc, a)
∧ pc0 = pcstepf(gs, ls, pc, a); (s)
⊦ flitpscStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc.
lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls)
∧ pcf0 = pcf(t := pc))
∨ (∃ l.
a = globalPSCPERSIST_W(l) ∧ firstPersistW(gs.p(l)) < # gs.p(l)
∧ gs0
= (gs.mem:= gs.mem(l := gs.p(l)[firstPersistW(gs.p(l))].val))
.p:= gs.p(l := gs.p(l) -p firstPersistW(gs.p(l)))
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ l.
a = globalPSCPERSIST_FO(l)
∧ (∃ n. isPersistFO(n, gs.p(l)) ∧ gs0 = gs.p:= gs.p(l := gs.p(l) -p n))
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalPSCCRASH ∧ gs0 = mkFLITPSCgs(gs.mem, λ l. [], λ l. 0, λ l. ∅, λ l. ∅)
∧ lsf0 = lsf ∧ pcf0 = (λ t. (pcf(t) = idle ⊃ idle;crashed)); (s)
Proof step 3 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ gs.pmem = gs0.pmem ∧ 0 = gs0.fctr(l) ∧ reorder(λ l. [], gs0.pq, gs0.rfo) ∧ ∅ = gs0.fwriters(l0)
∧ labs(gs0, lsf0(t), pcf0(t), mkFLITPSCgs(gs.pmem, λ l. [], λ l. 0, λ l. ∅, λ l. ∅), alsf(t), (apcf(t) = idle ⊃ idle;crashed)) |
Heuristic if-then-else split applied rule case distinction
And obtained the following new goals
- Proof step 4:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.pmem ≠ gs0.pmem, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 14:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, 0 ≠ gs0.fctr(l), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 36:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], gs0.pq, gs0.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 63:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, ∅ ≠ gs0.fwriters(l0), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 88:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)), reorder(ags.p, gs.pq, gs.rfo),
¬ labs(gs0, lsf0(t), pcf0(t), mkFLITPSCgs(gs.pmem, λ l. [], λ l. 0, λ l. ∅, λ l. ∅), alsf(t), (apcf(t) = idle ⊃ idle;crashed)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: right 1
Additional information
Proof step 4 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.pmem ≠ gs0.pmem, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 5:
⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l))) ∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
- Proof step 6:
(∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), globalCRASH, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
globalCRASH = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
globalCRASH = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
globalCRASH = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf
∧ pcf0 = pcf)
∨ globalCRASH = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.pmem ≠ gs0.pmem, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
spec: FLIT, name:flitStep,
seq:⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc.
lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls)
∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v)
∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0
= ( gs
.pq:= gs.pq
(gs.bq(tid).head.l
:= gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid)
))
.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l))
∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo;
PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid)
∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0
= (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val))
.pq:= gs.pq(loc := gs.pq(loc).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?)
∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters,
freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs
:= ( ( (((gs.pq:= pq).fctr:= fctr).bq:= bq)
.fwriters:= fwriters)
.freaders:= freaders)
.rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
subst:[lsf, gs, lsf0, a, pcf, pcf0, gs0] → [lsf, gs, lsf0, globalCRASH, pcf, pcf0, gs0],
<all paths>
Additional information
Used terms: pcf0, globalCRASH, lsf, gs0, pcf, lsf0, gs
Proof step 5 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l))) ∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf) |
A spec-lemma
Proof step 6 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), globalCRASH, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
globalCRASH = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
globalCRASH = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
globalCRASH = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf
∧ pcf0 = pcf)
∨ globalCRASH = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.pmem ≠ gs0.pmem, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 7:
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)) ∧ n < # gs.bq(t) ∧ isPropFO(n, l, gs.bq(t))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.pmem ≠ gs0.pmem, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ globalPERSIST_FO(loc); (s)
⊦ globalCRASH ≠ globalPERSIST_W(loc); (s)
⊦ globalCRASH ≠ propSF(t); (s)
⊦ doWrite(t, loc, v) ≠ globalCRASH; (s)
⊦ ¬ pre(gs, ls, pc, globalCRASH); (s)
⊦ lstep(gs, ls, pc, a, gs0, ls0, pc0)
↔ pre(gs, ls, pc, a) ∧ ls0 = lstepf(gs, ls, pc, a) ∧ gs0 = gstepf(gs, ls, pc, a)
∧ pc0 = pcstepf(gs, ls, pc, a); (s)
Proof step 7 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)) ∧ n < # gs.bq(t) ∧ isPropFO(n, l, gs.bq(t))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.pmem ≠ gs0.pmem, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic dl case distinction applied rule case distinction
And obtained the following new goals
- Proof step 8:
⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
gs.pmem ≠ gs0.pmem, n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 11:
⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.pmem ≠ gs0.pmem, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Proof step 8 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
gs.pmem ≠ gs0.pmem, n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 9:
⟨PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, gs.pmem ≠ gs0.pmem, n < # gs.bq(t),
FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 9 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, gs.pmem ≠ gs0.pmem, n < # gs.bq(t),
FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic split applied rule split left
And obtained the following new goals
- Proof step 10:
⟨gs := ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
⟨PROP_FO(t, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
fwriters = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, gs.pmem ≠ gs0.pmem,
n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Proof step 10 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨gs := ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
⟨PROP_FO(t, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
fwriters = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, gs.pmem ≠ gs0.pmem,
n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And closed the goal!
Rule argument
Additional information
Used simplifier rules:
⊦ (gs.rfo:= bq0).pmem = gs.pmem; (s)
⊦ (gs.bq:= bq).pmem = gs.pmem; (s)
⊦ (gs.pq:= pq).pmem = gs.pmem; (s)
Proof step 11 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.pmem ≠ gs0.pmem, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 12:
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, gs.pmem ≠ gs0.pmem, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 12 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, gs.pmem ≠ gs0.pmem, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic split applied rule split left
And obtained the following new goals
- Proof step 13:
⟨gs := (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf1),
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, gs.pmem ≠ gs0.pmem, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Proof step 13 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨gs := (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf1),
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, gs.pmem ≠ gs0.pmem, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And closed the goal!
Rule argument
Additional information
Used simplifier rules:
⊦ (gs.rfo:= bq0).pmem = gs.pmem; (s)
⊦ (gs.freaders:= fwriters0).pmem = gs.pmem; (s)
⊦ (gs.fwriters:= fwriters).pmem = gs.pmem; (s)
⊦ (gs.bq:= bq).pmem = gs.pmem; (s)
⊦ (gs.fctr:= fctr).pmem = gs.pmem; (s)
⊦ (gs.pq:= pq).pmem = gs.pmem; (s)
Proof step 14 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, 0 ≠ gs0.fctr(l), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 15:
⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l))) ∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
- Proof step 16:
(∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), globalCRASH, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
globalCRASH = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
globalCRASH = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
globalCRASH = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf
∧ pcf0 = pcf)
∨ globalCRASH = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, 0 ≠ gs0.fctr(l), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
spec: FLIT, name:flitStep,
seq:⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc.
lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls)
∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v)
∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0
= ( gs
.pq:= gs.pq
(gs.bq(tid).head.l
:= gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid)
))
.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l))
∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo;
PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid)
∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0
= (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val))
.pq:= gs.pq(loc := gs.pq(loc).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?)
∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters,
freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs
:= ( ( (((gs.pq:= pq).fctr:= fctr).bq:= bq)
.fwriters:= fwriters)
.freaders:= freaders)
.rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
subst:[lsf, gs, lsf0, a, pcf, pcf0, gs0] → [lsf, gs, lsf0, globalCRASH, pcf, pcf0, gs0],
<all paths>
Additional information
Used terms: pcf0, globalCRASH, lsf, gs0, pcf, lsf0, gs
Proof step 15 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l))) ∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf) |
A spec-lemma
Proof step 16 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), globalCRASH, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
globalCRASH = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
globalCRASH = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
globalCRASH = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf
∧ pcf0 = pcf)
∨ globalCRASH = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, 0 ≠ gs0.fctr(l), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 17:
globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)) ∧ n < # gs.bq(t) ∧ isPropFO(n, l0, gs.bq(t))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t, l0, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, 0 ≠ gs0.fctr(l), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ globalPERSIST_FO(loc); (s)
⊦ globalCRASH ≠ globalPERSIST_W(loc); (s)
⊦ globalCRASH ≠ propSF(t); (s)
⊦ doWrite(t, loc, v) ≠ globalCRASH; (s)
⊦ ¬ pre(gs, ls, pc, globalCRASH); (s)
⊦ lstep(gs, ls, pc, a, gs0, ls0, pc0)
↔ pre(gs, ls, pc, a) ∧ ls0 = lstepf(gs, ls, pc, a) ∧ gs0 = gstepf(gs, ls, pc, a)
∧ pc0 = pcstepf(gs, ls, pc, a); (s)
Proof step 17 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)) ∧ n < # gs.bq(t) ∧ isPropFO(n, l0, gs.bq(t))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t, l0, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, 0 ≠ gs0.fctr(l), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic dl case distinction applied rule case distinction
And obtained the following new goals
- Proof step 18:
⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t, l0, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)),
0 ≠ gs0.fctr(l), n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l0, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 30:
⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, 0 ≠ gs0.fctr(l), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Proof step 18 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t, l0, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)),
0 ≠ gs0.fctr(l), n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l0, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 19:
⟨PROP_FO(t, l0, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)), pq = gs.pq, rfo = gs.rfo, 0 ≠ gs0.fctr(l), n < # gs.bq(t),
FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 19 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨PROP_FO(t, l0, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)), pq = gs.pq, rfo = gs.rfo, 0 ≠ gs0.fctr(l), n < # gs.bq(t),
FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic split applied rule split left
And obtained the following new goals
- Proof step 20:
⟨gs := ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
⟨PROP_FO(t, l0, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, fwriters = gs.fwriters, globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)), pq = gs.pq, rfo = gs.rfo,
0 ≠ gs0.fctr(l), n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l0, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Proof step 20 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨gs := ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
⟨PROP_FO(t, l0, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, fwriters = gs.fwriters, globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)), pq = gs.pq, rfo = gs.rfo,
0 ≠ gs0.fctr(l), n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l0, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 21:
⟨PROP_FO(t, l0, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, fwriters = gs.fwriters, globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)),
gs0 = ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf0 = lsf, pcf0 = pcf, pq = gs.pq, rfo = gs.rfo, 0 ≠ gs0.fctr(l), n < # gs.bq(t),
FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 21 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨PROP_FO(t, l0, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, fwriters = gs.fwriters, globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)),
gs0 = ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf0 = lsf, pcf0 = pcf, pq = gs.pq, rfo = gs.rfo, 0 ≠ gs0.fctr(l), n < # gs.bq(t),
FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 22:
⟨PROP_FO(t, l0, gs.fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)), pq = gs.pq, rfo = gs.rfo, gs.bq(t) ≠ [], 0 ≠ gs.fctr(l),
n < # gs.bq(t), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ # x = 0 ↔ x = []; (s)
f: ⊦ m < n → n ≠ 0; (forward) from specification nat-basic
⊦ (gs.pq:= pq).fctr = gs.fctr; (s)
⊦ (gs.bq:= bq).fctr = gs.fctr; (s)
⊦ (gs.rfo:= bq0).fctr = gs.fctr; (s)
Proof step 22 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨PROP_FO(t, l0, gs.fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)), pq = gs.pq, rfo = gs.rfo, gs.bq(t) ≠ [], 0 ≠ gs.fctr(l),
n < # gs.bq(t), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic unfold applied rule call left
And obtained the following new goals
- Proof step 23:
⟨choose n
with n < # bq(tid) ∧ isPropFO(n, l, bq(tid))
in pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)
ifnone skip⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)), l = l0, pq = gs.pq, rfo = gs.rfo, tid = t, gs.bq(t) ≠ [],
0 ≠ gs.fctr(l1), n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Used simplifier rules:
decl: PROP_FO(tid, l, fwriters; pq, bq, rfo)
{choose n
with n < # bq(tid) ∧ isPropFO(n, l, bq(tid))
in pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n,
rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)
ifnone skip
};
Proof step 23 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨choose n
with n < # bq(tid) ∧ isPropFO(n, l, bq(tid))
in pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)
ifnone skip⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)), l = l0, pq = gs.pq, rfo = gs.rfo, tid = t, gs.bq(t) ≠ [],
0 ≠ gs.fctr(l1), n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule choose left
And obtained the following new goals
- Proof step 24:
⟨pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)), l = l0, pq = gs.pq, rfo = gs.rfo, tid = t, gs.bq(t) ≠ [],
0 ≠ gs.fctr(l1), n0 < # gs.bq(t), n < # bq(tid), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l0, gs.bq(t)), isPropFO(n, l, bq(tid)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 27:
⟨skip⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)), l = l0, pq = gs.pq, rfo = gs.rfo, tid = t, gs.bq(t) ≠ [],
0 ≠ gs.fctr(l1), n < # gs.bq(t), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid)))
⊦
Rule argument
Additional information
Proof step 24 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)), l = l0, pq = gs.pq, rfo = gs.rfo, tid = t, gs.bq(t) ≠ [],
0 ≠ gs.fctr(l1), n0 < # gs.bq(t), n < # bq(tid), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l0, gs.bq(t)), isPropFO(n, l, bq(tid)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 25:
pq(l := pq(l) + FO(tid)) = pq0, bq(tid := bq(tid) -p n) = bq0, rfo(tid := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)) = rfo0, ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)), l = l0, pq = gs.pq, rfo = gs.rfo, tid = t, gs.bq(t) ≠ [],
0 ≠ gs.fctr(l1), n < # bq(tid), n0 < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, bq(tid)), isPropFO(n0, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 25 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| pq(l := pq(l) + FO(tid)) = pq0, bq(tid := bq(tid) -p n) = bq0, rfo(tid := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)) = rfo0, ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)), l = l0, pq = gs.pq, rfo = gs.rfo, tid = t, gs.bq(t) ≠ [],
0 ≠ gs.fctr(l1), n < # bq(tid), n0 < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, bq(tid)), isPropFO(n0, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 26:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)),
gs.bq(t) ≠ [], 0 ≠ gs.fctr(l1), n0 < # gs.bq(t), n < # gs.bq(t), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l0 := gs.pq(l0) + FO(t) ')).bq:= gs.bq(t := gs.bq(t) -p n)).rfo:= gs.rfo(t := (t ∈ gs.fwriters(l0) ⊃ gs.rfo(t);gs.rfo(t) -p n)), lsf,
pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l0, gs.bq(t)), isPropFO(n, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ x + a = x + a '; (s)
Proof step 26 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)),
gs.bq(t) ≠ [], 0 ≠ gs.fctr(l1), n0 < # gs.bq(t), n < # gs.bq(t), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l0 := gs.pq(l0) + FO(t) ')).bq:= gs.bq(t := gs.bq(t) -p n)).rfo:= gs.rfo(t := (t ∈ gs.fwriters(l0) ⊃ gs.rfo(t);gs.rfo(t) -p n)), lsf,
pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l0, gs.bq(t)), isPropFO(n, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t, l0, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t, l0, gs.fwriters)
Proof step 27 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨skip⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)), l = l0, pq = gs.pq, rfo = gs.rfo, tid = t, gs.bq(t) ≠ [],
0 ≠ gs.fctr(l1), n < # gs.bq(t), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid)))
⊦ |
Heuristic symbolic execution applied rule skip left
And obtained the following new goals
- Proof step 28:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, bq = bq0, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)), l = l0, pq = gs.pq, pq = pq0, rfo = gs.rfo, rfo = rfo0, tid = t,
gs.bq(t) ≠ [], 0 ≠ gs.fctr(l1), n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid))),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 28 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, bq = bq0, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)), l = l0, pq = gs.pq, pq = pq0, rfo = gs.rfo, rfo = rfo0, tid = t,
gs.bq(t) ≠ [], 0 ≠ gs.fctr(l1), n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid))),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 29:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)),
gs.bq(t) ≠ [], 0 ≠ gs.fctr(l1), n < # gs.bq(t), FLITInv(((gs.pq:= gs.pq).bq:= gs.bq).rfo:= gs.rfo, lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ n0. ¬ n0 < # gs.bq(t) ∨ ¬ isPropFO(n0, l0, gs.bq(t))
⊦
Rule argument
Additional information
Proof step 29 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l0, gs.fwriters) ⊃ doWriteFO(t, l0);propFO(t, l0)),
gs.bq(t) ≠ [], 0 ≠ gs.fctr(l1), n < # gs.bq(t), FLITInv(((gs.pq:= gs.pq).bq:= gs.bq).rfo:= gs.rfo, lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l0, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ n0. ¬ n0 < # gs.bq(t) ∨ ¬ isPropFO(n0, l0, gs.bq(t))
⊦ |
Heuristic quantifier closing applied rule all left
And closed the goal!
Rule argument
pos: left 14 terms: n
Additional information
Used terms: n
Proof step 30 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, 0 ≠ gs0.fctr(l), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 31:
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, 0 ≠ gs0.fctr(l), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 31 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, 0 ≠ gs0.fctr(l), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic split applied rule split left
And obtained the following new goals
- Proof step 32:
⟨gs := (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf1),
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, 0 ≠ gs0.fctr(l), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Proof step 32 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨gs := (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf1),
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, 0 ≠ gs0.fctr(l), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 33:
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
gs0 = (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf0 = lsf, pcf0 = pcf1, pq = gs.pq,
rfo = gs.rfo, 0 ≠ gs0.fctr(l), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 33 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
gs0 = (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf0 = lsf, pcf0 = pcf1, pq = gs.pq,
rfo = gs.rfo, 0 ≠ gs0.fctr(l), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 34:
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, 0 ≠ fctr0(l), FLITInv(gs, lsf, pcf),
FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ (gs.fctr:= fctr).fctr = fctr; (s)
⊦ (gs.bq:= bq).fctr = gs.fctr; (s)
⊦ (gs.fwriters:= fwriters).fctr = gs.fctr; (s)
⊦ (gs.freaders:= fwriters0).fctr = gs.fctr; (s)
⊦ (gs.rfo:= bq0).fctr = gs.fctr; (s)
Proof step 34 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, 0 ≠ fctr0(l), FLITInv(gs, lsf, pcf),
FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic unfold applied rule call left
And obtained the following new goals
- Proof step 35:
⟨pcf := λ t. (pcf(t) = idle ⊃ idle;crashed), pq := λ l. [], fctr := λ l. 0, freaders := λ l. ∅, fwriters := λ l. ∅, bq := λ t. [], rfo := λ t. []⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, 0 ≠ fctr0(l),
FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Used simplifier rules:
decl: CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)
{pcf := λ t. (pcf(t) = idle ⊃ idle;crashed), pq := λ l. [], fctr := λ l. 0,
freaders := λ l. ∅, fwriters := λ l. ∅, bq := λ t. [], rfo := λ t. []
};
Proof step 35 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨pcf := λ t. (pcf(t) = idle ⊃ idle;crashed), pq := λ l. [], fctr := λ l. 0, freaders := λ l. ∅, fwriters := λ l. ∅, bq := λ t. [], rfo := λ t. []⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, 0 ≠ fctr0(l),
FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And closed the goal!
Rule argument
Additional information
Proof step 36 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], gs0.pq, gs0.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 37:
⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l))) ∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
- Proof step 38:
(∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), globalCRASH, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
globalCRASH = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
globalCRASH = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
globalCRASH = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf
∧ pcf0 = pcf)
∨ globalCRASH = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
spec: FLIT, name:flitStep,
seq:⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc.
lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls)
∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v)
∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0
= ( gs
.pq:= gs.pq
(gs.bq(tid).head.l
:= gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid)
))
.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l))
∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo;
PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid)
∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0
= (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val))
.pq:= gs.pq(loc := gs.pq(loc).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?)
∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters,
freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs
:= ( ( (((gs.pq:= pq).fctr:= fctr).bq:= bq)
.fwriters:= fwriters)
.freaders:= freaders)
.rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
subst:[lsf, gs, lsf0, a, pcf, pcf0, gs0] → [lsf, gs, lsf0, globalCRASH, pcf, pcf0, gs0],
<all paths>
Additional information
Used terms: pcf0, globalCRASH, lsf, gs0, pcf, lsf0, gs
Proof step 37 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l))) ∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf) |
A spec-lemma
Proof step 38 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), globalCRASH, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
globalCRASH = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
globalCRASH = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
globalCRASH = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf
∧ pcf0 = pcf)
∨ globalCRASH = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 39:
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)) ∧ n < # gs.bq(t) ∧ isPropFO(n, l, gs.bq(t))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ globalPERSIST_FO(loc); (s)
⊦ globalCRASH ≠ globalPERSIST_W(loc); (s)
⊦ globalCRASH ≠ propSF(t); (s)
⊦ doWrite(t, loc, v) ≠ globalCRASH; (s)
⊦ ¬ pre(gs, ls, pc, globalCRASH); (s)
⊦ lstep(gs, ls, pc, a, gs0, ls0, pc0)
↔ pre(gs, ls, pc, a) ∧ ls0 = lstepf(gs, ls, pc, a) ∧ gs0 = gstepf(gs, ls, pc, a)
∧ pc0 = pcstepf(gs, ls, pc, a); (s)
Proof step 39 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)) ∧ n < # gs.bq(t) ∧ isPropFO(n, l, gs.bq(t))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic dl case distinction applied rule case distinction
And obtained the following new goals
- Proof step 40:
⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 54:
⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Proof step 40 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 41:
⟨PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, n < # gs.bq(t), FLITInv(gs0, lsf0, pcf0),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], gs0.pq, gs0.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 41 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, n < # gs.bq(t), FLITInv(gs0, lsf0, pcf0),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], gs0.pq, gs0.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic split applied rule split left
And obtained the following new goals
- Proof step 42:
⟨gs := ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
⟨PROP_FO(t, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
fwriters = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, n < # gs.bq(t),
FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Proof step 42 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨gs := ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
⟨PROP_FO(t, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
fwriters = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, n < # gs.bq(t),
FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 43:
⟨PROP_FO(t, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
fwriters = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), gs0 = ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0,
lsf0 = lsf, pcf0 = pcf, pq = gs.pq, rfo = gs.rfo, n < # gs.bq(t), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 43 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨PROP_FO(t, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
fwriters = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), gs0 = ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0,
lsf0 = lsf, pcf0 = pcf, pq = gs.pq, rfo = gs.rfo, n < # gs.bq(t), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 44:
⟨PROP_FO(t, l, gs.fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, gs.bq(t) ≠ [],
n < # gs.bq(t), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ # x = 0 ↔ x = []; (s)
f: ⊦ m < n → n ≠ 0; (forward) from specification nat-basic
⊦ (gs.rfo:= bq0).rfo = bq0; (s)
⊦ (gs.pq:= pq).pq = pq; (s)
⊦ (gs.bq:= bq).pq = gs.pq; (s)
⊦ (gs.rfo:= bq0).pq = gs.pq; (s)
Proof step 44 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨PROP_FO(t, l, gs.fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, gs.bq(t) ≠ [],
n < # gs.bq(t), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic unfold applied rule call left
And obtained the following new goals
- Proof step 45:
⟨choose n
with n < # bq(tid) ∧ isPropFO(n, l, bq(tid))
in pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)
ifnone skip⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, tid = t, gs.bq(t) ≠ [], n < # gs.bq(t),
FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Used simplifier rules:
decl: PROP_FO(tid, l, fwriters; pq, bq, rfo)
{choose n
with n < # bq(tid) ∧ isPropFO(n, l, bq(tid))
in pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n,
rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)
ifnone skip
};
Proof step 45 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨choose n
with n < # bq(tid) ∧ isPropFO(n, l, bq(tid))
in pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)
ifnone skip⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, tid = t, gs.bq(t) ≠ [], n < # gs.bq(t),
FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule choose left
And obtained the following new goals
- Proof step 46:
⟨pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, tid = t, gs.bq(t) ≠ [], n0 < # gs.bq(t),
n < # bq(tid), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n0, l, gs.bq(t)), isPropFO(n, l, bq(tid)), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 51:
⟨skip⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, tid = t, gs.bq(t) ≠ [], n < # gs.bq(t),
FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid)))
⊦
Rule argument
Additional information
Proof step 46 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, tid = t, gs.bq(t) ≠ [], n0 < # gs.bq(t),
n < # bq(tid), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n0, l, gs.bq(t)), isPropFO(n, l, bq(tid)), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 47:
pq(l := pq(l) + FO(tid)) = pq0, bq(tid := bq(tid) -p n) = bq0, rfo(tid := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)) = rfo0, ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, tid = t, gs.bq(t) ≠ [], n < # bq(tid),
n0 < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, bq(tid)), isPropFO(n0, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 47 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| pq(l := pq(l) + FO(tid)) = pq0, bq(tid := bq(tid) -p n) = bq0, rfo(tid := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)) = rfo0, ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, tid = t, gs.bq(t) ≠ [], n < # bq(tid),
n0 < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, bq(tid)), isPropFO(n0, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 48:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
gs.bq(t) ≠ [], n0 < # gs.bq(t), n < # gs.bq(t), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t) ')).bq:= gs.bq(t := gs.bq(t) -p n)).rfo:= gs.rfo(t := (t ∈ gs.fwriters(l) ⊃ gs.rfo(t);gs.rfo(t) -p n)), lsf,
pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t)), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
¬ reorder(λ l. [], gs.pq(l := gs.pq(l) + FO(t) '), gs.rfo(t := (t ∈ gs.fwriters(l) ⊃ gs.rfo(t);gs.rfo(t) -p n))),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ x + a = x + a '; (s)
Proof step 48 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
gs.bq(t) ≠ [], n0 < # gs.bq(t), n < # gs.bq(t), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t) ')).bq:= gs.bq(t := gs.bq(t) -p n)).rfo:= gs.rfo(t := (t ∈ gs.fwriters(l) ⊃ gs.rfo(t);gs.rfo(t) -p n)), lsf,
pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t)), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
¬ reorder(λ l. [], gs.pq(l := gs.pq(l) + FO(t) '), gs.rfo(t := (t ∈ gs.fwriters(l) ⊃ gs.rfo(t);gs.rfo(t) -p n))),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 49:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
gs.bq(t) ≠ [], n < # gs.bq(t), n0 < # gs.bq(t),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t) ')).bq:= gs.bq(t := gs.bq(t) -p n)).rfo:= gs.rfo(t := (t ∈ gs.fwriters(l) ⊃ gs.rfo(t);gs.rfo(t) -p n)), lsf,
pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), isPropFO(n0, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
t ∈ gs.fwriters(l), ¬ reorder(λ l. [], gs.pq(l := gs.pq(l) + FO(t) '), gs.rfo(t := (t ∈ gs.fwriters(l) ⊃ gs.rfo(t);gs.rfo(t) -p n))),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t ∈ gs.fwriters(l)
Proof step 49 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
gs.bq(t) ≠ [], n < # gs.bq(t), n0 < # gs.bq(t),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t) ')).bq:= gs.bq(t := gs.bq(t) -p n)).rfo:= gs.rfo(t := (t ∈ gs.fwriters(l) ⊃ gs.rfo(t);gs.rfo(t) -p n)), lsf,
pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), isPropFO(n0, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
t ∈ gs.fwriters(l), ¬ reorder(λ l. [], gs.pq(l := gs.pq(l) + FO(t) '), gs.rfo(t := (t ∈ gs.fwriters(l) ⊃ gs.rfo(t);gs.rfo(t) -p n))),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 50:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
# gs.fwriters(l) ≠ 0, gs.bq(t) ≠ [], gs.fwriters(l) ≠ ∅, n < # gs.bq(t), n0 < # gs.bq(t),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t) ')).bq:= gs.bq(t := gs.bq(t) -p n)).rfo:= gs.rfo(t := gs.rfo(t)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), isPropFO(n0, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), t ∈ gs.fwriters(l),
¬ reorder(λ l. [], gs.pq(l := gs.pq(l) + FO(t) '), gs.rfo(t := gs.rfo(t))), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 50 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
# gs.fwriters(l) ≠ 0, gs.bq(t) ≠ [], gs.fwriters(l) ≠ ∅, n < # gs.bq(t), n0 < # gs.bq(t),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t) ')).bq:= gs.bq(t := gs.bq(t) -p n)).rfo:= gs.rfo(t := gs.rfo(t)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), isPropFO(n0, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), t ∈ gs.fwriters(l),
¬ reorder(λ l. [], gs.pq(l := gs.pq(l) + FO(t) '), gs.rfo(t := gs.rfo(t))), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t, l, gs.fwriters)
Proof step 51 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨skip⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, tid = t, gs.bq(t) ≠ [], n < # gs.bq(t),
FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid)))
⊦ |
Heuristic symbolic execution applied rule skip left
And obtained the following new goals
- Proof step 52:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, bq = bq0, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, pq = pq0, rfo = gs.rfo, rfo = rfo0, tid = t, gs.bq(t) ≠ [],
n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0), ∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid))),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 52 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, bq = bq0, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, pq = pq0, rfo = gs.rfo, rfo = rfo0, tid = t, gs.bq(t) ≠ [],
n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0), ∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid))),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 53:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
gs.bq(t) ≠ [], n < # gs.bq(t), FLITInv(((gs.pq:= gs.pq).bq:= gs.bq).rfo:= gs.rfo, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ n0. ¬ n0 < # gs.bq(t) ∨ ¬ isPropFO(n0, l, gs.bq(t))
⊦
Rule argument
Additional information
Proof step 53 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
gs.bq(t) ≠ [], n < # gs.bq(t), FLITInv(((gs.pq:= gs.pq).bq:= gs.bq).rfo:= gs.rfo, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ n0. ¬ n0 < # gs.bq(t) ∨ ¬ isPropFO(n0, l, gs.bq(t))
⊦ |
Heuristic quantifier closing applied rule all left
And closed the goal!
Rule argument
pos: left 14 terms: n
Additional information
Used terms: n
Proof step 54 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 55:
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 55 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic split applied rule split left
And obtained the following new goals
- Proof step 56:
⟨gs := (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf1),
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Proof step 56 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨gs := (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf1),
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 57:
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
gs0 = (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf0 = lsf, pcf0 = pcf1, pq = gs.pq,
rfo = gs.rfo, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 57 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
gs0 = (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf0 = lsf, pcf0 = pcf1, pq = gs.pq,
rfo = gs.rfo, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
¬ reorder(λ l. [], gs0.pq, gs0.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 58:
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, FLITInv(gs, lsf, pcf),
FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ (gs.rfo:= bq0).rfo = bq0; (s)
⊦ (gs.pq:= pq).pq = pq; (s)
⊦ (gs.fctr:= fctr).pq = gs.pq; (s)
⊦ (gs.bq:= bq).pq = gs.pq; (s)
⊦ (gs.fwriters:= fwriters).pq = gs.pq; (s)
⊦ (gs.freaders:= fwriters0).pq = gs.pq; (s)
⊦ (gs.rfo:= bq0).pq = gs.pq; (s)
Proof step 58 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, FLITInv(gs, lsf, pcf),
FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic unfold applied rule call left
And obtained the following new goals
- Proof step 59:
⟨pcf := λ t. (pcf(t) = idle ⊃ idle;crashed), pq := λ l. [], fctr := λ l. 0, freaders := λ l. ∅, fwriters := λ l. ∅, bq := λ t. [], rfo := λ t. []⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Used simplifier rules:
decl: CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)
{pcf := λ t. (pcf(t) = idle ⊃ idle;crashed), pq := λ l. [], fctr := λ l. 0,
freaders := λ l. ∅, fwriters := λ l. ∅, bq := λ t. [], rfo := λ t. []
};
Proof step 59 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨pcf := λ t. (pcf(t) = idle ⊃ idle;crashed), pq := λ l. [], fctr := λ l. 0, freaders := λ l. ∅, fwriters := λ l. ∅, bq := λ t. [], rfo := λ t. []⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 60:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, (λ l. []) = pq0, (λ l. 0) = fctr0, (λ t. []) = bq0, (λ l. ∅) = fwriters0,
(λ l. ∅) = freaders0, (λ t. []) = rfo0, (λ t. (pcf(t) = idle ⊃ idle;crashed)) = pcf1, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders,
fwriters = gs.fwriters, pq = gs.pq, rfo = gs.rfo, FLITInv(gs, lsf, pcf),
FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 60 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, (λ l. []) = pq0, (λ l. 0) = fctr0, (λ t. []) = bq0, (λ l. ∅) = fwriters0,
(λ l. ∅) = freaders0, (λ t. []) = rfo0, (λ t. (pcf(t) = idle ⊃ idle;crashed)) = pcf1, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders,
fwriters = gs.fwriters, pq = gs.pq, rfo = gs.rfo, FLITInv(gs, lsf, pcf),
FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], pq0, rfo0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 61:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
FLITInv
((((((gs.pq:= (λ l. [])).fctr:= (λ l. 0)).bq:= (λ t. [])).fwriters:= (λ l. ∅)).freaders:= (λ l. ∅)).rfo:= (λ t. []), lsf,
λ t. (pcf(t) = idle ⊃ idle;crashed)),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], λ l. [], λ t. []),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 61 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
FLITInv
((((((gs.pq:= (λ l. [])).fctr:= (λ l. 0)).bq:= (λ t. [])).fwriters:= (λ l. ∅)).freaders:= (λ l. ∅)).rfo:= (λ t. []), lsf,
λ t. (pcf(t) = idle ⊃ idle;crashed)),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ¬ reorder(λ l. [], λ l. [], λ t. []),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 62:
⊦ reorder(p, pq, rfo) ↔ (∀ l. reorder(l, p(l), pq(l), rfo))
Rule argument
spec: abs-FLIT-FLITPSCweak, name:reorder-def,
seq: ⊦ reorder(p, pq, rfo) ↔ (∀ l. reorder(l, p(l), pq(l), rfo)),
subst:[p, pq, rfo] → [λ l. [], λ l. [], λ t. []], <all paths>
Additional information
Used simplifier rules:
⊦ reorder(l, [], fowl0, rfo) ↔ fowl0 = [] ∧ (∀ t. propFOs(t, l, rfo(t)) = []); (s)
⊦ propFOs(t, l, []) = []; (s)
Used terms: λ l. [], λ l. [], λ t. []
Proof step 62 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⊦ reorder(p, pq, rfo) ↔ (∀ l. reorder(l, p(l), pq(l), rfo)) |
A spec-lemma
Proof step 63 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, ∅ ≠ gs0.fwriters(l0), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 64:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, # gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), FLITInv(gs0, lsf0, pcf0),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero: ⊦ # s ≠ 0 → s ≠ ∅; (forward) from specification set-basic
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
Proof step 64 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, # gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), FLITInv(gs0, lsf0, pcf0),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 65:
⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l))) ∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
- Proof step 66:
(∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), globalCRASH, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
globalCRASH = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
globalCRASH = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
globalCRASH = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf
∧ pcf0 = pcf)
∨ globalCRASH = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, # gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), FLITInv(gs, lsf, pcf),
FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
spec: FLIT, name:flitStep,
seq:⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc.
lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls)
∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v)
∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0
= ( gs
.pq:= gs.pq
(gs.bq(tid).head.l
:= gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid)
))
.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l))
∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo;
PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid)
∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0
= (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val))
.pq:= gs.pq(loc := gs.pq(loc).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?)
∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters,
freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs
:= ( ( (((gs.pq:= pq).fctr:= fctr).bq:= bq)
.fwriters:= fwriters)
.freaders:= freaders)
.rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
subst:[lsf, gs, lsf0, a, pcf, pcf0, gs0] → [lsf, gs, lsf0, globalCRASH, pcf, pcf0, gs0],
<all paths>
Additional information
Used terms: pcf0, globalCRASH, lsf, gs0, pcf, lsf0, gs
Proof step 65 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l))) ∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf) |
A spec-lemma
Proof step 66 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), globalCRASH, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
globalCRASH = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
globalCRASH = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
globalCRASH = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf
∧ pcf0 = pcf)
∨ globalCRASH = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, # gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), FLITInv(gs, lsf, pcf),
FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 67:
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)) ∧ n < # gs.bq(t) ∧ isPropFO(n, l, gs.bq(t))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, # gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), FLITInv(gs0, lsf0, pcf0),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ globalPERSIST_FO(loc); (s)
⊦ globalCRASH ≠ globalPERSIST_W(loc); (s)
⊦ globalCRASH ≠ propSF(t); (s)
⊦ doWrite(t, loc, v) ≠ globalCRASH; (s)
⊦ ¬ pre(gs, ls, pc, globalCRASH); (s)
⊦ lstep(gs, ls, pc, a, gs0, ls0, pc0)
↔ pre(gs, ls, pc, a) ∧ ls0 = lstepf(gs, ls, pc, a) ∧ gs0 = gstepf(gs, ls, pc, a)
∧ pc0 = pcstepf(gs, ls, pc, a); (s)
Proof step 67 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)) ∧ n < # gs.bq(t) ∧ isPropFO(n, l, gs.bq(t))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, # gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), FLITInv(gs0, lsf0, pcf0),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic dl case distinction applied rule case distinction
And obtained the following new goals
- Proof step 68:
⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
# gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 82:
⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, # gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), FLITInv(gs, lsf, pcf),
FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Proof step 68 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
# gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 69:
⟨PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, # gs0.fwriters(l0) ≠ 0,
∅ ≠ gs0.fwriters(l0), n < # gs.bq(t), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 69 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨PROP_FO(t, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, # gs0.fwriters(l0) ≠ 0,
∅ ≠ gs0.fwriters(l0), n < # gs.bq(t), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic split applied rule split left
And obtained the following new goals
- Proof step 70:
⟨gs := ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
⟨PROP_FO(t, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
fwriters = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo,
# gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Proof step 70 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨gs := ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
⟨PROP_FO(t, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
fwriters = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo,
# gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 71:
⟨PROP_FO(t, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
fwriters = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), gs0 = ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0,
lsf0 = lsf, pcf0 = pcf, pq = gs.pq, rfo = gs.rfo, # gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), n < # gs.bq(t), FLITInv(gs0, lsf0, pcf0),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 71 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨PROP_FO(t, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
fwriters = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), gs0 = ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0,
lsf0 = lsf, pcf0 = pcf, pq = gs.pq, rfo = gs.rfo, # gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), n < # gs.bq(t), FLITInv(gs0, lsf0, pcf0),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 72:
⟨PROP_FO(t, l, gs.fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, # gs.fwriters(l0) ≠ 0,
gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n < # gs.bq(t), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ # x = 0 ↔ x = []; (s)
size-zero: ⊦ # s ≠ 0 → s ≠ ∅; (forward) from specification set-basic
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
f: ⊦ m < n → n ≠ 0; (forward) from specification nat-basic
⊦ (gs.pq:= pq).fwriters = gs.fwriters; (s)
⊦ (gs.bq:= bq).fwriters = gs.fwriters; (s)
⊦ (gs.rfo:= bq0).fwriters = gs.fwriters; (s)
Proof step 72 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨PROP_FO(t, l, gs.fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, # gs.fwriters(l0) ≠ 0,
gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n < # gs.bq(t), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic unfold applied rule call left
And obtained the following new goals
- Proof step 73:
⟨choose n
with n < # bq(tid) ∧ isPropFO(n, l, bq(tid))
in pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)
ifnone skip⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, tid = t, # gs.fwriters(l0) ≠ 0,
gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Used simplifier rules:
decl: PROP_FO(tid, l, fwriters; pq, bq, rfo)
{choose n
with n < # bq(tid) ∧ isPropFO(n, l, bq(tid))
in pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n,
rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)
ifnone skip
};
Proof step 73 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨choose n
with n < # bq(tid) ∧ isPropFO(n, l, bq(tid))
in pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)
ifnone skip⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, tid = t, # gs.fwriters(l0) ≠ 0,
gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n < # gs.bq(t), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule choose left
And obtained the following new goals
- Proof step 74:
⟨pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, tid = t, # gs.fwriters(l0) ≠ 0,
gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n0 < # gs.bq(t), n < # bq(tid), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t)), isPropFO(n, l, bq(tid)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 79:
⟨skip⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, tid = t, # gs.fwriters(l0) ≠ 0,
gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n < # gs.bq(t), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid)))
⊦
Rule argument
Additional information
Proof step 74 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, tid = t, # gs.fwriters(l0) ≠ 0,
gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n0 < # gs.bq(t), n < # bq(tid), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t)), isPropFO(n, l, bq(tid)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 75:
pq(l := pq(l) + FO(tid)) = pq0, bq(tid := bq(tid) -p n) = bq0, rfo(tid := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)) = rfo0, ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, tid = t, # gs.fwriters(l0) ≠ 0,
gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n < # bq(tid), n0 < # gs.bq(t), FLITInv(gs, lsf, pcf),
FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, bq(tid)), isPropFO(n0, l, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 75 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| pq(l := pq(l) + FO(tid)) = pq0, bq(tid := bq(tid) -p n) = bq0, rfo(tid := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)) = rfo0, ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, tid = t, # gs.fwriters(l0) ≠ 0,
gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n < # bq(tid), n0 < # gs.bq(t), FLITInv(gs, lsf, pcf),
FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, bq(tid)), isPropFO(n0, l, gs.bq(t)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 76:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
# gs.fwriters(l0) ≠ 0, gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n0 < # gs.bq(t), n < # gs.bq(t), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t) ')).bq:= gs.bq(t := gs.bq(t) -p n)).rfo:= gs.rfo(t := (t ∈ gs.fwriters(l) ⊃ gs.rfo(t);gs.rfo(t) -p n)), lsf,
pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t)), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ x + a = x + a '; (s)
Proof step 76 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
# gs.fwriters(l0) ≠ 0, gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n0 < # gs.bq(t), n < # gs.bq(t), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t) ')).bq:= gs.bq(t := gs.bq(t) -p n)).rfo:= gs.rfo(t := (t ∈ gs.fwriters(l) ⊃ gs.rfo(t);gs.rfo(t) -p n)), lsf,
pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t)), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 77:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
# gs.fwriters(l0) ≠ 0, gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n < # gs.bq(t), n0 < # gs.bq(t),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t) ')).bq:= gs.bq(t := gs.bq(t) -p n)).rfo:= gs.rfo(t := (t ∈ gs.fwriters(l) ⊃ gs.rfo(t);gs.rfo(t) -p n)), lsf,
pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), isPropFO(n0, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
t ∈ gs.fwriters(l), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t ∈ gs.fwriters(l)
Proof step 77 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
# gs.fwriters(l0) ≠ 0, gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n < # gs.bq(t), n0 < # gs.bq(t),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t) ')).bq:= gs.bq(t := gs.bq(t) -p n)).rfo:= gs.rfo(t := (t ∈ gs.fwriters(l) ⊃ gs.rfo(t);gs.rfo(t) -p n)), lsf,
pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), isPropFO(n0, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
t ∈ gs.fwriters(l), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 78:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
# gs.fwriters(l0) ≠ 0, # gs.fwriters(l) ≠ 0, gs.bq(t) ≠ [], gs.fwriters(l) ≠ ∅, ∅ ≠ gs.fwriters(l0), n < # gs.bq(t),
n0 < # gs.bq(t), FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t) ')).bq:= gs.bq(t := gs.bq(t) -p n)).rfo:= gs.rfo(t := gs.rfo(t)), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), isPropFO(n0, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
t ∈ gs.fwriters(l), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 78 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
# gs.fwriters(l0) ≠ 0, # gs.fwriters(l) ≠ 0, gs.bq(t) ≠ [], gs.fwriters(l) ≠ ∅, ∅ ≠ gs.fwriters(l0), n < # gs.bq(t),
n0 < # gs.bq(t), FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t) ')).bq:= gs.bq(t := gs.bq(t) -p n)).rfo:= gs.rfo(t := gs.rfo(t)), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), isPropFO(n0, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
t ∈ gs.fwriters(l), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t, l, gs.fwriters)
Proof step 79 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨skip⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, rfo = gs.rfo, tid = t, # gs.fwriters(l0) ≠ 0,
gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n < # gs.bq(t), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid)))
⊦ |
Heuristic symbolic execution applied rule skip left
And obtained the following new goals
- Proof step 80:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, bq = bq0, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, pq = pq0, rfo = gs.rfo, rfo = rfo0, tid = t,
# gs.fwriters(l0) ≠ 0, gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n < # gs.bq(t), FLITInv(gs, lsf, pcf),
FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid))), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 80 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, bq = bq0, fwriters = gs.fwriters,
globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)), pq = gs.pq, pq = pq0, rfo = gs.rfo, rfo = rfo0, tid = t,
# gs.fwriters(l0) ≠ 0, gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n < # gs.bq(t), FLITInv(gs, lsf, pcf),
FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid))), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 81:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
# gs.fwriters(l0) ≠ 0, gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n < # gs.bq(t), FLITInv(((gs.pq:= gs.pq).bq:= gs.bq).rfo:= gs.rfo, lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ n0. ¬ n0 < # gs.bq(t) ∨ ¬ isPropFO(n0, l, gs.bq(t))
⊦
Rule argument
Additional information
Proof step 81 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t, l, gs.fwriters) ⊃ doWriteFO(t, l);propFO(t, l)),
# gs.fwriters(l0) ≠ 0, gs.bq(t) ≠ [], ∅ ≠ gs.fwriters(l0), n < # gs.bq(t), FLITInv(((gs.pq:= gs.pq).bq:= gs.bq).rfo:= gs.rfo, lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ n0. ¬ n0 < # gs.bq(t) ∨ ¬ isPropFO(n0, l, gs.bq(t))
⊦ |
Heuristic quantifier closing applied rule all left
And closed the goal!
Rule argument
pos: left 15 terms: n
Additional information
Used terms: n
Proof step 82 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, # gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), FLITInv(gs, lsf, pcf),
FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 83:
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, # gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 83 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, # gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic split applied rule split left
And obtained the following new goals
- Proof step 84:
⟨gs := (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf1),
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, # gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Proof step 84 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨gs := (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf1),
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, # gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 85:
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
gs0 = (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf0 = lsf, pcf0 = pcf1, pq = gs.pq,
rfo = gs.rfo, # gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 85 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
gs0 = (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf0 = lsf, pcf0 = pcf1, pq = gs.pq,
rfo = gs.rfo, # gs0.fwriters(l0) ≠ 0, ∅ ≠ gs0.fwriters(l0), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 86:
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, # fwriters0(l0) ≠ 0, ∅ ≠ fwriters0(l0), FLITInv(gs, lsf, pcf),
FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero: ⊦ # s ≠ 0 → s ≠ ∅; (forward) from specification set-basic
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
⊦ (gs.fwriters:= fwriters).fwriters = fwriters; (s)
⊦ (gs.freaders:= fwriters0).fwriters = gs.fwriters; (s)
⊦ (gs.rfo:= bq0).fwriters = gs.fwriters; (s)
Proof step 86 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, # fwriters0(l0) ≠ 0, ∅ ≠ fwriters0(l0), FLITInv(gs, lsf, pcf),
FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic unfold applied rule call left
And obtained the following new goals
- Proof step 87:
⟨pcf := λ t. (pcf(t) = idle ⊃ idle;crashed), pq := λ l. [], fctr := λ l. 0, freaders := λ l. ∅, fwriters := λ l. ∅, bq := λ t. [], rfo := λ t. []⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, # fwriters0(l0) ≠ 0, ∅ ≠ fwriters0(l0),
FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 1
Additional information
Used simplifier rules:
decl: CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)
{pcf := λ t. (pcf(t) = idle ⊃ idle;crashed), pq := λ l. [], fctr := λ l. 0,
freaders := λ l. ∅, fwriters := λ l. ∅, bq := λ t. [], rfo := λ t. []
};
Proof step 87 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨pcf := λ t. (pcf(t) = idle ⊃ idle;crashed), pq := λ l. [], fctr := λ l. 0, freaders := λ l. ∅, fwriters := λ l. ∅, bq := λ t. [], rfo := λ t. []⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, # fwriters0(l0) ≠ 0, ∅ ≠ fwriters0(l0),
FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic symbolic execution applied rule assign left
And closed the goal!
Rule argument
Additional information
Proof step 88 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)), reorder(ags.p, gs.pq, gs.rfo),
¬ labs(gs0, lsf0(t), pcf0(t), mkFLITPSCgs(gs.pmem, λ l. [], λ l. 0, λ l. ∅, λ l. ∅), alsf(t), (apcf(t) = idle ⊃ idle;crashed)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 89:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v)
Rule argument
Additional information
Used simplifier rules:
labs-def: ⊦ labs(gs, ls, pc, ags, als, apc)
↔ ls.t = als.t ∧ (pc = idle → apc = idle) ∧ (pc = ready → apc = ready)
∧ (pc = crashed → apc = crashed) ∧ (pc = R1 → apc = R1) ∧ (pc = R2 → apc = R2)
∧ (pc = R3 → apc = R3) ∧ (pc = R4 → apc = R4)
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → ls.loc = als.l)
∧ (pc = R2 ∨ pc = R3 ∨ pc = R4 → ls.val = als.v) ∧ (pc = W1 → apc = W1)
∧ (pc = W2 → apc = (SF ∈ gs.bq(ls.t) ⊃ W1;W2)) ∧ (pc = W3 → apc = W3)
∧ (pc = W4 → apc = (W(ls.loc, ls.val) ∈ gs.bq(ls.t) ⊃ W3;W4))
∧ ( pc = W5
→ apc = (W(ls.loc, ls.val) ∈ gs.bq(ls.t) ⊃ W3;(FO(ls.loc) ∈ gs.bq(ls.t) ⊃ W4;W5)))
∧ ( pc = W6
→ apc
= (W(ls.loc, ls.val) ∈ gs.bq(ls.t)
⊃ W3
;(FO(ls.loc) ∈ gs.bq(ls.t) ⊃ W4;(SF ∈ gs.bq(ls.t) ⊃ W5;W6))
))
∧ (pc = W7 → apc = W7)
∧ ( pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7
→ ls.loc = als.l)
∧ ( pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7
→ ls.val = als.v);
⊦ W7 ≠ crashed; (s)
⊦ W7 ≠ idle; (s)
⊦ W3 ≠ crashed; (s)
⊦ W3 ≠ idle; (s)
⊦ W1 ≠ crashed; (s)
⊦ W1 ≠ idle; (s)
⊦ R4 ≠ crashed; (s)
⊦ R4 ≠ idle; (s)
⊦ R3 ≠ crashed; (s)
⊦ R3 ≠ idle; (s)
⊦ R2 ≠ crashed; (s)
⊦ R2 ≠ idle; (s)
⊦ R1 ≠ crashed; (s)
⊦ R1 ≠ idle; (s)
⊦ crashed ≠ idle; (s)
⊦ crashed ≠ ready; (s)
⊦ idle ≠ ready; (s)
Proof step 89 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
flitStep(mkstate(gs, lsf, pcf), globalCRASH, mkstate(gs0, lsf0, pcf0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v) |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 90:
⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l))) ∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
- Proof step 91:
(∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), globalCRASH, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
globalCRASH = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
globalCRASH = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
globalCRASH = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf
∧ pcf0 = pcf)
∨ globalCRASH = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v)
Rule argument
spec: FLIT, name:flitStep,
seq:⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc.
lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls)
∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v)
∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0
= ( gs
.pq:= gs.pq
(gs.bq(tid).head.l
:= gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid)
))
.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l))
∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo;
PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid)
∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0
= (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val))
.pq:= gs.pq(loc := gs.pq(loc).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?)
∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters,
freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs
:= ( ( (((gs.pq:= pq).fctr:= fctr).bq:= bq)
.fwriters:= fwriters)
.freaders:= freaders)
.rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
subst:[lsf, gs, lsf0, a, pcf, pcf0, gs0] → [lsf, gs, lsf0, globalCRASH, pcf, pcf0, gs0],
<all paths>
Additional information
Used terms: pcf0, globalCRASH, lsf, gs0, pcf, lsf0, gs
Proof step 90 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l))) ∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf) |
A spec-lemma
Proof step 91 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), globalCRASH, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
globalCRASH = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
globalCRASH = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
globalCRASH = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
globalCRASH = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf
∧ pcf0 = pcf)
∨ globalCRASH = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 92:
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)) ∧ n < # gs.bq(t0) ∧ isPropFO(n, l, gs.bq(t0))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t0, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v)
Rule argument
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ globalPERSIST_FO(loc); (s)
⊦ globalCRASH ≠ globalPERSIST_W(loc); (s)
⊦ globalCRASH ≠ propSF(t); (s)
⊦ doWrite(t, loc, v) ≠ globalCRASH; (s)
⊦ ¬ pre(gs, ls, pc, globalCRASH); (s)
⊦ lstep(gs, ls, pc, a, gs0, ls0, pc0)
↔ pre(gs, ls, pc, a) ∧ ls0 = lstepf(gs, ls, pc, a) ∧ gs0 = gstepf(gs, ls, pc, a)
∧ pc0 = pcstepf(gs, ls, pc, a); (s)
Proof step 92 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)) ∧ n < # gs.bq(t0) ∧ isPropFO(n, l, gs.bq(t0))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t0, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v) |
Heuristic dl case distinction applied rule case distinction
And obtained the following new goals
- Proof step 93:
⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t0, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
n < # gs.bq(t0), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v)
- Proof step 156:
⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v)
Rule argument
pos: left 1
Additional information
Proof step 93 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(t0, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
n < # gs.bq(t0), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v) |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 94:
⟨PROP_FO(t0, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pq = gs.pq, rfo = gs.rfo, n < # gs.bq(t0),
FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v)
Rule argument
Additional information
Proof step 94 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨PROP_FO(t0, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pq = gs.pq, rfo = gs.rfo, n < # gs.bq(t0),
FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v) |
Heuristic split applied rule split left
And obtained the following new goals
- Proof step 95:
⟨gs := ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
⟨PROP_FO(t0, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, fwriters = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pq = gs.pq, rfo = gs.rfo,
n < # gs.bq(t0), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v)
Rule argument
pos: left 1
Additional information
Proof step 95 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨gs := ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
⟨PROP_FO(t0, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, fwriters = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pq = gs.pq, rfo = gs.rfo,
n < # gs.bq(t0), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v) |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 96:
⟨PROP_FO(t0, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, fwriters = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs0 = ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf0 = lsf, pcf0 = pcf, pq = gs.pq, rfo = gs.rfo, n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v)
Rule argument
Additional information
Proof step 96 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨PROP_FO(t0, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, fwriters = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs0 = ((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf0 = lsf, pcf0 = pcf, pq = gs.pq, rfo = gs.rfo, n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 97:
⟨PROP_FO(t0, l, gs.fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pq = gs.pq, rfo = gs.rfo, gs.bq(t0) ≠ [],
n < # gs.bq(t0), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ pcf(t) ≠ ready ∧ (pcf(t) = crashed → apcf(t) ≠ idle) ∧ pcf(t) ≠ R1 ∧ pcf(t) ≠ R2
∧ pcf(t) ≠ R3 ∧ pcf(t) ≠ R4 ∧ pcf(t) ≠ W1 ∧ (pcf(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf(t) ≠ W3
∧ (pcf(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf(t) ≠ W7 ∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v)
Rule argument
Additional information
Used simplifier rules:
⊦ # x = 0 ↔ x = []; (s)
f: ⊦ m < n → n ≠ 0; (forward) from specification nat-basic
⊦ (gs.bq:= bq).bq = bq; (s)
⊦ (gs.rfo:= bq0).bq = gs.bq; (s)
Proof step 97 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨PROP_FO(t0, l, gs.fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pq = gs.pq, rfo = gs.rfo, gs.bq(t0) ≠ [],
n < # gs.bq(t0), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ pcf(t) ≠ ready ∧ (pcf(t) = crashed → apcf(t) ≠ idle) ∧ pcf(t) ≠ R1 ∧ pcf(t) ≠ R2
∧ pcf(t) ≠ R3 ∧ pcf(t) ≠ R4 ∧ pcf(t) ≠ W1 ∧ (pcf(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf(t) ≠ W3
∧ (pcf(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf(t) ≠ W7 ∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v) |
Heuristic unfold applied rule call left
And obtained the following new goals
- Proof step 98:
⟨choose n
with n < # bq(tid) ∧ isPropFO(n, l, bq(tid))
in pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)
ifnone skip⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pq = gs.pq, rfo = gs.rfo, tid = t0, gs.bq(t0) ≠ [],
n < # gs.bq(t0), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ pcf(t) ≠ ready ∧ (pcf(t) = crashed → apcf(t) ≠ idle) ∧ pcf(t) ≠ R1 ∧ pcf(t) ≠ R2
∧ pcf(t) ≠ R3 ∧ pcf(t) ≠ R4 ∧ pcf(t) ≠ W1 ∧ (pcf(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf(t) ≠ W3
∧ (pcf(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf(t) ≠ W7 ∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v)
Rule argument
pos: left 1
Additional information
Used simplifier rules:
decl: PROP_FO(tid, l, fwriters; pq, bq, rfo)
{choose n
with n < # bq(tid) ∧ isPropFO(n, l, bq(tid))
in pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n,
rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)
ifnone skip
};
Proof step 98 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨choose n
with n < # bq(tid) ∧ isPropFO(n, l, bq(tid))
in pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)
ifnone skip⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pq = gs.pq, rfo = gs.rfo, tid = t0, gs.bq(t0) ≠ [],
n < # gs.bq(t0), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ pcf(t) ≠ ready ∧ (pcf(t) = crashed → apcf(t) ≠ idle) ∧ pcf(t) ≠ R1 ∧ pcf(t) ≠ R2
∧ pcf(t) ≠ R3 ∧ pcf(t) ≠ R4 ∧ pcf(t) ≠ W1 ∧ (pcf(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf(t) ≠ W3
∧ (pcf(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf(t) ≠ W7 ∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v) |
Heuristic symbolic execution applied rule choose left
And obtained the following new goals
- Proof step 99:
⟨pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pq = gs.pq, rfo = gs.rfo, tid = t0, gs.bq(t0) ≠ [],
n0 < # gs.bq(t0), n < # bq(tid), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, bq(tid)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ pcf(t) ≠ ready ∧ (pcf(t) = crashed → apcf(t) ≠ idle) ∧ pcf(t) ≠ R1 ∧ pcf(t) ≠ R2
∧ pcf(t) ≠ R3 ∧ pcf(t) ≠ R4 ∧ pcf(t) ≠ W1 ∧ (pcf(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf(t) ≠ W3
∧ (pcf(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf(t) ≠ W7 ∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v)
- Proof step 153:
⟨skip⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pq = gs.pq, rfo = gs.rfo, tid = t0, gs.bq(t0) ≠ [],
n < # gs.bq(t0), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid)))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ pcf(t) ≠ ready ∧ (pcf(t) = crashed → apcf(t) ≠ idle) ∧ pcf(t) ≠ R1 ∧ pcf(t) ≠ R2
∧ pcf(t) ≠ R3 ∧ pcf(t) ≠ R4 ∧ pcf(t) ≠ W1 ∧ (pcf(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf(t) ≠ W3
∧ (pcf(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf(t) ≠ W7 ∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v)
Rule argument
Additional information
Proof step 99 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pq = gs.pq, rfo = gs.rfo, tid = t0, gs.bq(t0) ≠ [],
n0 < # gs.bq(t0), n < # bq(tid), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, bq(tid)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ pcf(t) ≠ ready ∧ (pcf(t) = crashed → apcf(t) ≠ idle) ∧ pcf(t) ≠ R1 ∧ pcf(t) ≠ R2
∧ pcf(t) ≠ R3 ∧ pcf(t) ≠ R4 ∧ pcf(t) ≠ W1 ∧ (pcf(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf(t) ≠ W3
∧ (pcf(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf(t) ≠ W7 ∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v) |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 100:
pq(l := pq(l) + FO(tid)) = pq0, bq(tid := bq(tid) -p n) = bq0, rfo(tid := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)) = rfo0, ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pq = gs.pq, rfo = gs.rfo, tid = t0, gs.bq(t0) ≠ [],
n < # bq(tid), n0 < # gs.bq(t0), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, bq(tid)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ pcf(t) ≠ ready ∧ (pcf(t) = crashed → apcf(t) ≠ idle) ∧ pcf(t) ≠ R1 ∧ pcf(t) ≠ R2
∧ pcf(t) ≠ R3 ∧ pcf(t) ≠ R4 ∧ pcf(t) ≠ W1 ∧ (pcf(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf(t) ≠ W3
∧ (pcf(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf(t) ≠ W7 ∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v)
Rule argument
Additional information
Proof step 100 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| pq(l := pq(l) + FO(tid)) = pq0, bq(tid := bq(tid) -p n) = bq0, rfo(tid := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)) = rfo0, ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pq = gs.pq, rfo = gs.rfo, tid = t0, gs.bq(t0) ≠ [],
n < # bq(tid), n0 < # gs.bq(t0), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, bq(tid)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ pcf(t) ≠ ready ∧ (pcf(t) = crashed → apcf(t) ≠ idle) ∧ pcf(t) ≠ R1 ∧ pcf(t) ≠ R2
∧ pcf(t) ≠ R3 ∧ pcf(t) ≠ R4 ∧ pcf(t) ≠ W1 ∧ (pcf(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf(t) ≠ W3
∧ (pcf(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf(t) ≠ W7 ∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 101:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ pcf(t) ≠ ready ∧ (pcf(t) = crashed → apcf(t) ≠ idle) ∧ pcf(t) ≠ R1 ∧ pcf(t) ≠ R2
∧ pcf(t) ≠ R3 ∧ pcf(t) ≠ R4 ∧ pcf(t) ≠ W1
∧ (pcf(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W1;W2)) ∧ pcf(t) ≠ W3
∧ (pcf(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W4;W5)
))
∧ ( pcf(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W4
;(SF ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W5;W6)
)
))
∧ pcf(t) ≠ W7 ∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v)
Rule argument
Additional information
Used simplifier rules:
⊦ x + a = x + a '; (s)
Proof step 101 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ pcf(t) ≠ ready ∧ (pcf(t) = crashed → apcf(t) ≠ idle) ∧ pcf(t) ≠ R1 ∧ pcf(t) ≠ R2
∧ pcf(t) ≠ R3 ∧ pcf(t) ≠ R4 ∧ pcf(t) ≠ W1
∧ (pcf(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W1;W2)) ∧ pcf(t) ≠ W3
∧ (pcf(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W4;W5)
))
∧ ( pcf(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W4
;(SF ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W5;W6)
)
))
∧ pcf(t) ≠ W7 ∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v) |
Heuristic if-then-else split applied rule case distinction
And obtained the following new goals
- Proof step 102:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs.bq(t0) ≠ [], lsf(t).t ≠ alsf(t).t, n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 105:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = idle, gs.bq(t0) ≠ [], apcf(t) ≠ idle, n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 108:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = ready, gs.bq(t0) ≠ [], n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 111:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, apcf(t) = idle,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pcf(t) = crashed, gs.bq(t0) ≠ [], n < # gs.bq(t0),
n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 114:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R1, gs.bq(t0) ≠ [], n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 117:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R2, gs.bq(t0) ≠ [], n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 120:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R3, gs.bq(t0) ≠ [], n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 123:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R4, gs.bq(t0) ≠ [], n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 126:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W1, gs.bq(t0) ≠ [], n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 129:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W2, gs.bq(t0) ≠ [], (apcf(t) = idle ⊃ idle;crashed) ≠ (SF ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W1;W2),
n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 132:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W3, gs.bq(t0) ≠ [], n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 135:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W4, gs.bq(t0) ≠ [],
(apcf(t) = idle ⊃ idle;crashed) ≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W3;W4), n < # gs.bq(t0),
n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 138:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W5, gs.bq(t0) ≠ [],
(apcf(t) = idle ⊃ idle;crashed)
≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W4;W5)
),
n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 141:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W6, gs.bq(t0) ≠ [],
(apcf(t) = idle ⊃ idle;crashed)
≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W4
;(SF ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W5;W6)
)
),
n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 144:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W7, gs.bq(t0) ≠ [], n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 147:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs.bq(t0) ≠ [], lsf(t).loc ≠ alsf(t).l, n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6
⊦
- Proof step 150:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs.bq(t0) ≠ [], lsf(t).val ≠ alsf(t).v, n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6
⊦
Rule argument
pos: right 1
Additional information
Proof step 102 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs.bq(t0) ≠ [], lsf(t).t ≠ alsf(t).t, n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 103:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs.bq(t0) ≠ [], lsf(t).t ≠ alsf(t).t, n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 103 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs.bq(t0) ≠ [], lsf(t).t ≠ alsf(t).t, n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 104:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
# gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, lsf(t).t ≠ alsf(t).t, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 104 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
# gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, lsf(t).t ≠ alsf(t).t, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 105 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = idle, gs.bq(t0) ≠ [], apcf(t) ≠ idle, n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 106:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = idle, gs.bq(t0) ≠ [], apcf(t) ≠ idle, n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 106 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = idle, gs.bq(t0) ≠ [], apcf(t) ≠ idle, n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 107:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = idle, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, apcf(t) ≠ idle, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 107 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = idle, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, apcf(t) ≠ idle, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 108 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = ready, gs.bq(t0) ≠ [], n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 109:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = ready, gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 109 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = ready, gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 110:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = ready, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 110 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = ready, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 111 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, apcf(t) = idle,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pcf(t) = crashed, gs.bq(t0) ≠ [], n < # gs.bq(t0),
n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 112:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, apcf(t) = idle,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pcf(t) = crashed, gs.bq(t0) ≠ [], n0 < # gs.bq(t0),
n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 112 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, apcf(t) = idle,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pcf(t) = crashed, gs.bq(t0) ≠ [], n0 < # gs.bq(t0),
n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 113:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, apcf(t) = idle,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pcf(t) = crashed, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [],
gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 113 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, apcf(t) = idle,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pcf(t) = crashed, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [],
gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 114 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R1, gs.bq(t0) ≠ [], n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 115:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R1, gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 115 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R1, gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 116:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R1, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 116 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R1, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 117 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R2, gs.bq(t0) ≠ [], n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 118:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R2, gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 118 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R2, gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 119:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R2, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 119 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R2, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 120 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R3, gs.bq(t0) ≠ [], n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 121:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R3, gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 121 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R3, gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 122:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R3, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 122 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R3, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 123 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R4, gs.bq(t0) ≠ [], n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 124:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R4, gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 124 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R4, gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 125:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R4, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 125 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = R4, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 126 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W1, gs.bq(t0) ≠ [], n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 127:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W1, gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 127 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W1, gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 128:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W1, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 128 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W1, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 129 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W2, gs.bq(t0) ≠ [], (apcf(t) = idle ⊃ idle;crashed) ≠ (SF ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W1;W2),
n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 130:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W2, gs.bq(t0) ≠ [], (apcf(t) = idle ⊃ idle;crashed) ≠ (SF ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W1;W2),
n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 130 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W2, gs.bq(t0) ≠ [], (apcf(t) = idle ⊃ idle;crashed) ≠ (SF ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W1;W2),
n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 131:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W2, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅,
(apcf(t) = idle ⊃ idle;crashed) ≠ (SF ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W1;W2), n0 < # gs.bq(t0),
n < # gs.bq(t0), FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
t0 ∈ gs.fwriters(l), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 131 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W2, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅,
(apcf(t) = idle ⊃ idle;crashed) ≠ (SF ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W1;W2), n0 < # gs.bq(t0),
n < # gs.bq(t0), FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
t0 ∈ gs.fwriters(l), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 132 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W3, gs.bq(t0) ≠ [], n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 133:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W3, gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 133 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W3, gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 134:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W3, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 134 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W3, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 135 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W4, gs.bq(t0) ≠ [],
(apcf(t) = idle ⊃ idle;crashed) ≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W3;W4), n < # gs.bq(t0),
n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 136:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W4, gs.bq(t0) ≠ [],
(apcf(t) = idle ⊃ idle;crashed) ≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W3;W4),
n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 136 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W4, gs.bq(t0) ≠ [],
(apcf(t) = idle ⊃ idle;crashed) ≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W3;W4),
n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 137:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W4, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅,
(apcf(t) = idle ⊃ idle;crashed) ≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W3;W4),
n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 137 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W4, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅,
(apcf(t) = idle ⊃ idle;crashed) ≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W3;W4),
n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 138 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W5, gs.bq(t0) ≠ [],
(apcf(t) = idle ⊃ idle;crashed)
≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W4;W5)
),
n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 139:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W5, gs.bq(t0) ≠ [],
(apcf(t) = idle ⊃ idle;crashed)
≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W4;W5)
),
n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 139 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W5, gs.bq(t0) ≠ [],
(apcf(t) = idle ⊃ idle;crashed)
≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W4;W5)
),
n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 140:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W5, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅,
(apcf(t) = idle ⊃ idle;crashed)
≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W4;W5)
),
n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 140 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W5, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅,
(apcf(t) = idle ⊃ idle;crashed)
≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W4;W5)
),
n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 141 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W6, gs.bq(t0) ≠ [],
(apcf(t) = idle ⊃ idle;crashed)
≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W4
;(SF ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W5;W6)
)
),
n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 142:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W6, gs.bq(t0) ≠ [],
(apcf(t) = idle ⊃ idle;crashed)
≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W4
;(SF ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W5;W6)
)
),
n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 142 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W6, gs.bq(t0) ≠ [],
(apcf(t) = idle ⊃ idle;crashed)
≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W4
;(SF ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W5;W6)
)
),
n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 143:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W6, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅,
(apcf(t) = idle ⊃ idle;crashed)
≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W4
;(SF ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W5;W6)
)
),
n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 143 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W6, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅,
(apcf(t) = idle ⊃ idle;crashed)
≠ (W(lsf(t).loc, lsf(t).val) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t))
⊃ W4
;(SF ∈ (t0 = lsf(t).t ⊃ gs.bq(lsf(t).t) -p n;gs.bq(lsf(t).t)) ⊃ W5;W6)
)
),
n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 144 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W7, gs.bq(t0) ≠ [], n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 145:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W7, gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 145 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W7, gs.bq(t0) ≠ [], n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 146:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W7, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 146 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
pcf(t) = W7, # gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 147 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs.bq(t0) ≠ [], lsf(t).loc ≠ alsf(t).l, n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 148:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs.bq(t0) ≠ [], lsf(t).loc ≠ alsf(t).l, n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 148 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs.bq(t0) ≠ [], lsf(t).loc ≠ alsf(t).l, n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 149:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
# gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, lsf(t).loc ≠ alsf(t).l, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 149 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
# gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, lsf(t).loc ≠ alsf(t).l, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 150 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs.bq(t0) ≠ [], lsf(t).val ≠ alsf(t).v, n < # gs.bq(t0), n0 < # gs.bq(t0),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), isPropFO(n0, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 151:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs.bq(t0) ≠ [], lsf(t).val ≠ alsf(t).v, n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6
⊦
Rule argument
fma: t0 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ globalCRASH ≠ propFO(t, loc); (s)
Used formulas: t0 ∈ gs.fwriters(l)
Proof step 151 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs.bq(t0) ≠ [], lsf(t).val ≠ alsf(t).v, n0 < # gs.bq(t0), n < # gs.bq(t0), FLITInv(gs, lsf, pcf),
FLITInv
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := (t0 ∈ gs.fwriters(l) ⊃ gs.rfo(t0);gs.rfo(t0) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 152:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
# gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, lsf(t).val ≠ alsf(t).v, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6
⊦
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 152 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
# gs.fwriters(l) ≠ 0, gs.bq(t0) ≠ [], gs.fwriters(l) ≠ ∅, lsf(t).val ≠ alsf(t).v, n0 < # gs.bq(t0), n < # gs.bq(t0),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(t0) ')).bq:= gs.bq(t0 := gs.bq(t0) -p n)).rfo:= gs.rfo(t0 := gs.rfo(t0)), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(t0)), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), t0 ∈ gs.fwriters(l),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(t0, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ globalCRASH ≠ propFO(t, loc); (s)
⊦ doWriteFO(t, loc) ≠ globalCRASH; (s)
Used formulas: oneMember(t0, l, gs.fwriters)
Proof step 153 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨skip⟩ (pq = pq0 ∧ bq = bq0 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fwriters = gs.fwriters,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pq = gs.pq, rfo = gs.rfo, tid = t0, gs.bq(t0) ≠ [],
n < # gs.bq(t0), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid)))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ pcf(t) ≠ ready ∧ (pcf(t) = crashed → apcf(t) ≠ idle) ∧ pcf(t) ≠ R1 ∧ pcf(t) ≠ R2
∧ pcf(t) ≠ R3 ∧ pcf(t) ≠ R4 ∧ pcf(t) ≠ W1 ∧ (pcf(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf(t) ≠ W3
∧ (pcf(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf(t) ≠ W7 ∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v) |
Heuristic symbolic execution applied rule skip left
And obtained the following new goals
- Proof step 154:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, bq = bq0, fwriters = gs.fwriters,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pq = gs.pq, pq = pq0, rfo = gs.rfo, rfo = rfo0, tid = t0,
gs.bq(t0) ≠ [], n < # gs.bq(t0), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), ∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid))),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ pcf(t) ≠ ready ∧ (pcf(t) = crashed → apcf(t) ≠ idle) ∧ pcf(t) ≠ R1 ∧ pcf(t) ≠ R2
∧ pcf(t) ≠ R3 ∧ pcf(t) ≠ R4 ∧ pcf(t) ≠ W1 ∧ (pcf(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf(t) ≠ W3
∧ (pcf(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf(t) ≠ W7 ∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v)
Rule argument
Additional information
Proof step 154 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, bq = bq0, fwriters = gs.fwriters,
globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)), pq = gs.pq, pq = pq0, rfo = gs.rfo, rfo = rfo0, tid = t0,
gs.bq(t0) ≠ [], n < # gs.bq(t0), FLITInv(((gs.pq:= pq0).bq:= bq0).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), ∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid))),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ pcf(t) ≠ ready ∧ (pcf(t) = crashed → apcf(t) ≠ idle) ∧ pcf(t) ≠ R1 ∧ pcf(t) ≠ R2
∧ pcf(t) ≠ R3 ∧ pcf(t) ≠ R4 ∧ pcf(t) ≠ W1 ∧ (pcf(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf(t) ≠ W3
∧ (pcf(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf(t) ≠ W7 ∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 155:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs.bq(t0) ≠ [], n < # gs.bq(t0), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= gs.pq).bq:= gs.bq).rfo:= gs.rfo, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ n0. ¬ n0 < # gs.bq(t0) ∨ ¬ isPropFO(n0, l, gs.bq(t0))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ pcf(t) ≠ ready ∧ (pcf(t) = crashed → apcf(t) ≠ idle) ∧ pcf(t) ≠ R1 ∧ pcf(t) ≠ R2
∧ pcf(t) ≠ R3 ∧ pcf(t) ≠ R4 ∧ pcf(t) ≠ W1 ∧ (pcf(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs.bq(lsf(t).t) ⊃ W1;W2)) ∧ pcf(t) ≠ W3
∧ (pcf(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(lsf(t).t) ⊃ W3;W4))
∧ (pcf(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(lsf(t).t) ⊃ W4;(SF ∈ gs.bq(lsf(t).t) ⊃ W5;W6))))
∧ pcf(t) ≠ W7 ∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v)
Rule argument
Additional information
Proof step 155 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, globalCRASH = (oneMember(t0, l, gs.fwriters) ⊃ doWriteFO(t0, l);propFO(t0, l)),
gs.bq(t0) ≠ [], n < # gs.bq(t0), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= gs.pq).bq:= gs.bq).rfo:= gs.rfo, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(t0)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ n0. ¬ n0 < # gs.bq(t0) ∨ ¬ isPropFO(n0, l, gs.bq(t0))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ pcf(t) ≠ ready ∧ (pcf(t) = crashed → apcf(t) ≠ idle) ∧ pcf(t) ≠ R1 ∧ pcf(t) ≠ R2
∧ pcf(t) ≠ R3 ∧ pcf(t) ≠ R4 ∧ pcf(t) ≠ W1 ∧ (pcf(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs.bq(lsf(t).t) ⊃ W1;W2)) ∧ pcf(t) ≠ W3
∧ (pcf(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(lsf(t).t) ⊃ W3;W4))
∧ (pcf(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(lsf(t).t) ⊃ W4;(SF ∈ gs.bq(lsf(t).t) ⊃ W5;W6))))
∧ pcf(t) ≠ W7 ∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf(t) = W2 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v) |
Heuristic quantifier closing applied rule all left
And closed the goal!
Rule argument
pos: left 13 terms: n
Additional information
Used terms: n
Proof step 156 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v) |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 157:
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v)
Rule argument
Additional information
Proof step 157 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf); gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v) |
Heuristic split applied rule split left
And obtained the following new goals
- Proof step 158:
⟨gs := (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf1),
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v)
Rule argument
pos: left 1
Additional information
Proof step 158 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨gs := (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf1),
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v) |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 159:
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
gs0 = (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf0 = lsf, pcf0 = pcf1, pq = gs.pq,
rfo = gs.rfo, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v)
Rule argument
Additional information
Proof step 159 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
gs0 = (((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf0 = lsf, pcf0 = pcf1, pq = gs.pq,
rfo = gs.rfo, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf0(t).t = alsf(t).t ∧ (pcf0(t) = idle → apcf(t) = idle) ∧ pcf0(t) ≠ ready ∧ (pcf0(t) = crashed → apcf(t) ≠ idle) ∧ pcf0(t) ≠ R1 ∧ pcf0(t) ≠ R2
∧ pcf0(t) ≠ R3 ∧ pcf0(t) ≠ R4 ∧ pcf0(t) ≠ W1 ∧ (pcf0(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ gs0.bq(lsf0(t).t) ⊃ W1;W2)) ∧ pcf0(t) ≠ W3
∧ (pcf0(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;W4))
∧ ( pcf0(t) = W5
→ (apcf(t) = idle ⊃ idle;crashed) = (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;W5)))
∧ ( pcf0(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf0(t).loc, lsf0(t).val) ∈ gs0.bq(lsf0(t).t) ⊃ W3;(FO(lsf0(t).loc) ∈ gs0.bq(lsf0(t).t) ⊃ W4;(SF ∈ gs0.bq(lsf0(t).t) ⊃ W5;W6))))
∧ pcf0(t) ≠ W7 ∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).loc = alsf(t).l)
∧ (pcf0(t) = W2 ∨ pcf0(t) = W4 ∨ pcf0(t) = W5 ∨ pcf0(t) = W6 → lsf0(t).val = alsf(t).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 160:
⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf1(t) = idle → apcf(t) = idle) ∧ pcf1(t) ≠ ready ∧ (pcf1(t) = crashed → apcf(t) ≠ idle) ∧ pcf1(t) ≠ R1 ∧ pcf1(t) ≠ R2
∧ pcf1(t) ≠ R3 ∧ pcf1(t) ≠ R4 ∧ pcf1(t) ≠ W1 ∧ (pcf1(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf1(t) ≠ W3
∧ (pcf1(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf1(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf1(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf1(t) ≠ W7 ∧ (pcf1(t) = W2 ∨ pcf1(t) = W4 ∨ pcf1(t) = W5 ∨ pcf1(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf1(t) = W2 ∨ pcf1(t) = W4 ∨ pcf1(t) = W5 ∨ pcf1(t) = W6 → lsf(t).val = alsf(t).v)
Rule argument
Additional information
Used simplifier rules:
⊦ (gs.bq:= bq).bq = bq; (s)
⊦ (gs.fwriters:= fwriters).bq = gs.bq; (s)
⊦ (gs.freaders:= fwriters0).bq = gs.bq; (s)
⊦ (gs.rfo:= bq0).bq = gs.bq; (s)
Proof step 160 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf1(t) = idle → apcf(t) = idle) ∧ pcf1(t) ≠ ready ∧ (pcf1(t) = crashed → apcf(t) ≠ idle) ∧ pcf1(t) ≠ R1 ∧ pcf1(t) ≠ R2
∧ pcf1(t) ≠ R3 ∧ pcf1(t) ≠ R4 ∧ pcf1(t) ≠ W1 ∧ (pcf1(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf1(t) ≠ W3
∧ (pcf1(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf1(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf1(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf1(t) ≠ W7 ∧ (pcf1(t) = W2 ∨ pcf1(t) = W4 ∨ pcf1(t) = W5 ∨ pcf1(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf1(t) = W2 ∨ pcf1(t) = W4 ∨ pcf1(t) = W5 ∨ pcf1(t) = W6 → lsf(t).val = alsf(t).v) |
Heuristic unfold applied rule call left
And obtained the following new goals
- Proof step 161:
⟨pcf := λ t. (pcf(t) = idle ⊃ idle;crashed), pq := λ l. [], fctr := λ l. 0, freaders := λ l. ∅, fwriters := λ l. ∅, bq := λ t. [], rfo := λ t. []⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, FLITInv(gs, lsf, pcf),
FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf1(t) = idle → apcf(t) = idle) ∧ pcf1(t) ≠ ready ∧ (pcf1(t) = crashed → apcf(t) ≠ idle) ∧ pcf1(t) ≠ R1 ∧ pcf1(t) ≠ R2
∧ pcf1(t) ≠ R3 ∧ pcf1(t) ≠ R4 ∧ pcf1(t) ≠ W1 ∧ (pcf1(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf1(t) ≠ W3
∧ (pcf1(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf1(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf1(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf1(t) ≠ W7 ∧ (pcf1(t) = W2 ∨ pcf1(t) = W4 ∨ pcf1(t) = W5 ∨ pcf1(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf1(t) = W2 ∨ pcf1(t) = W4 ∨ pcf1(t) = W5 ∨ pcf1(t) = W6 → lsf(t).val = alsf(t).v)
Rule argument
pos: left 1
Additional information
Used simplifier rules:
decl: CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf)
{pcf := λ t. (pcf(t) = idle ⊃ idle;crashed), pq := λ l. [], fctr := λ l. 0,
freaders := λ l. ∅, fwriters := λ l. ∅, bq := λ t. [], rfo := λ t. []
};
Proof step 161 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ⟨pcf := λ t. (pcf(t) = idle ⊃ idle;crashed), pq := λ l. [], fctr := λ l. 0, freaders := λ l. ∅, fwriters := λ l. ∅, bq := λ t. [], rfo := λ t. []⟩
(pq = pq0 ∧ fctr = fctr0 ∧ bq = bq0 ∧ fwriters = fwriters0 ∧ freaders = freaders0 ∧ rfo = rfo0 ∧ pcf = pcf1),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders, fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, FLITInv(gs, lsf, pcf),
FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf1(t) = idle → apcf(t) = idle) ∧ pcf1(t) ≠ ready ∧ (pcf1(t) = crashed → apcf(t) ≠ idle) ∧ pcf1(t) ≠ R1 ∧ pcf1(t) ≠ R2
∧ pcf1(t) ≠ R3 ∧ pcf1(t) ≠ R4 ∧ pcf1(t) ≠ W1 ∧ (pcf1(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf1(t) ≠ W3
∧ (pcf1(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf1(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf1(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf1(t) ≠ W7 ∧ (pcf1(t) = W2 ∨ pcf1(t) = W4 ∨ pcf1(t) = W5 ∨ pcf1(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf1(t) = W2 ∨ pcf1(t) = W4 ∨ pcf1(t) = W5 ∨ pcf1(t) = W6 → lsf(t).val = alsf(t).v) |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 162:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, (λ l. []) = pq0, (λ l. 0) = fctr0, (λ t. []) = bq0, (λ l. ∅) = fwriters0,
(λ l. ∅) = freaders0, (λ t. []) = rfo0, (λ t. (pcf(t) = idle ⊃ idle;crashed)) = pcf1, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders,
fwriters = gs.fwriters, pq = gs.pq, rfo = gs.rfo,
FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf1(t) = idle → apcf(t) = idle) ∧ pcf1(t) ≠ ready ∧ (pcf1(t) = crashed → apcf(t) ≠ idle) ∧ pcf1(t) ≠ R1 ∧ pcf1(t) ≠ R2
∧ pcf1(t) ≠ R3 ∧ pcf1(t) ≠ R4 ∧ pcf1(t) ≠ W1 ∧ (pcf1(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf1(t) ≠ W3
∧ (pcf1(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf1(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf1(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf1(t) ≠ W7 ∧ (pcf1(t) = W2 ∨ pcf1(t) = W4 ∨ pcf1(t) = W5 ∨ pcf1(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf1(t) = W2 ∨ pcf1(t) = W4 ∨ pcf1(t) = W5 ∨ pcf1(t) = W6 → lsf(t).val = alsf(t).v)
Rule argument
Additional information
Proof step 162 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, (λ l. []) = pq0, (λ l. 0) = fctr0, (λ t. []) = bq0, (λ l. ∅) = fwriters0,
(λ l. ∅) = freaders0, (λ t. []) = rfo0, (λ t. (pcf(t) = idle ⊃ idle;crashed)) = pcf1, bq = gs.bq, fctr = gs.fctr, freaders = gs.freaders,
fwriters = gs.fwriters, pq = gs.pq, rfo = gs.rfo,
FLITInv((((((gs.pq:= pq0).fctr:= fctr0).bq:= bq0).fwriters:= fwriters0).freaders:= freaders0).rfo:= rfo0, lsf, pcf1), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf1(t) = idle → apcf(t) = idle) ∧ pcf1(t) ≠ ready ∧ (pcf1(t) = crashed → apcf(t) ≠ idle) ∧ pcf1(t) ≠ R1 ∧ pcf1(t) ≠ R2
∧ pcf1(t) ≠ R3 ∧ pcf1(t) ≠ R4 ∧ pcf1(t) ≠ W1 ∧ (pcf1(t) = W2 → (apcf(t) = idle ⊃ idle;crashed) = (SF ∈ bq0(lsf(t).t) ⊃ W1;W2)) ∧ pcf1(t) ≠ W3
∧ (pcf1(t) = W4 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;W4))
∧ (pcf1(t) = W5 → (apcf(t) = idle ⊃ idle;crashed) = (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;W5)))
∧ ( pcf1(t) = W6
→ (apcf(t) = idle ⊃ idle;crashed)
= (W(lsf(t).loc, lsf(t).val) ∈ bq0(lsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ bq0(lsf(t).t) ⊃ W4;(SF ∈ bq0(lsf(t).t) ⊃ W5;W6))))
∧ pcf1(t) ≠ W7 ∧ (pcf1(t) = W2 ∨ pcf1(t) = W4 ∨ pcf1(t) = W5 ∨ pcf1(t) = W6 → lsf(t).loc = alsf(t).l)
∧ (pcf1(t) = W2 ∨ pcf1(t) = W4 ∨ pcf1(t) = W5 ∨ pcf1(t) = W6 → lsf(t).val = alsf(t).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 163:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf),
FLITInv
((((((gs.pq:= (λ l. [])).fctr:= (λ l. 0)).bq:= (λ t. [])).fwriters:= (λ l. ∅)).freaders:= (λ l. ∅)).rfo:= (λ t. []), lsf,
λ t. (pcf(t) = idle ⊃ idle;crashed)),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ (pcf(t) ≠ idle → apcf(t) ≠ idle)
Rule argument
Additional information
Used simplifier rules:
⊦ W6 ≠ crashed; (s)
⊦ W6 ≠ idle; (s)
⊦ W5 ≠ crashed; (s)
⊦ W5 ≠ idle; (s)
⊦ W4 ≠ crashed; (s)
⊦ W4 ≠ idle; (s)
⊦ W2 ≠ crashed; (s)
⊦ W2 ≠ idle; (s)
⊦ W7 ≠ crashed; (s)
⊦ W7 ≠ idle; (s)
⊦ W3 ≠ crashed; (s)
⊦ W3 ≠ idle; (s)
⊦ W1 ≠ crashed; (s)
⊦ W1 ≠ idle; (s)
⊦ R4 ≠ crashed; (s)
⊦ R4 ≠ idle; (s)
⊦ R3 ≠ crashed; (s)
⊦ R3 ≠ idle; (s)
⊦ R2 ≠ crashed; (s)
⊦ R2 ≠ idle; (s)
⊦ R1 ≠ crashed; (s)
⊦ R1 ≠ idle; (s)
⊦ crashed ≠ idle; (s)
⊦ crashed ≠ ready; (s)
⊦ idle ≠ ready; (s)
Proof step 163 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf),
FLITInv
((((((gs.pq:= (λ l. [])).fctr:= (λ l. 0)).bq:= (λ t. [])).fwriters:= (λ l. ∅)).freaders:= (λ l. ∅)).rfo:= (λ t. []), lsf,
λ t. (pcf(t) = idle ⊃ idle;crashed)),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ (pcf(t) ≠ idle → apcf(t) ≠ idle) |
User applied rule all left
And obtained the following new goals
- Proof step 164:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
FLITInv
((((((gs.pq:= (λ l. [])).fctr:= (λ l. 0)).bq:= (λ t. [])).fwriters:= (λ l. ∅)).freaders:= (λ l. ∅)).rfo:= (λ t. []), lsf,
λ t. (pcf(t) = idle ⊃ idle;crashed)),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ (pcf(t) ≠ idle → apcf(t) ≠ idle)
Rule argument
pos: left 8 terms: t abort: F discard: F computed: F
Additional information
Used terms: t
Proof step 164 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
FLITInv
((((((gs.pq:= (λ l. [])).fctr:= (λ l. 0)).bq:= (λ t. [])).fwriters:= (λ l. ∅)).freaders:= (λ l. ∅)).rfo:= (λ t. []), lsf,
λ t. (pcf(t) = idle ⊃ idle;crashed)),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = alsf(t).t ∧ (pcf(t) = idle → apcf(t) = idle) ∧ (pcf(t) ≠ idle → apcf(t) ≠ idle) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 165:
ags.ctr = gs.fctr, ags.mem = gs.pmem, lsf(t).t = alsf(t).t, ags.writers = gs.fwriters, apcf(t) = idle, pcf(t) ≠ idle, pcf(t) ≠ W7, pcf(t) ≠ W6,
pcf(t) ≠ W5, pcf(t) ≠ W4, pcf(t) ≠ W3, pcf(t) ≠ W2, pcf(t) ≠ W1, pcf(t) ≠ R4, pcf(t) ≠ R3, pcf(t) ≠ R2, pcf(t) ≠ R1, pcf(t) ≠ crashed, pcf(t) ≠ ready,
FLITInv
((((((gs.pq:= (λ l. [])).fctr:= (λ l. 0)).bq:= (λ t. [])).fwriters:= (λ l. ∅)).freaders:= (λ l. ∅)).rfo:= (λ t. []), lsf,
λ t. (pcf(t) = idle ⊃ idle;crashed)),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
labs-def: ⊦ labs(gs, ls, pc, ags, als, apc)
↔ ls.t = als.t ∧ (pc = idle → apc = idle) ∧ (pc = ready → apc = ready)
∧ (pc = crashed → apc = crashed) ∧ (pc = R1 → apc = R1) ∧ (pc = R2 → apc = R2)
∧ (pc = R3 → apc = R3) ∧ (pc = R4 → apc = R4)
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → ls.loc = als.l)
∧ (pc = R2 ∨ pc = R3 ∨ pc = R4 → ls.val = als.v) ∧ (pc = W1 → apc = W1)
∧ (pc = W2 → apc = (SF ∈ gs.bq(ls.t) ⊃ W1;W2)) ∧ (pc = W3 → apc = W3)
∧ (pc = W4 → apc = (W(ls.loc, ls.val) ∈ gs.bq(ls.t) ⊃ W3;W4))
∧ ( pc = W5
→ apc = (W(ls.loc, ls.val) ∈ gs.bq(ls.t) ⊃ W3;(FO(ls.loc) ∈ gs.bq(ls.t) ⊃ W4;W5)))
∧ ( pc = W6
→ apc
= (W(ls.loc, ls.val) ∈ gs.bq(ls.t)
⊃ W3
;(FO(ls.loc) ∈ gs.bq(ls.t) ⊃ W4;(SF ∈ gs.bq(ls.t) ⊃ W5;W6))
))
∧ (pc = W7 → apc = W7)
∧ ( pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7
→ ls.loc = als.l)
∧ ( pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7
→ ls.val = als.v);
⊦ idle ≠ ready; (s)
⊦ crashed ≠ idle; (s)
⊦ R1 ≠ idle; (s)
⊦ R2 ≠ idle; (s)
⊦ R3 ≠ idle; (s)
⊦ R4 ≠ idle; (s)
⊦ W1 ≠ idle; (s)
⊦ W2 ≠ idle; (s)
⊦ W3 ≠ idle; (s)
⊦ W4 ≠ idle; (s)
⊦ W5 ≠ idle; (s)
⊦ W6 ≠ idle; (s)
⊦ W7 ≠ idle; (s)
Proof step 165 from proof step-absstep-CRASH-globalCRASH (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, lsf(t).t = alsf(t).t, ags.writers = gs.fwriters, apcf(t) = idle, pcf(t) ≠ idle, pcf(t) ≠ W7, pcf(t) ≠ W6,
pcf(t) ≠ W5, pcf(t) ≠ W4, pcf(t) ≠ W3, pcf(t) ≠ W2, pcf(t) ≠ W1, pcf(t) ≠ R4, pcf(t) ≠ R3, pcf(t) ≠ R2, pcf(t) ≠ R1, pcf(t) ≠ crashed, pcf(t) ≠ ready,
FLITInv
((((((gs.pq:= (λ l. [])).fctr:= (λ l. 0)).bq:= (λ t. [])).fwriters:= (λ l. ∅)).freaders:= (λ l. ∅)).rfo:= (λ t. []), lsf,
λ t. (pcf(t) = idle ⊃ idle;crashed)),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
User applied rule constructor cut
And closed the goal!
Rule argument
term: pcf(t)
Additional information
Used simplifier rules:
FLITPC
freely generated by R1, R2, R3, R4, W1, W2, W3, W4, W5, W6, W7, crashed, idle, ready
;;
Proof Tree for step-absstep-CRASH-globalCRASH
(View conclusion)
The following image shows the proof tree of sequent calculus. The
proved goal is at the bottom. You can click on the nodes to view
additional rules. See here for details on colors in a proof
tree.