[Imprint][Data Privacy Statement][E-Mail]
View long theorem info.
View the proof.
Back to main index.
View the specification.
View theorem base summary,
View theorem base listing,
the used properties by spec,
the dependency list,
the symbol table,
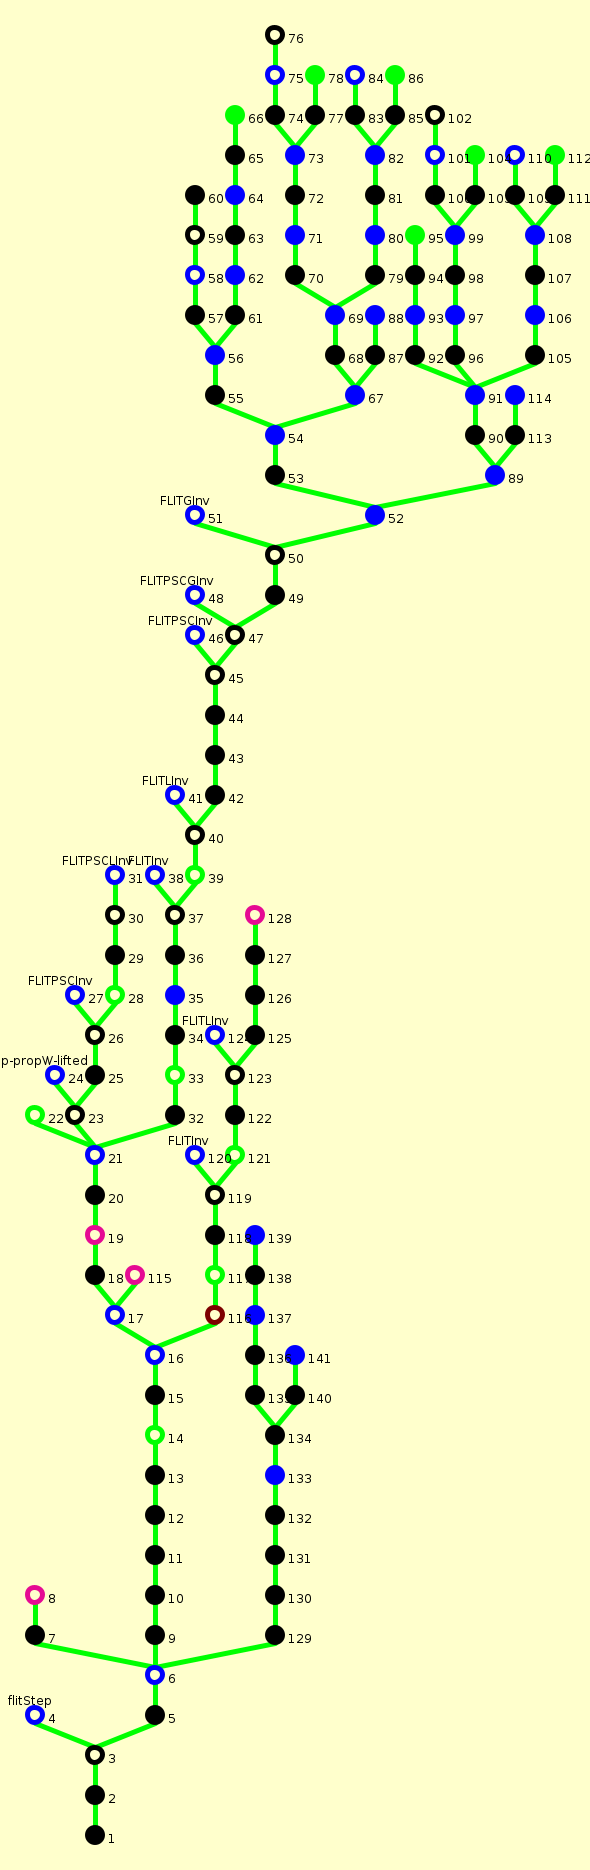
Proof step 1 from proof step-absstep-PROP_W-doWrite (conclusion)
(back to tree)
| FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
flitStep(mkstate(gs, lsf, pcf), doWrite(tid, bq(tid).head.l, bq(tid).head.v), mkstate(gs0, lsf0, pcf0)),
abs(mkstate(gs, lsf, pcf), mkstate(ags, alsf, apcf))
⊦ ∃ ags0, alsf0, apcf0.
flitpscStep(mkstate(ags, alsf, apcf), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v), mkstate(ags0, alsf0, apcf0))
∧ abs(mkstate(gs0, lsf0, pcf0), mkstate(ags0, alsf0, apcf0)) |
System applied rule normalize
And obtained the following new goals
- Proof step 2:
FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), abs(mkstate(gs, lsf, pcf), mkstate(ags, alsf, apcf)),
flitStep(mkstate(gs, lsf, pcf), doWrite(tid, bq(tid).head.l, bq(tid).head.v), mkstate(gs0, lsf0, pcf0))
⊦ ∃ ags0, alsf0, apcf0.
flitpscStep(mkstate(ags, alsf, apcf), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v), mkstate(ags0, alsf0, apcf0))
∧ abs(mkstate(gs0, lsf0, pcf0), mkstate(ags0, alsf0, apcf0))
Rule argument
Additional information
Proof step 2 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), abs(mkstate(gs, lsf, pcf), mkstate(ags, alsf, apcf)),
flitStep(mkstate(gs, lsf, pcf), doWrite(tid, bq(tid).head.l, bq(tid).head.v), mkstate(gs0, lsf0, pcf0))
⊦ ∃ ags0, alsf0, apcf0.
flitpscStep(mkstate(ags, alsf, apcf), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v), mkstate(ags0, alsf0, apcf0))
∧ abs(mkstate(gs0, lsf0, pcf0), mkstate(ags0, alsf0, apcf0)) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 3:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
flitStep(mkstate(gs, lsf, pcf), doWrite(tid, bq(tid).head.l, bq(tid).head.v), mkstate(gs0, lsf0, pcf0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t)))
Rule argument
Additional information
Used simplifier rules:
abs-def: ⊦ abs(mkstate(gs, lsf, pcf), mkstate(ags, alsf, apcf))
↔ gabs(gs, lsf, pcf, ags, alsf, apcf)
∧ (∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)));
gabs-def: ⊦ gabs(gs, lsf, pcf, ags, alsf, apcf)
↔ ags.mem = gs.pmem ∧ ags.ctr = gs.fctr ∧ reorder(ags.p, gs.pq, gs.rfo)
∧ ags.writers = gs.fwriters;
⊦ doWritePSC(t, l, v) ≠ globalPSCCRASH; (s)
⊦ doWritePSC(t, l, v) ≠ globalPSCPERSIST_FO(l0); (s)
⊦ doWritePSC(t, l, v) ≠ globalPSCPERSIST_W(l0); (s)
⊦ lstep(gs, ls, pc, a, gs0, ls0, pc0)
↔ pre(gs, ls, pc, a) ∧ ls0 = lstepf(gs, ls, pc, a) ∧ gs0 = gstepf(gs, ls, pc, a)
∧ pc0 = pcstepf(gs, ls, pc, a); (s)
⊦ flitpscStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc.
lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls)
∧ pcf0 = pcf(t := pc))
∨ (∃ l.
a = globalPSCPERSIST_W(l) ∧ firstPersistW(gs.p(l)) < # gs.p(l)
∧ gs0
= (gs.mem:= gs.mem(l := gs.p(l)[firstPersistW(gs.p(l))].val))
.p:= gs.p(l := gs.p(l) -p firstPersistW(gs.p(l)))
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ l.
a = globalPSCPERSIST_FO(l)
∧ (∃ n. isPersistFO(n, gs.p(l)) ∧ gs0 = gs.p:= gs.p(l := gs.p(l) -p n))
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalPSCCRASH ∧ gs0 = mkFLITPSCgs(gs.mem, λ l. [], λ l. 0, λ l. ∅, λ l. ∅)
∧ lsf0 = lsf ∧ pcf0 = (λ t. (pcf(t) = idle ⊃ idle;crashed)); (s)
Proof step 3 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
flitStep(mkstate(gs, lsf, pcf), doWrite(tid, bq(tid).head.l, bq(tid).head.v), mkstate(gs0, lsf0, pcf0)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t))) |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 4:
⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l))) ∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
- Proof step 5:
(∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v), gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid0.
doWrite(tid, bq(tid).head.l, bq(tid).head.v) = doWrite(tid0, gs.bq(tid0).head.l, gs.bq(tid0).head.v) ∧ (gs.bq(tid0) ≠ [] ∧ gs.bq(tid0).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid0).head.l := gs.pq(gs.bq(tid0).head.l) + W(gs.bq(tid0).head.v, tid0))).bq:= gs.bq(tid0 := gs.bq(tid0).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid0, l.
doWrite(tid, bq(tid).head.l, bq(tid).head.v) = (oneMember(tid0, l, gs.fwriters) ⊃ doWriteFO(tid0, l);propFO(tid0, l))
∧ (∃ n. n < # gs.bq(tid0) ∧ isPropFO(n, l, gs.bq(tid0)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid0, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid0.
doWrite(tid, bq(tid).head.l, bq(tid).head.v) = propSF(tid0) ∧ (gs.bq(tid0) ≠ [] ∧ gs.bq(tid0).head = SF ∧ (∀ l. ¬ FO(tid0) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid0 := gs.bq(tid0).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
doWrite(tid, bq(tid).head.l, bq(tid).head.v) = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
doWrite(tid, bq(tid).head.l, bq(tid).head.v) = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?)
∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ doWrite(tid, bq(tid).head.l, bq(tid).head.v) = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t)))
Rule argument
spec: FLIT, name:flitStep,
seq:⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc.
lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls)
∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v)
∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0
= ( gs
.pq:= gs.pq
(gs.bq(tid).head.l
:= gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid)
))
.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l))
∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo;
PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid)
∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0
= (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val))
.pq:= gs.pq(loc := gs.pq(loc).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?)
∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters,
freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs
:= ( ( (((gs.pq:= pq).fctr:= fctr).bq:= bq)
.fwriters:= fwriters)
.freaders:= freaders)
.rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
subst:[lsf, gs, lsf0, a, pcf, pcf0, gs0]
→ [lsf, gs, lsf0, doWrite(tid, bq(tid).head.l, bq(tid).head.v), pcf, pcf0, gs0],
<all paths>
Additional information
Used terms: pcf0, doWrite(tid, bq(tid).head.l, bq(tid).head.v), lsf, gs0, pcf, lsf0, gs
Proof step 4 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⊦ flitStep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0))
↔ (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), a, gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid.
a = doWrite(tid, gs.bq(tid).head.l, gs.bq(tid).head.v) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid).head.l := gs.pq(gs.bq(tid).head.l) + W(gs.bq(tid).head.v, tid))).bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid, l.
a = (oneMember(tid, l, gs.fwriters) ⊃ doWriteFO(tid, l);propFO(tid, l)) ∧ (∃ n. n < # gs.bq(tid) ∧ isPropFO(n, l, gs.bq(tid)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid.
a = propSF(tid) ∧ (gs.bq(tid) ≠ [] ∧ gs.bq(tid).head = SF ∧ (∀ l. ¬ FO(tid) ∈ gs.pq(l))) ∧ gs0 = gs.bq:= gs.bq(tid := gs.bq(tid).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
a = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?) ∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ a = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf) |
A spec-lemma
Proof step 5 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| (∃ t, ls, pc. lstep(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v), gs0, ls, pc) ∧ lsf0 = lsf(t := ls) ∧ pcf0 = pcf(t := pc))
∨ (∃ tid0.
doWrite(tid, bq(tid).head.l, bq(tid).head.v) = doWrite(tid0, gs.bq(tid0).head.l, gs.bq(tid0).head.v) ∧ (gs.bq(tid0) ≠ [] ∧ gs.bq(tid0).head.W?)
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid0).head.l := gs.pq(gs.bq(tid0).head.l) + W(gs.bq(tid0).head.v, tid0))).bq:= gs.bq(tid0 := gs.bq(tid0).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ tid0, l.
doWrite(tid, bq(tid).head.l, bq(tid).head.v) = (oneMember(tid0, l, gs.fwriters) ⊃ doWriteFO(tid0, l);propFO(tid0, l))
∧ (∃ n. n < # gs.bq(tid0) ∧ isPropFO(n, l, gs.bq(tid0)))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid0, l, fwriters; pq, bq, rfo);
gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf))
∨ (∃ tid0.
doWrite(tid, bq(tid).head.l, bq(tid).head.v) = propSF(tid0) ∧ (gs.bq(tid0) ≠ [] ∧ gs.bq(tid0).head = SF ∧ (∀ l. ¬ FO(tid0) ∈ gs.pq(l)))
∧ gs0 = gs.bq:= gs.bq(tid0 := gs.bq(tid0).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
doWrite(tid, bq(tid).head.l, bq(tid).head.v) = globalPERSIST_W(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.W?)
∧ gs0 = (gs.pmem:= gs.pmem(loc := gs.pq(loc).head.val)).pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ (∃ loc.
doWrite(tid, bq(tid).head.l, bq(tid).head.v) = globalPERSIST_FO(loc) ∧ (gs.pq(loc) ≠ [] ∧ gs.pq(loc).head.FO?)
∧ gs0 = gs.pq:= gs.pq(loc := gs.pq(loc).tail) ∧ lsf0 = lsf ∧ pcf0 = pcf)
∨ doWrite(tid, bq(tid).head.l, bq(tid).head.v) = globalCRASH
∧ ⟨pq := gs.pq, fctr := gs.fctr, bq := gs.bq, fwriters := gs.fwriters, freaders := gs.freaders, rfo := gs.rfo;
CRASH(; pq, fctr, bq, fwriters, freaders, rfo, pcf);
gs := (((((gs.pq:= pq).fctr:= fctr).bq:= bq).fwriters:= fwriters).freaders:= freaders).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t))) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 6:
pre(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v))
∧ ls = lstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v))
∧ gs0 = gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v))
∧ pc = pcstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v))
∧ lsf0 = lsf(t := lstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)))
∧ pcf0 = pcf(t := pcstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)))
∨ doWrite(tid, bq(tid).head.l, bq(tid).head.v) = doWrite(tid0, gs.bq(tid0).head.l, gs.bq(tid0).head.v) ∧ gs.bq(tid0) ≠ [] ∧ gs.bq(tid0).head.W?
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid0).head.l := gs.pq(gs.bq(tid0).head.l) + W(gs.bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := gs.bq(tid0).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf
∨ doWrite(tid, bq(tid).head.l, bq(tid).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)) ∧ n < # gs.bq(tid1)
∧ isPropFO(n, l, gs.bq(tid1))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid1, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t)))
Rule argument
Additional information
Used simplifier rules:
⊦ doWrite(t, loc, v) ≠ globalCRASH; (s)
⊦ doWrite(t, loc, v) ≠ globalPERSIST_FO(loc0); (s)
⊦ doWrite(t, loc, v) ≠ globalPERSIST_W(loc0); (s)
⊦ doWrite(t, loc, v) ≠ propSF(t0); (s)
⊦ x + a = x + a '; (s)
⊦ lstep(gs, ls, pc, a, gs0, ls0, pc0)
↔ pre(gs, ls, pc, a) ∧ ls0 = lstepf(gs, ls, pc, a) ∧ gs0 = gstepf(gs, ls, pc, a)
∧ pc0 = pcstepf(gs, ls, pc, a); (s)
Proof step 6 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| pre(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v))
∧ ls = lstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v))
∧ gs0 = gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v))
∧ pc = pcstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v))
∧ lsf0 = lsf(t := lstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)))
∧ pcf0 = pcf(t := pcstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)))
∨ doWrite(tid, bq(tid).head.l, bq(tid).head.v) = doWrite(tid0, gs.bq(tid0).head.l, gs.bq(tid0).head.v) ∧ gs.bq(tid0) ≠ [] ∧ gs.bq(tid0).head.W?
∧ gs0 = (gs.pq:= gs.pq(gs.bq(tid0).head.l := gs.pq(gs.bq(tid0).head.l) + W(gs.bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := gs.bq(tid0).tail)
∧ lsf0 = lsf ∧ pcf0 = pcf
∨ doWrite(tid, bq(tid).head.l, bq(tid).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)) ∧ n < # gs.bq(tid1)
∧ isPropFO(n, l, gs.bq(tid1))
∧ ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid1, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t))) |
User applied rule case distinction
And obtained the following new goals
- Proof step 7:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs0 = gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)),
ls = lstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)),
lsf0 = lsf(t := lstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v))),
pc = pcstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)),
pcf0 = pcf(t := pcstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v))), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), pre(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t)))
- Proof step 9:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
doWrite(tid, bq(tid).head.l, bq(tid).head.v) = doWrite(tid0, gs.bq(tid0).head.l, gs.bq(tid0).head.v),
gs0 = (gs.pq:= gs.pq(gs.bq(tid0).head.l := gs.pq(gs.bq(tid0).head.l) + W(gs.bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := gs.bq(tid0).tail),
lsf0 = lsf, pcf0 = pcf, gs.bq(tid0) ≠ [], gs.bq(tid0).head.W?, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t)))
- Proof step 129:
⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid1, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
doWrite(tid, bq(tid).head.l, bq(tid).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), n < # gs.bq(tid1),
FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t)))
Rule argument
pos: left 1
Additional information
Proof step 7 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs0 = gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)),
ls = lstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)),
lsf0 = lsf(t := lstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v))),
pc = pcstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)),
pcf0 = pcf(t := pcstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v))), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), pre(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t))) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 8:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf),
FLITInv
(gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)),
lsf(t := lstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v))),
pcf(t := pcstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)))),
FLITPSCInv(ags, alsf, apcf), pre(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))))
∧ ags0.mem = gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)).pmem
∧ ags0.ctr = gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)).fctr
∧ reorder
(ags0.p, gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)).pq,
gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)).rfo)
∧ ags0.writers = gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)).fwriters
∧ (∀ t0.
labs
(gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)),
(t = t0 ⊃ lstepf(gs, lsf(t0), pcf(t0), doWrite(tid, bq(tid).head.l, bq(tid).head.v));lsf(t0)),
(t = t0 ⊃ pcstepf(gs, lsf(t0), pcf(t0), doWrite(tid, bq(tid).head.l, bq(tid).head.v));pcf(t0)), ags0, alsf0(t0), apcf0(t0)))
Rule argument
Additional information
Proof step 8 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, FLITInv(gs, lsf, pcf),
FLITInv
(gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)),
lsf(t := lstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v))),
pcf(t := pcstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)))),
FLITPSCInv(ags, alsf, apcf), pre(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))))
∧ ags0.mem = gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)).pmem
∧ ags0.ctr = gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)).fctr
∧ reorder
(ags0.p, gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)).pq,
gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)).rfo)
∧ ags0.writers = gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)).fwriters
∧ (∀ t0.
labs
(gstepf(gs, lsf(t), pcf(t), doWrite(tid, bq(tid).head.l, bq(tid).head.v)),
(t = t0 ⊃ lstepf(gs, lsf(t0), pcf(t0), doWrite(tid, bq(tid).head.l, bq(tid).head.v));lsf(t0)),
(t = t0 ⊃ pcstepf(gs, lsf(t0), pcf(t0), doWrite(tid, bq(tid).head.l, bq(tid).head.v));pcf(t0)), ags0, alsf0(t0), apcf0(t0))) |
User applied rule constructor cut
And closed the goal!
Rule argument
term: pcf(t)
Additional information
Used simplifier rules:
FLITPC
freely generated by R1, R2, R3, R4, W1, W2, W3, W4, W5, W6, W7, crashed, idle, ready
;;
⊦ gstepf(gs, ls, ready, a) = gs; (s)
⊦ pre(gs, ls, ready, a)
↔ (∃ loc0, val0. a = invFLITWRITE(ls.t, loc0, val0))
∨ (∃ loc0. a = invFLITREAD(ls.t, loc0))
∨ a = callFLITCOMPLETE(ls.t) ∧ gs.bq(ls.t) = [] ∧ (∀ l. ¬ FO(ls.t) ∈ gs.pq(l)); (s)
⊦ doWrite(t, loc, v) ≠ invFLITWRITE(t0, loc0, v0); (s)
⊦ doWrite(t, loc, v) ≠ invFLITREAD(t0, loc0); (s)
⊦ callFLITCOMPLETE(t) ≠ doWrite(t0, loc, v); (s)
⊦ pre(gs, ls, idle, a) ↔ a = callRUN(ls.t); (s)
⊦ callRUN(t) ≠ doWrite(t0, loc, v); (s)
⊦ pre(gs, ls, crashed, a) ↔ false; (s)
⊦ pcstepf(gs, ls, W7, a) = ready; (s)
⊦ pre(gs, ls, W7, a) ↔ a = retFLITWRITE(ls.t); (s)
⊦ doWrite(t, loc, v) ≠ retFLITWRITE(t0); (s)
⊦ gstepf(gs, ls, W6, a)
= (gs.fctr:= gs.fctr(ls.loc := gs.fctr(ls.loc) - 1))
.fwriters:= gs.fwriters(ls.loc := gs.fwriters(ls.loc) -- ls.t); (s)
⊦ lstepf(gs, ls, W6, a) = ls; (s)
⊦ pcstepf(gs, ls, W6, a) = W7; (s)
⊦ pre(gs, ls, W6, a)
↔ (gs.bq(ls.t) = [] ∧ (∀ l. ¬ FO(ls.t) ∈ gs.pq(l))) ∧ a = ctrDec(ls.t, ls.loc); (s)
⊦ ctrDec(t, loc) ≠ doWrite(t0, loc0, v); (s)
⊦ pcstepf(gs, ls, W5, a) = W6; (s)
⊦ pre(gs, ls, W5, a) ↔ a = τ; (s)
⊦ doWrite(t, loc, v) ≠ τ; (s)
⊦ pcstepf(gs, ls, W4, a) = W5; (s)
⊦ pre(gs, ls, W4, a) ↔ a = τ; (s)
⊦ pcstepf(gs, ls, W3, a) = W4; (s)
⊦ pre(gs, ls, W3, a) ↔ a = τ; (s)
⊦ gstepf(gs, ls, W2, a)
= (gs.fctr:= gs.fctr(ls.loc := gs.fctr(ls.loc) + 1))
.fwriters:= gs.fwriters(ls.loc := gs.fwriters(ls.loc) ++ ls.t); (s)
⊦ lstepf(gs, ls, W2, a) = ls; (s)
⊦ pcstepf(gs, ls, W2, a) = W3; (s)
⊦ pre(gs, ls, W2, a)
↔ (gs.bq(ls.t) = [] ∧ (∀ l. ¬ FO(ls.t) ∈ gs.pq(l))) ∧ a = ctrInc(ls.t, ls.loc); (s)
⊦ ctrInc(t, loc) ≠ doWrite(t0, loc0, v); (s)
⊦ gstepf(gs, ls, W1, a) = gs.bq:= gs.bq(ls.t := gs.bq(ls.t) + SF); (s)
⊦ x + a = x + a '; (s)
⊦ lstepf(gs, ls, W1, a) = ls; (s)
⊦ pcstepf(gs, ls, W1, a) = W2; (s)
⊦ pre(gs, ls, W1, a) ↔ a = sfence(ls.t); (s)
⊦ doWrite(t, loc, v) ≠ sfence(t0); (s)
⊦ pcstepf(gs, ls, R4, a) = ready; (s)
⊦ pre(gs, ls, R4, a) ↔ a = retFLITREAD(ls.t, ls.val); (s)
⊦ doWrite(t, loc, v) ≠ retFLITREAD(t0, v0); (s)
⊦ gstepf(gs, ls, R3, a)
= ( (gs.bq:= gs.bq(ls.t := gs.bq(ls.t) + FO(ls.loc)))
.rfo:= gs.rfo(ls.t := gs.rfo(ls.t) + FO(ls.loc)))
.freaders:= gs.freaders(ls.loc := gs.freaders(ls.loc) -- ls.t); (s)
⊦ lstepf(gs, ls, R3, a) = ls; (s)
⊦ pcstepf(gs, ls, R3, a) = R4; (s)
⊦ pre(gs, ls, R3, a) ↔ a = pwb(ls.t, ls.loc); (s)
⊦ doWrite(t, loc, v) ≠ pwb(t0, loc0); (s)
⊦ gstepf(gs, ls, R2, a)
= (gs.fctr(ls.loc) ≠ 0
⊃ gs
;gs.freaders:= gs.freaders(ls.loc := gs.freaders(ls.loc) -- ls.t)
); (s)
⊦ lstepf(gs, ls, R2, a) = ls; (s)
⊦ pcstepf(gs, ls, R2, a) = (gs.fctr(ls.loc) ≠ 0 ⊃ R3;R4); (s)
⊦ pre(gs, ls, R2, a) ↔ a = ctrRead(ls.t, ls.loc, gs.fctr(ls.loc)); (s)
⊦ ctrRead(t, loc, n) ≠ doWrite(t0, loc0, v); (s)
⊦ gstepf(gs, ls, R1, a) = gs.freaders:= gs.freaders(ls.loc := gs.freaders(ls.loc) ++ ls.t); (s)
⊦ lstepf(gs, ls, R1, a) = ls.val:= (((gs.pmem ⊕ gs.pq) ⊕ gs.bq(ls.t)))(ls.loc); (s)
⊦ pcstepf(gs, ls, R1, a) = R2; (s)
⊦ pre(gs, ls, R1, a) ↔ a = doRead(ls.t, ls.loc, ((gs.pmem ⊕ gs.pq))(ls.loc)); (s)
⊦ ((mem ⊕ p))(l) = mem(l) ⊕ p(l); (s)
⊦ reorder(p, pq, rfo) → v ⊕ pq(l) = v ⊕ p(l); (s)
⊦ doRead(t, loc, v) ≠ doWrite(t0, loc0, v0); (s)
Proof step 9 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
doWrite(tid, bq(tid).head.l, bq(tid).head.v) = doWrite(tid0, gs.bq(tid0).head.l, gs.bq(tid0).head.v),
gs0 = (gs.pq:= gs.pq(gs.bq(tid0).head.l := gs.pq(gs.bq(tid0).head.l) + W(gs.bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := gs.bq(tid0).tail),
lsf0 = lsf, pcf0 = pcf, gs.bq(tid0) ≠ [], gs.bq(tid0).head.W?, FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t))) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 10:
ags.ctr = gs.fctr, bq(tid0).head.l = gs.bq(tid0).head.l, ags.mem = gs.pmem, bq(tid0).head.v = gs.bq(tid0).head.v, ags.writers = gs.fwriters,
gs.bq(tid0) ≠ [], gs.bq(tid0).head.W?,
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := gs.bq(tid0).tail), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ ags0.writers = gs.fwriters
∧ (∀ t.
labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := gs.bq(tid0).tail), lsf(t), pcf(t),
ags0, alsf0(t), apcf0(t)))
Rule argument
Additional information
Used simplifier rules:
⊦ (gs.pq:= pq).fwriters = gs.fwriters; (s)
⊦ (gs.bq:= bq).fwriters = gs.fwriters; (s)
⊦ (gs.pq:= pq).rfo = gs.rfo; (s)
⊦ (gs.bq:= bq).rfo = gs.rfo; (s)
⊦ (gs.pq:= pq).pq = pq; (s)
⊦ (gs.bq:= bq).pq = gs.pq; (s)
⊦ (gs.pq:= pq).fctr = gs.fctr; (s)
⊦ (gs.bq:= bq).fctr = gs.fctr; (s)
⊦ (gs.pq:= pq).pmem = gs.pmem; (s)
⊦ (gs.bq:= bq).pmem = gs.pmem; (s)
⊦ doWrite(t, loc, v) = doWrite(t0, loc0, v0) ↔ t = t0 ∧ loc = loc0 ∧ v = v0; (ws)
Proof step 10 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ags.ctr = gs.fctr, bq(tid0).head.l = gs.bq(tid0).head.l, ags.mem = gs.pmem, bq(tid0).head.v = gs.bq(tid0).head.v, ags.writers = gs.fwriters,
gs.bq(tid0) ≠ [], gs.bq(tid0).head.W?,
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := gs.bq(tid0).tail), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ ags0.writers = gs.fwriters
∧ (∀ t.
labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := gs.bq(tid0).tail), lsf(t), pcf(t),
ags0, alsf0(t), apcf0(t))) |
Heuristic elimination applied rule apply elim lemma
And obtained the following new goals
- Proof step 11:
ags.ctr = gs.fctr, gs.bq(tid0).head = W(l, v), bq(tid0).head.l = l, ags.mem = gs.pmem, bq(tid0).head.v = v, ags.writers = gs.fwriters,
gs.bq(tid0) ≠ [], gs.bq(tid0).head.W?, FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := gs.bq(tid0).tail), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ ags0.writers = gs.fwriters
∧ (∀ t.
labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := gs.bq(tid0).tail), lsf(t), pcf(t),
ags0, alsf0(t), apcf0(t)))
Rule argument
spec: Bevent, name:elim-W, seq: ⊦ be.W? → (l = be.l ∧ v = be.v ↔ be = W(l, v)),
subst:[be, l, v] → [gs.bq(tid0).head, l, v]
Additional information
Used simplifier rules:
⊦ be.W? → (l = be.l ∧ v = be.v ↔ be = W(l, v)); (elim)
Used terms: gs.bq(tid0).head, l, v
Proof step 11 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ags.ctr = gs.fctr, gs.bq(tid0).head = W(l, v), bq(tid0).head.l = l, ags.mem = gs.pmem, bq(tid0).head.v = v, ags.writers = gs.fwriters,
gs.bq(tid0) ≠ [], gs.bq(tid0).head.W?, FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := gs.bq(tid0).tail), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ ags0.writers = gs.fwriters
∧ (∀ t.
labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := gs.bq(tid0).tail), lsf(t), pcf(t),
ags0, alsf0(t), apcf0(t))) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 12:
ags.ctr = gs.fctr, gs.bq(tid0).head = W(bq(tid0).head.l, bq(tid0).head.v), ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.bq(tid0) ≠ [],
FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := gs.bq(tid0).tail), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ ags0.writers = gs.fwriters
∧ (∀ t.
labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := gs.bq(tid0).tail), lsf(t), pcf(t),
ags0, alsf0(t), apcf0(t)))
Rule argument
Additional information
Used simplifier rules:
⊦ W(l, v).W?; (s)
Proof step 12 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ags.ctr = gs.fctr, gs.bq(tid0).head = W(bq(tid0).head.l, bq(tid0).head.v), ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.bq(tid0) ≠ [],
FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := gs.bq(tid0).tail), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ ags0.writers = gs.fwriters
∧ (∀ t.
labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := gs.bq(tid0).tail), lsf(t), pcf(t),
ags0, alsf0(t), apcf0(t))) |
Heuristic elimination applied rule apply elim lemma
And obtained the following new goals
- Proof step 13:
gs.bq(tid0) = head + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, head = W(bq(tid0).head.l, bq(tid0).head.v),
gs.bq(tid0) ≠ [], FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ ags0.writers = gs.fwriters
∧ (∀ t.
labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t), ags0,
alsf0(t), apcf0(t)))
Rule argument
spec: list-data, name:elim-add,
seq: ⊦ x ≠ [] → (head = x.head ∧ tail = x.tail ↔ x = head + tail),
subst:[x, head, tail] → [gs.bq(tid0), head, bel]; ['a] → [Bevent]
Additional information
Used simplifier rules:
⊦ x ≠ [] → (head = x.head ∧ tail = x.tail ↔ x = head + tail); (elim)
Used terms: gs.bq(tid0), head, bel
Proof step 13 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = head + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, head = W(bq(tid0).head.l, bq(tid0).head.v),
gs.bq(tid0) ≠ [], FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ ags0.writers = gs.fwriters
∧ (∀ t.
labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t), ags0,
alsf0(t), apcf0(t))) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 14:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.bq(tid0) ≠ [],
FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ ags0.writers = gs.fwriters
∧ (∀ t.
labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t), ags0,
alsf0(t), apcf0(t)))
Rule argument
Additional information
Used simplifier rules:
a: ⊦ (x + y) + z = x + y + z; from specification list
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
⊦ a + x = a ' + x; (s)
Proof step 14 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.bq(tid0) ≠ [],
FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ ags0.writers = gs.fwriters
∧ (∀ t.
labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t), ags0,
alsf0(t), apcf0(t))) |
User applied rule exists right
And obtained the following new goals
- Proof step 15:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
= gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf(tid0 := lstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf(tid0 := pcstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).mem = gs.pmem
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).ctr = gs.fctr
∧ reorder
(gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).p,
gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).writers = gs.fwriters
∧ (∀ t.
labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
alsf(tid0 := lstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))(t),
apcf(tid0 := pcstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))(t)))
Rule argument
pos: right 1
terms: gstepf
(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
alsf
(tid0
:= lstepf
(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
),
apcf
(tid0
:= pcstepf
(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
)
abort: F
discard: T
computed: F
Additional information
Used terms: gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)), alsf
(tid0
:= lstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
), apcf
(tid0
:= pcstepf
(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
)
Proof step 15 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
= gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf(tid0 := lstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf(tid0 := pcstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).mem = gs.pmem
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).ctr = gs.fctr
∧ reorder
(gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).p,
gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).writers = gs.fwriters
∧ (∀ t.
labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
alsf(tid0 := lstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))(t),
apcf(tid0 := pcstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))(t))) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 16:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.bq(tid0) ≠ [],
FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
= gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf(tid0 := lstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf(tid0 := pcstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).mem = gs.pmem
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).ctr = gs.fctr
∧ reorder
(gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).p,
gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).writers = gs.fwriters
∧ labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)))
Rule argument
Additional information
Proof step 16 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.bq(tid0) ≠ [],
FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
= gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf(tid0 := lstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf(tid0 := pcstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).mem = gs.pmem
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).ctr = gs.fctr
∧ reorder
(gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).p,
gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).writers = gs.fwriters
∧ labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))) |
User applied rule cut formula
And obtained the following new goals
- Proof step 17:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
= gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf(tid0 := lstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf(tid0 := pcstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).mem = gs.pmem
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).ctr = gs.fctr
∧ reorder
(gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).p,
gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).writers = gs.fwriters
∧ labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)))
- Proof step 116:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
= gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf(tid0 := lstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf(tid0 := pcstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).mem = gs.pmem
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).ctr = gs.fctr
∧ reorder
(gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).p,
gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).writers = gs.fwriters
∧ labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)))
Rule argument
fma: pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
Additional information
Used formulas: pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
Proof step 17 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
= gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf(tid0 := lstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf(tid0 := pcstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).mem = gs.pmem
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).ctr = gs.fctr
∧ reorder
(gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).p,
gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).writers = gs.fwriters
∧ labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))) |
User applied rule cut formula
And obtained the following new goals
- Proof step 18:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, apcf(tid0) = W3,
gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)), reorder(ags.p, gs.pq, gs.rfo),
W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
= gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf(tid0 := lstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf(tid0 := pcstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).mem = gs.pmem
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).ctr = gs.fctr
∧ reorder
(gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).p,
gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).writers = gs.fwriters
∧ labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)))
- Proof step 115:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.bq(tid0) ≠ [],
apcf(tid0) ≠ W3, FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)), reorder(ags.p, gs.pq, gs.rfo),
W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
= gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf(tid0 := lstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf(tid0 := pcstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).mem = gs.pmem
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).ctr = gs.fctr
∧ reorder
(gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).p,
gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).writers = gs.fwriters
∧ labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)))
Rule argument
fma: apcf(tid0) = W3
Additional information
Used formulas: apcf(tid0) = W3
Proof step 18 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, apcf(tid0) = W3,
gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)), reorder(ags.p, gs.pq, gs.rfo),
W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
= gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf(tid0 := lstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf(tid0 := pcstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).mem = gs.pmem
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).ctr = gs.fctr
∧ reorder
(gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).p,
gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).writers = gs.fwriters
∧ labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 19:
gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t0.
pre(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))
∧ ags.p:= ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')
= gstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))
∧ alsf(tid0 := alsf(tid0)) = alsf(t0 := lstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v)))
∧ apcf(tid0 := W4) = apcf(t0 := pcstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))))
∧ reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '),
gs.rfo)
∧ labs
((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
ags.p:= ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)))
Rule argument
Additional information
Used simplifier rules:
a: ⊦ (x + y) + z = x + y + z; from specification list
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
⊦ x + a = x + a '; (s)
⊦ gstepf(gs, ls, W3, a) = gs.p:= gs.p(ls.l := gs.p(ls.l) + W(ls.v, ls.t)); (s)
⊦ (gs.p:= p).writers = gs.writers; (s)
⊦ (gs.p:= p).p = p; (s)
⊦ (gs.p:= p).ctr = gs.ctr; (s)
⊦ (gs.p:= p).mem = gs.mem; (s)
⊦ pcstepf(gs, ls, W3, a) = W4; (s)
⊦ lstepf(gs, ls, W3, a) = ls; (s)
⊦ doWritePSC(t, l, v) = doWritePSC(t0, l0, v0) ↔ t = t0 ∧ l = l0 ∧ v = v0; (ws)
⊦ pre(gs, ls, W3, a) ↔ a = doWritePSC(ls.t, ls.l, ls.v); (s)
Proof step 19 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t0.
pre(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))
∧ ags.p:= ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')
= gstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))
∧ alsf(tid0 := alsf(tid0)) = alsf(t0 := lstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v)))
∧ apcf(tid0 := W4) = apcf(t0 := pcstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))))
∧ reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '),
gs.rfo)
∧ labs
((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
ags.p:= ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))) |
User applied rule constructor cut
And obtained the following new goals
- Proof step 20:
gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t0.
pre(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))
∧ ags.p:= ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')
= gstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))
∧ alsf(tid0 := alsf(tid0)) = alsf(t0 := lstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v)))
∧ apcf(tid0 := W4) = apcf(t0 := pcstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))))
∧ reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '),
gs.rfo)
∧ labs
((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
ags.p:= ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)))
Rule argument
term: apcf(tid0)
Additional information
Used simplifier rules:
FLITPSCPC
freely generated by R1, R2, R3, R4, W1, W2, W3, W4, W5, W6, W7, crashed, idle, ready
;;
⊦ W3 ≠ ready; (s)
⊦ W3 ≠ idle; (s)
⊦ W3 ≠ crashed; (s)
⊦ W3 ≠ W7; (s)
⊦ W3 ≠ W6; (s)
⊦ W3 ≠ W5; (s)
⊦ W3 ≠ W4; (s)
⊦ W2 ≠ W3; (s)
⊦ W1 ≠ W3; (s)
⊦ R4 ≠ W3; (s)
⊦ R3 ≠ W3; (s)
⊦ R2 ≠ W3; (s)
⊦ R1 ≠ W3; (s)
Proof step 20 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t0.
pre(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))
∧ ags.p:= ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')
= gstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))
∧ alsf(tid0 := alsf(tid0)) = alsf(t0 := lstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v)))
∧ apcf(tid0 := W4) = apcf(t0 := pcstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))))
∧ reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '),
gs.rfo)
∧ labs
((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
ags.p:= ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 21:
gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t0.
pre(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))
∧ ags.p:= ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')
= gstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))
∧ alsf(tid0 := alsf(tid0)) = alsf(t0 := lstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v)))
∧ apcf(tid0 := W4) = apcf(t0 := pcstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))))
∧ reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '),
gs.rfo)
∧ labs
((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
ags.p:= ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)))
Rule argument
Additional information
Proof step 21 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t0.
pre(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))
∧ ags.p:= ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')
= gstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))
∧ alsf(tid0 := alsf(tid0)) = alsf(t0 := lstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v)))
∧ apcf(tid0 := W4) = apcf(t0 := pcstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))))
∧ reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '),
gs.rfo)
∧ labs
((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
ags.p:= ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))) |
User applied rule case distinction
And obtained the following new goals
- Proof step 22:
gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ t0.
pre(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))
∧ ags.p:= ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')
= gstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))
∧ alsf(tid0 := alsf(tid0)) = alsf(t0 := lstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v)))
∧ apcf(tid0 := W4) = apcf(t0 := pcstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v)))
- Proof step 23:
gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0),
¬
reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
- Proof step 32:
gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0),
¬
labs
((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
ags.p:= ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: right 1
Additional information
Proof step 22 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ t0.
pre(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))
∧ ags.p:= ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')
= gstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))
∧ alsf(tid0 := alsf(tid0)) = alsf(t0 := lstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v)))
∧ apcf(tid0 := W4) = apcf(t0 := pcstepf(ags, alsf(t0), apcf(t0), doWritePSC(tid0, alsf(tid0).l, alsf(tid0).v))) |
User applied rule exists right
And closed the goal!
Rule argument
pos: right 1 terms: tid0 abort: F discard: T computed: F
Additional information
Used simplifier rules:
⊦ pre(gs, ls, W3, a) ↔ a = doWritePSC(ls.t, ls.l, ls.v); (s)
⊦ doWritePSC(t, l, v) = doWritePSC(t0, l0, v0) ↔ t = t0 ∧ l = l0 ∧ v = v0; (ws)
⊦ gstepf(gs, ls, W3, a) = gs.p:= gs.p(ls.l := gs.p(ls.l) + W(ls.v, ls.t)); (s)
⊦ x + a = x + a '; (s)
⊦ lstepf(gs, ls, W3, a) = ls; (s)
⊦ pcstepf(gs, ls, W3, a) = W4; (s)
Used terms: tid0
Proof step 23 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0),
¬
reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 24:
⊦ reorder(p, pq, rfo) ∧ noPending(t, p) → reorder(p(l := p(l) + W(v, t) '), pq(l := pq(l) + W(v, t) '), rfo)
- Proof step 25:
gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0),
¬
reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ reorder(ags.p, gs.pq, gs.rfo) ∧ noPending(tid0, ags.p)
Rule argument
spec: abs-FLIT-FLITPSCweak, name:reorder-step-propW-lifted,
seq:⊦ reorder(p, pq, rfo) ∧ noPending(t, p)
→ reorder(p(l := p(l) + W(v, t) '), pq(l := pq(l) + W(v, t) '), rfo),
subst:[t, l, v, p, pq, rfo] → [tid0, alsf(tid0).l, alsf(tid0).v, ags.p, gs.pq, gs.rfo],
<all paths>
Additional information
Used terms: alsf(tid0).v, alsf(tid0).l, gs.rfo, tid0, gs.pq, ags.p
Proof step 24 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⊦ reorder(p, pq, rfo) ∧ noPending(t, p) → reorder(p(l := p(l) + W(v, t) '), pq(l := pq(l) + W(v, t) '), rfo) |
A spec-lemma
Proof step 25 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0),
¬
reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ reorder(ags.p, gs.pq, gs.rfo) ∧ noPending(tid0, ags.p) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 26:
gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0), ¬ noPending(tid0, ags.p),
¬
reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 26 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0), ¬ noPending(tid0, ags.p),
¬
reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 27:
⊦ FLITPSCInv(gs, lsf, pcf) ↔ FLITPSCGInv(gs) ∧ (∀ t. lsf(t).t = t ∧ FLITPSCLInv(gs, lsf(t), pcf(t)))
- Proof step 28:
gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITPSCGInv(ags),
reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0), ¬ noPending(tid0, ags.p),
¬
reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦
Rule argument
spec: FLITPSCweak, name:FLITPSCInv,
seq:⊦ FLITPSCInv(gs, lsf, pcf)
↔ FLITPSCGInv(gs) ∧ (∀ t. lsf(t).t = t ∧ FLITPSCLInv(gs, lsf(t), pcf(t))),
subst:[gs, lsf, pcf] → [ags, alsf, apcf], <all paths>
Additional information
Used terms: ags, alsf, apcf
Proof step 27 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⊦ FLITPSCInv(gs, lsf, pcf) ↔ FLITPSCGInv(gs) ∧ (∀ t. lsf(t).t = t ∧ FLITPSCLInv(gs, lsf(t), pcf(t))) |
A spec-lemma
Proof step 28 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITPSCGInv(ags),
reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0), ¬ noPending(tid0, ags.p),
¬
reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ |
User applied rule all left
And obtained the following new goals
- Proof step 29:
gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem, alsf(tid0).t = tid0,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCGInv(ags), FLITPSCLInv(ags, alsf(tid0), apcf(tid0)), reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0),
¬ noPending(tid0, ags.p),
¬
reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 18 terms: tid0 abort: F discard: T computed: F
Additional information
Used terms: tid0
Proof step 29 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem, alsf(tid0).t = tid0,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCGInv(ags), FLITPSCLInv(ags, alsf(tid0), apcf(tid0)), reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0),
¬ noPending(tid0, ags.p),
¬
reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 30:
gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem, alsf(tid0).t = tid0,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITPSCGInv(ags),
FLITPSCLInv(ags, alsf(tid0), W3), reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0), ¬ noPending(tid0, ags.p),
¬
reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 30 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem, alsf(tid0).t = tid0,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITPSCGInv(ags),
FLITPSCLInv(ags, alsf(tid0), W3), reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0), ¬ noPending(tid0, ags.p),
¬
reorder
(ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) '), gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 31:
⊦ FLITPSCLInv(gs, ls, pc)
↔ (pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7 → notMember(ls.t, gs.readers))
∧ (pc = W1 ∨ pc = W2 ∨ pc = W7 → notMember(ls.t, gs.writers)) ∧ (pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 → oneMember(ls.t, ls.l, gs.writers))
∧ (pc = W1 ∨ pc = W2 → noPendingW(ls.t, gs.p)) ∧ (pc = W2 ∨ pc = W3 ∨ pc = W6 ∨ pc = W7 → noPending(ls.t, gs.p))
∧ (pc = W4 ∨ pc = W5 → onePendingW(ls.t, ls.l, gs.p)) ∧ (pc = W5 → FOFollowsW(ls.t, gs.p(ls.l)))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → notMember(ls.t, gs.writers)) ∧ (pc = R1 ∨ pc = R4 → notMember(ls.t, gs.readers))
∧ (pc = R2 ∨ pc = R3 → oneMember(ls.t, ls.l, gs.readers)) ∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → noPendingW(ls.t, gs.p))
∧ (pc = idle ∨ pc = ready → notMember(ls.t, gs.writers)) ∧ (pc = idle ∨ pc = ready → notMember(ls.t, gs.readers))
∧ (pc = idle ∨ pc = ready → noPendingW(ls.t, gs.p)) ∧ (pc = idle → noPending(ls.t, gs.p))
Rule argument
spec: FLITPSCweak, name:FLITPSCLInv,
seq:⊦ FLITPSCLInv(gs, ls, pc)
↔ ( pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7
→ notMember(ls.t, gs.readers))
∧ (pc = W1 ∨ pc = W2 ∨ pc = W7 → notMember(ls.t, gs.writers))
∧ (pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 → oneMember(ls.t, ls.l, gs.writers))
∧ (pc = W1 ∨ pc = W2 → noPendingW(ls.t, gs.p))
∧ (pc = W2 ∨ pc = W3 ∨ pc = W6 ∨ pc = W7 → noPending(ls.t, gs.p))
∧ (pc = W4 ∨ pc = W5 → onePendingW(ls.t, ls.l, gs.p))
∧ (pc = W5 → FOFollowsW(ls.t, gs.p(ls.l)))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → notMember(ls.t, gs.writers))
∧ (pc = R1 ∨ pc = R4 → notMember(ls.t, gs.readers))
∧ (pc = R2 ∨ pc = R3 → oneMember(ls.t, ls.l, gs.readers))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → noPendingW(ls.t, gs.p))
∧ (pc = idle ∨ pc = ready → notMember(ls.t, gs.writers))
∧ (pc = idle ∨ pc = ready → notMember(ls.t, gs.readers))
∧ (pc = idle ∨ pc = ready → noPendingW(ls.t, gs.p))
∧ (pc = idle → noPending(ls.t, gs.p)),
subst:[gs, ls, pc] → [ags, alsf(tid0), W3], <all paths>
Additional information
Used simplifier rules:
⊦ W3 ≠ idle; (s)
⊦ W3 ≠ ready; (s)
⊦ R1 ≠ W3; (s)
⊦ R2 ≠ W3; (s)
⊦ R3 ≠ W3; (s)
⊦ R4 ≠ W3; (s)
⊦ W3 ≠ W4; (s)
⊦ W3 ≠ W5; (s)
⊦ W3 ≠ W7; (s)
⊦ W1 ≠ W3; (s)
⊦ W2 ≠ W3; (s)
Used terms: ags, alsf(tid0), W3
Proof step 31 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⊦ FLITPSCLInv(gs, ls, pc)
↔ (pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7 → notMember(ls.t, gs.readers))
∧ (pc = W1 ∨ pc = W2 ∨ pc = W7 → notMember(ls.t, gs.writers)) ∧ (pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 → oneMember(ls.t, ls.l, gs.writers))
∧ (pc = W1 ∨ pc = W2 → noPendingW(ls.t, gs.p)) ∧ (pc = W2 ∨ pc = W3 ∨ pc = W6 ∨ pc = W7 → noPending(ls.t, gs.p))
∧ (pc = W4 ∨ pc = W5 → onePendingW(ls.t, ls.l, gs.p)) ∧ (pc = W5 → FOFollowsW(ls.t, gs.p(ls.l)))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → notMember(ls.t, gs.writers)) ∧ (pc = R1 ∨ pc = R4 → notMember(ls.t, gs.readers))
∧ (pc = R2 ∨ pc = R3 → oneMember(ls.t, ls.l, gs.readers)) ∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → noPendingW(ls.t, gs.p))
∧ (pc = idle ∨ pc = ready → notMember(ls.t, gs.writers)) ∧ (pc = idle ∨ pc = ready → notMember(ls.t, gs.readers))
∧ (pc = idle ∨ pc = ready → noPendingW(ls.t, gs.p)) ∧ (pc = idle → noPending(ls.t, gs.p)) |
A spec-lemma
Proof step 32 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0),
¬
labs
((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
ags.p:= ags.p(alsf(tid0).l := ags.p(alsf(tid0).l) + W(alsf(tid0).v, tid0) '),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 33:
gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ ( pcf(t) = W2
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (SF ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W1;W2))
∧ (pcf(t) = W3 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W3;(FO(lsf(t).loc) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W4;(SF ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W5;W6))
))
∧ (pcf(t) = W7 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
Additional information
Used simplifier rules:
labs-def: ⊦ labs(gs, ls, pc, ags, als, apc)
↔ ls.t = als.t ∧ (pc = idle → apc = idle) ∧ (pc = ready → apc = ready)
∧ (pc = crashed → apc = crashed) ∧ (pc = R1 → apc = R1) ∧ (pc = R2 → apc = R2)
∧ (pc = R3 → apc = R3) ∧ (pc = R4 → apc = R4)
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → ls.loc = als.l)
∧ (pc = R2 ∨ pc = R3 ∨ pc = R4 → ls.val = als.v) ∧ (pc = W1 → apc = W1)
∧ (pc = W2 → apc = (SF ∈ gs.bq(ls.t) ⊃ W1;W2)) ∧ (pc = W3 → apc = W3)
∧ (pc = W4 → apc = (W(ls.loc, ls.val) ∈ gs.bq(ls.t) ⊃ W3;W4))
∧ ( pc = W5
→ apc = (W(ls.loc, ls.val) ∈ gs.bq(ls.t) ⊃ W3;(FO(ls.loc) ∈ gs.bq(ls.t) ⊃ W4;W5)))
∧ ( pc = W6
→ apc
= (W(ls.loc, ls.val) ∈ gs.bq(ls.t)
⊃ W3
;(FO(ls.loc) ∈ gs.bq(ls.t) ⊃ W4;(SF ∈ gs.bq(ls.t) ⊃ W5;W6))
))
∧ (pc = W7 → apc = W7)
∧ ( pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7
→ ls.loc = als.l)
∧ ( pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7
→ ls.val = als.v);
⊦ (gs.bq:= bq).bq = bq; (s)
Proof step 33 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ ( pcf(t) = W2
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (SF ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W1;W2))
∧ (pcf(t) = W3 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W3;(FO(lsf(t).loc) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W4;(SF ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W5;W6))
))
∧ (pcf(t) = W7 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
User applied rule all left
And obtained the following new goals
- Proof step 34:
gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), reorder(ags.p, gs.pq, gs.rfo),
W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ ( pcf(t) = W2
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (SF ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W1;W2))
∧ (pcf(t) = W3 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W3;(FO(lsf(t).loc) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W4;(SF ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W5;W6))
))
∧ (pcf(t) = W7 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
pos: left 15 terms: t abort: F discard: F computed: F
Additional information
Used terms: t
Proof step 34 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), reorder(ags.p, gs.pq, gs.rfo),
W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ lsf(t).t = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ ( pcf(t) = W2
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (SF ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W1;W2))
∧ (pcf(t) = W3 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W3;(FO(lsf(t).loc) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W4;(SF ∈ (tid0 = lsf(t).t ⊃ bel;gs.bq(lsf(t).t)) ⊃ W5;W6))
))
∧ (pcf(t) = W7 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 35:
gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem, lsf(t).t = alsf(t).t,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0), pcf(t) = idle → apcf(t) = idle, pcf(t) = ready → apcf(t) = ready,
pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2, pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = W1 → apcf(t) = W1, pcf(t) = W2 → apcf(t) = (SF ∈ gs.bq(alsf(t).t) ⊃ W1;W2), pcf(t) = W3 → apcf(t) = W3,
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;W4),
pcf(t) = W5 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;W5)),
pcf(t) = W6 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;(SF ∈ gs.bq(alsf(t).t) ⊃ W5;W6))),
pcf(t) = W7 → apcf(t) = W7, pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ alsf(t).t = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ ( pcf(t) = W2
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (SF ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W1;W2))
∧ (pcf(t) = W3 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W4;W5)
))
∧ ( pcf(t) = W6
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W4;(SF ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W5;W6))
))
∧ (pcf(t) = W7 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
Additional information
Used simplifier rules:
labs-def: ⊦ labs(gs, ls, pc, ags, als, apc)
↔ ls.t = als.t ∧ (pc = idle → apc = idle) ∧ (pc = ready → apc = ready)
∧ (pc = crashed → apc = crashed) ∧ (pc = R1 → apc = R1) ∧ (pc = R2 → apc = R2)
∧ (pc = R3 → apc = R3) ∧ (pc = R4 → apc = R4)
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → ls.loc = als.l)
∧ (pc = R2 ∨ pc = R3 ∨ pc = R4 → ls.val = als.v) ∧ (pc = W1 → apc = W1)
∧ (pc = W2 → apc = (SF ∈ gs.bq(ls.t) ⊃ W1;W2)) ∧ (pc = W3 → apc = W3)
∧ (pc = W4 → apc = (W(ls.loc, ls.val) ∈ gs.bq(ls.t) ⊃ W3;W4))
∧ ( pc = W5
→ apc = (W(ls.loc, ls.val) ∈ gs.bq(ls.t) ⊃ W3;(FO(ls.loc) ∈ gs.bq(ls.t) ⊃ W4;W5)))
∧ ( pc = W6
→ apc
= (W(ls.loc, ls.val) ∈ gs.bq(ls.t)
⊃ W3
;(FO(ls.loc) ∈ gs.bq(ls.t) ⊃ W4;(SF ∈ gs.bq(ls.t) ⊃ W5;W6))
))
∧ (pc = W7 → apc = W7)
∧ ( pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7
→ ls.loc = als.l)
∧ ( pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7
→ ls.val = als.v);
Proof step 35 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem, lsf(t).t = alsf(t).t,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITPSCInv(ags, alsf, apcf),
reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0), pcf(t) = idle → apcf(t) = idle, pcf(t) = ready → apcf(t) = ready,
pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2, pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = W1 → apcf(t) = W1, pcf(t) = W2 → apcf(t) = (SF ∈ gs.bq(alsf(t).t) ⊃ W1;W2), pcf(t) = W3 → apcf(t) = W3,
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;W4),
pcf(t) = W5 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;W5)),
pcf(t) = W6 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;(SF ∈ gs.bq(alsf(t).t) ⊃ W5;W6))),
pcf(t) = W7 → apcf(t) = W7, pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ alsf(t).t = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ ( pcf(t) = W2
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (SF ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W1;W2))
∧ (pcf(t) = W3 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W4;W5)
))
∧ ( pcf(t) = W6
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W4;(SF ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W5;W6))
))
∧ (pcf(t) = W7 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 36:
gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem, lsf(t).t = alsf(t).t,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, tid0 = alsf(t).t, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W6 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;(SF ∈ gs.bq(alsf(t).t) ⊃ W5;W6))),
pcf(t) = W5 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;W5)),
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;W4), pcf(t) = W3 → apcf(t) = W3,
pcf(t) = W2 → apcf(t) = (SF ∈ gs.bq(alsf(t).t) ⊃ W1;W2), pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ alsf(t).t = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ ( pcf(t) = W2
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (SF ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W1;W2))
∧ (pcf(t) = W3 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W4;W5)
))
∧ ( pcf(t) = W6
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W4;(SF ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W5;W6))
))
∧ (pcf(t) = W7 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
fma: tid0 = alsf(t).t
Additional information
Used formulas: tid0 = alsf(t).t
Proof step 36 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(alsf(tid0).l, alsf(tid0).v) ' + bel, ags.ctr = gs.fctr, bq(tid0).head.l = alsf(tid0).l, ags.mem = gs.pmem, lsf(t).t = alsf(t).t,
bq(tid0).head.v = alsf(tid0).v, ags.writers = gs.fwriters, apcf(tid0) = W3, tid0 = alsf(tid0).t, tid0 = alsf(t).t, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(alsf(tid0).l := gs.pq(alsf(tid0).l) + W(alsf(tid0).v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(tid0).l, alsf(tid0).v) ∈ gs.bq(tid0),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W6 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;(SF ∈ gs.bq(alsf(t).t) ⊃ W5;W6))),
pcf(t) = W5 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;W5)),
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;W4), pcf(t) = W3 → apcf(t) = W3,
pcf(t) = W2 → apcf(t) = (SF ∈ gs.bq(alsf(t).t) ⊃ W1;W2), pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ alsf(t).t = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ ( pcf(t) = W2
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (SF ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W1;W2))
∧ (pcf(t) = W3 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W4;W5)
))
∧ ( pcf(t) = W6
→ (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t))
⊃ W3
;(FO(lsf(t).loc) ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W4;(SF ∈ (tid0 = alsf(t).t ⊃ bel;gs.bq(alsf(t).t)) ⊃ W5;W6))
))
∧ (pcf(t) = W7 → (tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 37:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3,
gs.bq(alsf(t).t) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∈ gs.bq(alsf(t).t), pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W2 → apcf(t) = (SF ∈ gs.bq(alsf(t).t) ⊃ W1;W2),
pcf(t) = W3 → apcf(t) = W3, pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;W4),
pcf(t) = W5 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;W5)),
pcf(t) = W6 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;(SF ∈ gs.bq(alsf(t).t) ⊃ W5;W6))),
pcf(t) = W7 → apcf(t) = W7, pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
Additional information
Used simplifier rules:
a: ⊦ (x + y) + z = x + y + z; from specification list
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
Proof step 37 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3,
gs.bq(alsf(t).t) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∈ gs.bq(alsf(t).t), pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W2 → apcf(t) = (SF ∈ gs.bq(alsf(t).t) ⊃ W1;W2),
pcf(t) = W3 → apcf(t) = W3, pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;W4),
pcf(t) = W5 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;W5)),
pcf(t) = W6 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;(SF ∈ gs.bq(alsf(t).t) ⊃ W5;W6))),
pcf(t) = W7 → apcf(t) = W7, pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 38:
⊦ FLITInv(gs, lsf, pcf) ↔ FLITGInv(gs) ∧ (∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)))
- Proof step 39:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3,
gs.bq(alsf(t).t) ≠ [], FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∈ gs.bq(alsf(t).t),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W6 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;(SF ∈ gs.bq(alsf(t).t) ⊃ W5;W6))),
pcf(t) = W5 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;W5)),
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;W4), pcf(t) = W3 → apcf(t) = W3,
pcf(t) = W2 → apcf(t) = (SF ∈ gs.bq(alsf(t).t) ⊃ W1;W2), pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
spec: FLIT, name:FLITInv,
seq:⊦ FLITInv(gs, lsf, pcf)
↔ FLITGInv(gs) ∧ (∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))),
subst:[gs, lsf, pcf] → [gs, lsf, pcf], <all paths>
Additional information
Used terms: gs, lsf, pcf
Proof step 38 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⊦ FLITInv(gs, lsf, pcf) ↔ FLITGInv(gs) ∧ (∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))) |
A spec-lemma
Proof step 39 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3,
gs.bq(alsf(t).t) ≠ [], FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∈ gs.bq(alsf(t).t),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W6 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;(SF ∈ gs.bq(alsf(t).t) ⊃ W5;W6))),
pcf(t) = W5 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;W5)),
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;W4), pcf(t) = W3 → apcf(t) = W3,
pcf(t) = W2 → apcf(t) = (SF ∈ gs.bq(alsf(t).t) ⊃ W1;W2), pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
User applied rule all left
And obtained the following new goals
- Proof step 40:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, gs.bq(alsf(t).t) ≠ [], FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
FLITLInv(gs, lsf(alsf(t).t), pcf(alsf(t).t)), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∈ gs.bq(alsf(t).t), pcf(t) = idle → apcf(t) = idle, pcf(t) = ready → apcf(t) = ready,
pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2, pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = W1 → apcf(t) = W1, pcf(t) = W2 → apcf(t) = (SF ∈ gs.bq(alsf(t).t) ⊃ W1;W2), pcf(t) = W3 → apcf(t) = W3,
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;W4),
pcf(t) = W5 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;W5)),
pcf(t) = W6 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;(SF ∈ gs.bq(alsf(t).t) ⊃ W5;W6))),
pcf(t) = W7 → apcf(t) = W7, pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
pos: left 35 terms: alsf(t).t abort: F discard: F computed: T
Additional information
Used terms: alsf(t).t
Proof step 40 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, gs.bq(alsf(t).t) ≠ [], FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
FLITLInv(gs, lsf(alsf(t).t), pcf(alsf(t).t)), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo),
W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∈ gs.bq(alsf(t).t), pcf(t) = idle → apcf(t) = idle, pcf(t) = ready → apcf(t) = ready,
pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2, pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = W1 → apcf(t) = W1, pcf(t) = W2 → apcf(t) = (SF ∈ gs.bq(alsf(t).t) ⊃ W1;W2), pcf(t) = W3 → apcf(t) = W3,
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;W4),
pcf(t) = W5 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;W5)),
pcf(t) = W6 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;(SF ∈ gs.bq(alsf(t).t) ⊃ W5;W6))),
pcf(t) = W7 → apcf(t) = W7, pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 41:
⊦ FLITLInv(gs, ls, pc)
↔ (pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7 → notMember(ls.t, gs.freaders))
∧ (pc = W1 ∨ pc = W2 ∨ pc = W7 → notMember(ls.t, gs.fwriters)) ∧ (pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 → oneMember(ls.t, ls.loc, gs.fwriters))
∧ (pc = W1 ∨ pc = W2 → noPendingW(ls.t, gs.bq, gs.pq)) ∧ (pc = W3 ∨ pc = W7 → noPending(ls.t, gs.bq, gs.pq))
∧ (pc = W5 ∨ pc = W6 → FOFollowsW(ls.t, gs.bq(ls.t), gs.pq(ls.loc), ls.loc))
∧ (pc = W1 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W7 → ¬ SF ∈ gs.bq(ls.t)) ∧ (pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7 → gs.rfo(ls.t) = [])
∧ (pc = W3 → gs.bq(ls.t) = []) ∧ (pc = W4 → gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = W(ls.loc, ls.val) ')
∧ (pc = W5 → gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = FO(ls.loc) ' ∨ gs.bq(ls.t) = W(ls.loc, ls.val) ' + FO(ls.loc) ')
∧ (pc = W6 → gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = SF ' ∨ gs.bq(ls.t) = FO(ls.loc) ' + SF ' ∨ gs.bq(ls.t) = W(ls.loc, ls.val) ' + FO(ls.loc) ' + SF ')
∧ (pc = W4 ∨ pc = W5 ∨ pc = W6 → gs.bq(ls.t) ≠ [] ∧ gs.bq(ls.t).head.W? → gs.bq(ls.t).head = W(ls.loc, ls.val))
∧ (pc = W1 ∨ pc = W7 → gs.rfo(ls.t) = gs.bq(ls.t)) ∧ (pc = W2 → gs.rfo(ls.t) = gs.bq(ls.t) ∨ gs.rfo(ls.t) + SF ' = gs.bq(ls.t))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → noPendingW(ls.t, gs.bq, gs.pq))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → notMember(ls.t, gs.fwriters)) ∧ (pc = R1 ∨ pc = R4 → notMember(ls.t, gs.freaders))
∧ (pc = R2 ∨ pc = R3 → oneMember(ls.t, ls.loc, gs.freaders)) ∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → ¬ SF ∈ gs.bq(ls.t))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → gs.rfo(ls.t) = gs.bq(ls.t)) ∧ (pc = idle ∨ pc = ready ∨ pc = crashed → notMember(ls.t, gs.fwriters))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → notMember(ls.t, gs.freaders))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → noPendingW(ls.t, gs.bq, gs.pq)) ∧ (pc = idle ∨ pc = crashed → noPending(ls.t, gs.bq, gs.pq))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → ¬ SF ∈ gs.bq(ls.t)) ∧ (pc = idle ∨ pc = ready ∨ pc = crashed → gs.rfo(ls.t) = gs.bq(ls.t))
- Proof step 42:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, gs.bq(alsf(t).t) ≠ [], FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∈ gs.bq(alsf(t).t),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W6 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;(SF ∈ gs.bq(alsf(t).t) ⊃ W5;W6))),
pcf(t) = W5 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;W5)),
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;W4), pcf(t) = W3 → apcf(t) = W3,
pcf(t) = W2 → apcf(t) = (SF ∈ gs.bq(alsf(t).t) ⊃ W1;W2), pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle,
pcf(alsf(t).t) = W1 ∨ pcf(alsf(t).t) = W2 ∨ pcf(alsf(t).t) = W3 ∨ pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6
∨ pcf(alsf(t).t) = W7
→ notMember(lsf(alsf(t).t).t, gs.freaders),
pcf(alsf(t).t) = W1 ∨ pcf(alsf(t).t) = W2 ∨ pcf(alsf(t).t) = W7 → notMember(lsf(alsf(t).t).t, gs.fwriters),
pcf(alsf(t).t) = W3 ∨ pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(lsf(alsf(t).t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W1 ∨ pcf(alsf(t).t) = W2 → noPendingW(lsf(alsf(t).t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W3 ∨ pcf(alsf(t).t) = W7 → noPending(lsf(alsf(t).t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(lsf(alsf(t).t).t, gs.bq(lsf(alsf(t).t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W1 ∨ pcf(alsf(t).t) = W3 ∨ pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W7 → ¬ SF ∈ gs.bq(lsf(alsf(t).t).t),
pcf(alsf(t).t) = W3 ∨ pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 ∨ pcf(alsf(t).t) = W7 → gs.rfo(lsf(alsf(t).t).t) = [],
pcf(alsf(t).t) = W3 → gs.bq(lsf(alsf(t).t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(lsf(alsf(t).t).t) = [] ∨ gs.bq(lsf(alsf(t).t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(lsf(alsf(t).t).t) = [] ∨ gs.bq(lsf(alsf(t).t).t) = FO(lsf(alsf(t).t).loc) '
∨ gs.bq(lsf(alsf(t).t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(lsf(alsf(t).t).t) = [] ∨ gs.bq(lsf(alsf(t).t).t) = SF ' ∨ gs.bq(lsf(alsf(t).t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(lsf(alsf(t).t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.bq(lsf(alsf(t).t).t) ≠ [] ∧ gs.bq(lsf(alsf(t).t).t).head.W?
→ gs.bq(lsf(alsf(t).t).t).head = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W1 ∨ pcf(alsf(t).t) = W7 → gs.rfo(lsf(alsf(t).t).t) = gs.bq(lsf(alsf(t).t).t),
pcf(alsf(t).t) = W2 → gs.rfo(lsf(alsf(t).t).t) = gs.bq(lsf(alsf(t).t).t) ∨ gs.rfo(lsf(alsf(t).t).t) + SF ' = gs.bq(lsf(alsf(t).t).t),
pcf(alsf(t).t) = R1 ∨ pcf(alsf(t).t) = R2 ∨ pcf(alsf(t).t) = R3 ∨ pcf(alsf(t).t) = R4 → noPendingW(lsf(alsf(t).t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = R1 ∨ pcf(alsf(t).t) = R2 ∨ pcf(alsf(t).t) = R3 ∨ pcf(alsf(t).t) = R4 → notMember(lsf(alsf(t).t).t, gs.fwriters),
pcf(alsf(t).t) = R1 ∨ pcf(alsf(t).t) = R4 → notMember(lsf(alsf(t).t).t, gs.freaders),
pcf(alsf(t).t) = R2 ∨ pcf(alsf(t).t) = R3 → oneMember(lsf(alsf(t).t).t, lsf(alsf(t).t).loc, gs.freaders),
pcf(alsf(t).t) = R1 ∨ pcf(alsf(t).t) = R2 ∨ pcf(alsf(t).t) = R3 ∨ pcf(alsf(t).t) = R4 → ¬ SF ∈ gs.bq(lsf(alsf(t).t).t),
pcf(alsf(t).t) = R1 ∨ pcf(alsf(t).t) = R2 ∨ pcf(alsf(t).t) = R3 ∨ pcf(alsf(t).t) = R4 → gs.rfo(lsf(alsf(t).t).t) = gs.bq(lsf(alsf(t).t).t),
pcf(alsf(t).t) = idle ∨ pcf(alsf(t).t) = ready ∨ pcf(alsf(t).t) = crashed → notMember(lsf(alsf(t).t).t, gs.fwriters),
pcf(alsf(t).t) = idle ∨ pcf(alsf(t).t) = ready ∨ pcf(alsf(t).t) = crashed → notMember(lsf(alsf(t).t).t, gs.freaders),
pcf(alsf(t).t) = idle ∨ pcf(alsf(t).t) = ready ∨ pcf(alsf(t).t) = crashed → noPendingW(lsf(alsf(t).t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = idle ∨ pcf(alsf(t).t) = crashed → noPending(lsf(alsf(t).t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = idle ∨ pcf(alsf(t).t) = ready ∨ pcf(alsf(t).t) = crashed → ¬ SF ∈ gs.bq(lsf(alsf(t).t).t),
pcf(alsf(t).t) = idle ∨ pcf(alsf(t).t) = ready ∨ pcf(alsf(t).t) = crashed → gs.rfo(lsf(alsf(t).t).t) = gs.bq(lsf(alsf(t).t).t),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
spec: FLIT, name:FLITLInv,
seq:⊦ FLITLInv(gs, ls, pc)
↔ ( pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7
→ notMember(ls.t, gs.freaders))
∧ (pc = W1 ∨ pc = W2 ∨ pc = W7 → notMember(ls.t, gs.fwriters))
∧ (pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 → oneMember(ls.t, ls.loc, gs.fwriters))
∧ (pc = W1 ∨ pc = W2 → noPendingW(ls.t, gs.bq, gs.pq))
∧ (pc = W3 ∨ pc = W7 → noPending(ls.t, gs.bq, gs.pq))
∧ (pc = W5 ∨ pc = W6 → FOFollowsW(ls.t, gs.bq(ls.t), gs.pq(ls.loc), ls.loc))
∧ (pc = W1 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W7 → ¬ SF ∈ gs.bq(ls.t))
∧ (pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7 → gs.rfo(ls.t) = [])
∧ (pc = W3 → gs.bq(ls.t) = [])
∧ (pc = W4 → gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = W(ls.loc, ls.val) ')
∧ ( pc = W5
→ gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = FO(ls.loc) '
∨ gs.bq(ls.t) = W(ls.loc, ls.val) ' + FO(ls.loc) ')
∧ ( pc = W6
→ gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = SF ' ∨ gs.bq(ls.t) = FO(ls.loc) ' + SF '
∨ gs.bq(ls.t) = W(ls.loc, ls.val) ' + FO(ls.loc) ' + SF ')
∧ ( pc = W4 ∨ pc = W5 ∨ pc = W6 → gs.bq(ls.t) ≠ [] ∧ gs.bq(ls.t).head.W?
→ gs.bq(ls.t).head = W(ls.loc, ls.val))
∧ (pc = W1 ∨ pc = W7 → gs.rfo(ls.t) = gs.bq(ls.t))
∧ (pc = W2 → gs.rfo(ls.t) = gs.bq(ls.t) ∨ gs.rfo(ls.t) + SF ' = gs.bq(ls.t))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → noPendingW(ls.t, gs.bq, gs.pq))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → notMember(ls.t, gs.fwriters))
∧ (pc = R1 ∨ pc = R4 → notMember(ls.t, gs.freaders))
∧ (pc = R2 ∨ pc = R3 → oneMember(ls.t, ls.loc, gs.freaders))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → ¬ SF ∈ gs.bq(ls.t))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → gs.rfo(ls.t) = gs.bq(ls.t))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → notMember(ls.t, gs.fwriters))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → notMember(ls.t, gs.freaders))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → noPendingW(ls.t, gs.bq, gs.pq))
∧ (pc = idle ∨ pc = crashed → noPending(ls.t, gs.bq, gs.pq))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → ¬ SF ∈ gs.bq(ls.t))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → gs.rfo(ls.t) = gs.bq(ls.t)),
subst:[gs, ls, pc] → [gs, lsf(alsf(t).t), pcf(alsf(t).t)], <all paths>
Additional information
Used terms: gs, lsf(alsf(t).t), pcf(alsf(t).t)
Proof step 41 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⊦ FLITLInv(gs, ls, pc)
↔ (pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7 → notMember(ls.t, gs.freaders))
∧ (pc = W1 ∨ pc = W2 ∨ pc = W7 → notMember(ls.t, gs.fwriters)) ∧ (pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 → oneMember(ls.t, ls.loc, gs.fwriters))
∧ (pc = W1 ∨ pc = W2 → noPendingW(ls.t, gs.bq, gs.pq)) ∧ (pc = W3 ∨ pc = W7 → noPending(ls.t, gs.bq, gs.pq))
∧ (pc = W5 ∨ pc = W6 → FOFollowsW(ls.t, gs.bq(ls.t), gs.pq(ls.loc), ls.loc))
∧ (pc = W1 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W7 → ¬ SF ∈ gs.bq(ls.t)) ∧ (pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7 → gs.rfo(ls.t) = [])
∧ (pc = W3 → gs.bq(ls.t) = []) ∧ (pc = W4 → gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = W(ls.loc, ls.val) ')
∧ (pc = W5 → gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = FO(ls.loc) ' ∨ gs.bq(ls.t) = W(ls.loc, ls.val) ' + FO(ls.loc) ')
∧ (pc = W6 → gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = SF ' ∨ gs.bq(ls.t) = FO(ls.loc) ' + SF ' ∨ gs.bq(ls.t) = W(ls.loc, ls.val) ' + FO(ls.loc) ' + SF ')
∧ (pc = W4 ∨ pc = W5 ∨ pc = W6 → gs.bq(ls.t) ≠ [] ∧ gs.bq(ls.t).head.W? → gs.bq(ls.t).head = W(ls.loc, ls.val))
∧ (pc = W1 ∨ pc = W7 → gs.rfo(ls.t) = gs.bq(ls.t)) ∧ (pc = W2 → gs.rfo(ls.t) = gs.bq(ls.t) ∨ gs.rfo(ls.t) + SF ' = gs.bq(ls.t))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → noPendingW(ls.t, gs.bq, gs.pq))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → notMember(ls.t, gs.fwriters)) ∧ (pc = R1 ∨ pc = R4 → notMember(ls.t, gs.freaders))
∧ (pc = R2 ∨ pc = R3 → oneMember(ls.t, ls.loc, gs.freaders)) ∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → ¬ SF ∈ gs.bq(ls.t))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → gs.rfo(ls.t) = gs.bq(ls.t)) ∧ (pc = idle ∨ pc = ready ∨ pc = crashed → notMember(ls.t, gs.fwriters))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → notMember(ls.t, gs.freaders))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → noPendingW(ls.t, gs.bq, gs.pq)) ∧ (pc = idle ∨ pc = crashed → noPending(ls.t, gs.bq, gs.pq))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → ¬ SF ∈ gs.bq(ls.t)) ∧ (pc = idle ∨ pc = ready ∨ pc = crashed → gs.rfo(ls.t) = gs.bq(ls.t)) |
A spec-lemma
Proof step 42 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, gs.bq(alsf(t).t) ≠ [], FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∈ gs.bq(alsf(t).t),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W6 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;(SF ∈ gs.bq(alsf(t).t) ⊃ W5;W6))),
pcf(t) = W5 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;W5)),
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;W4), pcf(t) = W3 → apcf(t) = W3,
pcf(t) = W2 → apcf(t) = (SF ∈ gs.bq(alsf(t).t) ⊃ W1;W2), pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle,
pcf(alsf(t).t) = W1 ∨ pcf(alsf(t).t) = W2 ∨ pcf(alsf(t).t) = W3 ∨ pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6
∨ pcf(alsf(t).t) = W7
→ notMember(lsf(alsf(t).t).t, gs.freaders),
pcf(alsf(t).t) = W1 ∨ pcf(alsf(t).t) = W2 ∨ pcf(alsf(t).t) = W7 → notMember(lsf(alsf(t).t).t, gs.fwriters),
pcf(alsf(t).t) = W3 ∨ pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(lsf(alsf(t).t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W1 ∨ pcf(alsf(t).t) = W2 → noPendingW(lsf(alsf(t).t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W3 ∨ pcf(alsf(t).t) = W7 → noPending(lsf(alsf(t).t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(lsf(alsf(t).t).t, gs.bq(lsf(alsf(t).t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W1 ∨ pcf(alsf(t).t) = W3 ∨ pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W7 → ¬ SF ∈ gs.bq(lsf(alsf(t).t).t),
pcf(alsf(t).t) = W3 ∨ pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 ∨ pcf(alsf(t).t) = W7 → gs.rfo(lsf(alsf(t).t).t) = [],
pcf(alsf(t).t) = W3 → gs.bq(lsf(alsf(t).t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(lsf(alsf(t).t).t) = [] ∨ gs.bq(lsf(alsf(t).t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(lsf(alsf(t).t).t) = [] ∨ gs.bq(lsf(alsf(t).t).t) = FO(lsf(alsf(t).t).loc) '
∨ gs.bq(lsf(alsf(t).t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(lsf(alsf(t).t).t) = [] ∨ gs.bq(lsf(alsf(t).t).t) = SF ' ∨ gs.bq(lsf(alsf(t).t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(lsf(alsf(t).t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.bq(lsf(alsf(t).t).t) ≠ [] ∧ gs.bq(lsf(alsf(t).t).t).head.W?
→ gs.bq(lsf(alsf(t).t).t).head = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W1 ∨ pcf(alsf(t).t) = W7 → gs.rfo(lsf(alsf(t).t).t) = gs.bq(lsf(alsf(t).t).t),
pcf(alsf(t).t) = W2 → gs.rfo(lsf(alsf(t).t).t) = gs.bq(lsf(alsf(t).t).t) ∨ gs.rfo(lsf(alsf(t).t).t) + SF ' = gs.bq(lsf(alsf(t).t).t),
pcf(alsf(t).t) = R1 ∨ pcf(alsf(t).t) = R2 ∨ pcf(alsf(t).t) = R3 ∨ pcf(alsf(t).t) = R4 → noPendingW(lsf(alsf(t).t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = R1 ∨ pcf(alsf(t).t) = R2 ∨ pcf(alsf(t).t) = R3 ∨ pcf(alsf(t).t) = R4 → notMember(lsf(alsf(t).t).t, gs.fwriters),
pcf(alsf(t).t) = R1 ∨ pcf(alsf(t).t) = R4 → notMember(lsf(alsf(t).t).t, gs.freaders),
pcf(alsf(t).t) = R2 ∨ pcf(alsf(t).t) = R3 → oneMember(lsf(alsf(t).t).t, lsf(alsf(t).t).loc, gs.freaders),
pcf(alsf(t).t) = R1 ∨ pcf(alsf(t).t) = R2 ∨ pcf(alsf(t).t) = R3 ∨ pcf(alsf(t).t) = R4 → ¬ SF ∈ gs.bq(lsf(alsf(t).t).t),
pcf(alsf(t).t) = R1 ∨ pcf(alsf(t).t) = R2 ∨ pcf(alsf(t).t) = R3 ∨ pcf(alsf(t).t) = R4 → gs.rfo(lsf(alsf(t).t).t) = gs.bq(lsf(alsf(t).t).t),
pcf(alsf(t).t) = idle ∨ pcf(alsf(t).t) = ready ∨ pcf(alsf(t).t) = crashed → notMember(lsf(alsf(t).t).t, gs.fwriters),
pcf(alsf(t).t) = idle ∨ pcf(alsf(t).t) = ready ∨ pcf(alsf(t).t) = crashed → notMember(lsf(alsf(t).t).t, gs.freaders),
pcf(alsf(t).t) = idle ∨ pcf(alsf(t).t) = ready ∨ pcf(alsf(t).t) = crashed → noPendingW(lsf(alsf(t).t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = idle ∨ pcf(alsf(t).t) = crashed → noPending(lsf(alsf(t).t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = idle ∨ pcf(alsf(t).t) = ready ∨ pcf(alsf(t).t) = crashed → ¬ SF ∈ gs.bq(lsf(alsf(t).t).t),
pcf(alsf(t).t) = idle ∨ pcf(alsf(t).t) = ready ∨ pcf(alsf(t).t) = crashed → gs.rfo(lsf(alsf(t).t).t) = gs.bq(lsf(alsf(t).t).t),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 43:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, gs.bq(alsf(t).t) ≠ [], pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W6 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;(SF ∈ gs.bq(alsf(t).t) ⊃ W5;W6))),
pcf(t) = W5 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;W5)),
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;W4), pcf(t) = W3 → apcf(t) = W3,
pcf(t) = W2 → apcf(t) = (SF ∈ gs.bq(alsf(t).t) ⊃ W1;W2), pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ gs.bq(alsf(t).t),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.bq(alsf(t).t).head.W?
→ gs.bq(alsf(t).t).head = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
Additional information
Used simplifier rules:
a: ⊦ (x + y) + z = x + y + z; from specification list
⊦ noPending(t, bq, pq) → bq(t) ≠ W(l, v) ' + bel; (as)
⊦ noPendingW(t, bq, pq) → bq(t) ≠ W(l, v) ' + bel; (as)
Proof step 43 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, gs.bq(alsf(t).t) ≠ [], pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W6 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;(SF ∈ gs.bq(alsf(t).t) ⊃ W5;W6))),
pcf(t) = W5 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;W5)),
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;W4), pcf(t) = W3 → apcf(t) = W3,
pcf(t) = W2 → apcf(t) = (SF ∈ gs.bq(alsf(t).t) ⊃ W1;W2), pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ gs.bq(alsf(t).t),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.bq(alsf(t).t).head.W?
→ gs.bq(alsf(t).t).head = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic elimination applied rule apply elim lemma
And obtained the following new goals
- Proof step 44:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, gs.bq(alsf(t).t) = head + bel0, ags.ctr = gs.fctr,
bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, gs.bq(alsf(t).t) ≠ [], pcf(alsf(t).t) ≠ W1,
pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4,
pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → head.W? → head = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ gs.bq(alsf(t).t), pcf(t) = idle → apcf(t) = idle, pcf(t) = ready → apcf(t) = ready,
pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2, pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = W1 → apcf(t) = W1, pcf(t) = W2 → apcf(t) = (SF ∈ gs.bq(alsf(t).t) ⊃ W1;W2), pcf(t) = W3 → apcf(t) = W3,
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;W4),
pcf(t) = W5 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;W5)),
pcf(t) = W6 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;(SF ∈ gs.bq(alsf(t).t) ⊃ W5;W6))),
pcf(t) = W7 → apcf(t) = W7, pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
spec: list-data, name:elim-add,
seq: ⊦ x ≠ [] → (head = x.head ∧ tail = x.tail ↔ x = head + tail),
subst:[x, head, tail] → [gs.bq(alsf(t).t), head, bel0]; ['a] → [Bevent]
Additional information
Used simplifier rules:
⊦ x ≠ [] → (head = x.head ∧ tail = x.tail ↔ x = head + tail); (elim)
Used terms: gs.bq(alsf(t).t), head, bel0
Proof step 44 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, gs.bq(alsf(t).t) = head + bel0, ags.ctr = gs.fctr,
bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, gs.bq(alsf(t).t) ≠ [], pcf(alsf(t).t) ≠ W1,
pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4,
pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → head.W? → head = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ gs.bq(alsf(t).t), pcf(t) = idle → apcf(t) = idle, pcf(t) = ready → apcf(t) = ready,
pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2, pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = W1 → apcf(t) = W1, pcf(t) = W2 → apcf(t) = (SF ∈ gs.bq(alsf(t).t) ⊃ W1;W2), pcf(t) = W3 → apcf(t) = W3,
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;W4),
pcf(t) = W5 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;W5)),
pcf(t) = W6 → apcf(t) = (W(lsf(t).loc, lsf(t).val) ∈ gs.bq(alsf(t).t) ⊃ W3;(FO(lsf(t).loc) ∈ gs.bq(alsf(t).t) ⊃ W4;(SF ∈ gs.bq(alsf(t).t) ⊃ W5;W6))),
pcf(t) = W7 → apcf(t) = W7, pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 45:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W3 → apcf(t) = W3, pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
Additional information
Used simplifier rules:
⊦ W(l, v).W?; (s)
⊦ W(l, v) ≠ SF; (s)
⊦ W(l, v) ≠ FO(l0); (s)
a: ⊦ (x + y) + z = x + y + z; from specification list
⊦ a ∈ a0 ' + x ↔ a = a0 ∨ a ∈ x; (s)
⊦ a ' ≠ []; (s)
⊦ x + y = [] ↔ x = [] ∧ y = []; (s)
⊦ a ' + x = a0 ' + y ↔ a = a0 ∧ x = y; (ws)
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
⊦ a + x = a ' + x; (s)
Proof step 45 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W3 → apcf(t) = W3, pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 46:
⊦ FLITPSCInv(gs, lsf, pcf) ↔ FLITPSCGInv(gs) ∧ (∀ t. lsf(t).t = t ∧ FLITPSCLInv(gs, lsf(t), pcf(t)))
- Proof step 47:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
FLITPSCGInv(ags), reorder(ags.p, gs.pq, gs.rfo), ¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
spec: FLITPSCweak, name:FLITPSCInv,
seq:⊦ FLITPSCInv(gs, lsf, pcf)
↔ FLITPSCGInv(gs) ∧ (∀ t. lsf(t).t = t ∧ FLITPSCLInv(gs, lsf(t), pcf(t))),
subst:[gs, lsf, pcf] → [ags, alsf, apcf], <all paths>
Additional information
Used terms: ags, alsf, apcf
Proof step 46 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⊦ FLITPSCInv(gs, lsf, pcf) ↔ FLITPSCGInv(gs) ∧ (∀ t. lsf(t).t = t ∧ FLITPSCLInv(gs, lsf(t), pcf(t))) |
A spec-lemma
Proof step 47 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
FLITPSCGInv(ags), reorder(ags.p, gs.pq, gs.rfo), ¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 48:
⊦ FLITPSCGInv(gs) ↔ ctrok(gs.ctr, gs.writers) ∧ writersOk(gs.p, gs.writers) ∧ pendingOk(gs.p)
- Proof step 49:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
ctrok(ags.ctr, ags.writers), pendingOk(ags.p), reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, ags.writers), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W3 → apcf(t) = W3, pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
spec: FLITPSCweak, name:FLITPSCGInv,
seq:⊦ FLITPSCGInv(gs)
↔ ctrok(gs.ctr, gs.writers) ∧ writersOk(gs.p, gs.writers) ∧ pendingOk(gs.p),
subst:[gs] → [ags], <all paths>
Additional information
Used terms: ags
Proof step 48 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⊦ FLITPSCGInv(gs) ↔ ctrok(gs.ctr, gs.writers) ∧ writersOk(gs.p, gs.writers) ∧ pendingOk(gs.p) |
A spec-lemma
Proof step 49 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
ctrok(ags.ctr, ags.writers), pendingOk(ags.p), reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, ags.writers), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W3 → apcf(t) = W3, pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 50:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
Additional information
Proof step 50 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 51:
⊦ FLITGInv(gs)
↔ ctrok(gs.fctr, gs.fwriters) ∧ writersOk(gs.bq, gs.pq, gs.fwriters) ∧ pendingOk(gs.bq, gs.pq) ∧ SFTrailing(gs.bq) ∧ readFOsOk(gs.rfo, gs.fwriters)
- Proof step 52:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W3 → apcf(t) = W3, pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
spec: FLIT, name:FLITGInv,
seq:⊦ FLITGInv(gs)
↔ ctrok(gs.fctr, gs.fwriters) ∧ writersOk(gs.bq, gs.pq, gs.fwriters)
∧ pendingOk(gs.bq, gs.pq) ∧ SFTrailing(gs.bq) ∧ readFOsOk(gs.rfo, gs.fwriters),
subst:[gs] → [gs], <all paths>
Additional information
Used terms: gs
Proof step 51 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⊦ FLITGInv(gs)
↔ ctrok(gs.fctr, gs.fwriters) ∧ writersOk(gs.bq, gs.pq, gs.fwriters) ∧ pendingOk(gs.bq, gs.pq) ∧ SFTrailing(gs.bq) ∧ readFOsOk(gs.rfo, gs.fwriters) |
A spec-lemma
Proof step 52 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(t) = W4 → apcf(t) = (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W3 → apcf(t) = W3, pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic if-then-else split applied rule case distinction
And obtained the following new goals
- Proof step 53:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
- Proof step 89:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, apcf(t) = (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4),
pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3,
pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
pos: left 33
Additional information
Proof step 53 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 54:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W7 → apcf(t) = W7, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W1 → apcf(t) = W1,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3, pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed,
pcf(t) = ready → apcf(t) = ready, pcf(t) = idle → apcf(t) = idle,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
Additional information
Proof step 54 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W7 → apcf(t) = W7, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W1 → apcf(t) = W1,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3, pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed,
pcf(t) = ready → apcf(t) = ready, pcf(t) = idle → apcf(t) = idle,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic if-then-else split applied rule case distinction
And obtained the following new goals
- Proof step 55:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(t) ≠ W6, pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
- Proof step 67:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3,
apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
pos: left 53
Additional information
Proof step 55 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(t) ≠ W6, pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 56:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(t) ≠ W6, pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W7 → apcf(t) = W7, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W1 → apcf(t) = W1,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3, pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed,
pcf(t) = ready → apcf(t) = ready, pcf(t) = idle → apcf(t) = idle,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
Additional information
Proof step 56 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, pcf(t) ≠ W6, pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W7 → apcf(t) = W7, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W1 → apcf(t) = W1,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3, pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed,
pcf(t) = ready → apcf(t) = ready, pcf(t) = idle → apcf(t) = idle,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 57:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, alsf(t).t = t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v,
ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, pcf(t) ≠ W6, pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
- Proof step 61:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, alsf(t).t ≠ t, pcf(t) ≠ W6, pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
fma: alsf(t).t = t
Additional information
Used formulas: alsf(t).t = t
Proof step 57 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, alsf(t).t = t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v,
ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, pcf(t) ≠ W6, pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 58:
gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, gs.rfo(t) = [],
alsf(t).t = t, lsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, pcf(t) = W5,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, gs.bq(t), gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(t), ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ SF ∈ bel, ¬ FO(alsf(t).l) ∈ bel, ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
gs.bq(t) = FO(alsf(t).l) ' ∨ gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + FO(alsf(t).l) '
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ pendingOk(bq, pq) ∧ bq(t) = W(l, v) ' + bel0 → ¬ W(l, v0) ∈ bel0; (as)
⊦ W5 ≠ crashed; (s)
⊦ W5 ≠ ready; (s)
⊦ W5 ≠ idle; (s)
⊦ R4 ≠ W5; (s)
⊦ R3 ≠ W5; (s)
⊦ R2 ≠ W5; (s)
⊦ R1 ≠ W5; (s)
⊦ W5 ≠ W7; (s)
⊦ W3 ≠ W5; (s)
⊦ W2 ≠ W5; (s)
⊦ W1 ≠ W5; (s)
⊦ W4 ≠ W5; (s)
⊦ W5 ≠ W6; (s)
⊦ W(l, v) = W(l0, v0) ↔ l = l0 ∧ v = v0; (ws)
⊦ lstepf(gs, ls, W3, a) = ls; (s)
⊦ W4 ≠ W5; (s)
⊦ W3 ≠ W4; (s)
⊦ pcstepf(gs, ls, W3, a) = W4; (s)
⊦ W3 ≠ W5; (s)
a: ⊦ (x + y) + z = x + y + z; from specification list
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
Proof step 58 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, gs.rfo(t) = [],
alsf(t).t = t, lsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, pcf(t) = W5,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, gs.bq(t), gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(t), ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ SF ∈ bel, ¬ FO(alsf(t).l) ∈ bel, ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
gs.bq(t) = FO(alsf(t).l) ' ∨ gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + FO(alsf(t).l) '
⊦ |
User applied rule case distinction
And obtained the following new goals
- Proof step 59:
gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + bel, gs.bq(t) = FO(alsf(t).l) ', ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l,
ags.mem = gs.pmem, gs.rfo(t) = [], lsf(t).t = t, alsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters,
apcf(t) = W3, pcf(t) = W5, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, gs.bq(t), gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(t), ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ SF ∈ bel, ¬ FO(alsf(t).l) ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 34
Additional information
Used simplifier rules:
eq-05: ⊦ x = a ' + y ∧ x = a0 ' + z → a = a0 ∧ y = z; (forward) from specification list
in-15: ⊦ x + a ' = y → a ∈ y; (forward) from specification list
a: ⊦ (x + y) + z = x + y + z; from specification list
⊦ a ∈ a0 ' ↔ a = a0; (s)
Proof step 59 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + bel, gs.bq(t) = FO(alsf(t).l) ', ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l,
ags.mem = gs.pmem, gs.rfo(t) = [], lsf(t).t = t, alsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters,
apcf(t) = W3, pcf(t) = W5, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, gs.bq(t), gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(t), ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ SF ∈ bel, ¬ FO(alsf(t).l) ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ |
User applied rule subst equation
And obtained the following new goals
- Proof step 60:
FO(alsf(t).l) ' = W(alsf(t).l, alsf(t).v) ' + bel, gs.bq(t) = FO(alsf(t).l) ', ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l,
ags.mem = gs.pmem, gs.rfo(t) = [], alsf(t).t = t, lsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters,
apcf(t) = W3, pcf(t) = W5, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, FO(alsf(t).l) ', gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ FO(alsf(t).l) ', ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ SF ∈ bel, ¬ FO(alsf(t).l) ∈ bel, ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦
Rule argument
pos: left 2, flags:
Additional information
Proof step 60 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| FO(alsf(t).l) ' = W(alsf(t).l, alsf(t).v) ' + bel, gs.bq(t) = FO(alsf(t).l) ', ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l,
ags.mem = gs.pmem, gs.rfo(t) = [], alsf(t).t = t, lsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters,
apcf(t) = W3, pcf(t) = W5, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, FO(alsf(t).l) ', gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ FO(alsf(t).l) ', ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ SF ∈ bel, ¬ FO(alsf(t).l) ∈ bel, ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And closed the goal!
Rule argument
Additional information
Used simplifier rules:
a: ⊦ (x + y) + z = x + y + z; from specification list
⊦ W(l, v) ≠ FO(l0); (s)
⊦ a ' = a0 ' + x ↔ a = a0 ∧ x = []; (ws)
Proof step 61 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, alsf(t).t ≠ t, pcf(t) ≠ W6, pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 62:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters,
apcf(t) = (W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)),
apcf(alsf(t).t) = W3, pcf(t) = W5, alsf(t).t ≠ t, apcf(t) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)),
pcf(alsf(t).t) ≠ crashed, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ W5 ≠ W7; (s)
⊦ W3 ≠ W5; (s)
⊦ W1 ≠ W5; (s)
⊦ R4 ≠ W5; (s)
⊦ R3 ≠ W5; (s)
⊦ R2 ≠ W5; (s)
⊦ R1 ≠ W5; (s)
⊦ W5 ≠ crashed; (s)
⊦ W5 ≠ ready; (s)
⊦ W5 ≠ idle; (s)
⊦ W2 ≠ W5; (s)
⊦ W5 ≠ W6; (s)
⊦ W4 ≠ W5; (s)
Proof step 62 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters,
apcf(t) = (W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)),
apcf(alsf(t).t) = W3, pcf(t) = W5, alsf(t).t ≠ t, apcf(t) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)),
pcf(alsf(t).t) ≠ crashed, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 63:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3,
apcf(t) = (W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)),
pcf(t) = W5, alsf(t).t ≠ t, apcf(t) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)), pcf(alsf(t).t) ≠ crashed,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦
Rule argument
fma: W(alsf(t).l, alsf(t).v) ∈ bel
Additional information
Used formulas: W(alsf(t).l, alsf(t).v) ∈ bel
Proof step 63 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3,
apcf(t) = (W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)),
pcf(t) = W5, alsf(t).t ≠ t, apcf(t) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)), pcf(alsf(t).t) ≠ crashed,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 64:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3,
apcf(t) = (W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)), pcf(t) = W5, alsf(t).t ≠ t,
apcf(t) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;W5), pcf(alsf(t).t) ≠ crashed, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Proof step 64 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3,
apcf(t) = (W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)), pcf(t) = W5, alsf(t).t ≠ t,
apcf(t) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;W5), pcf(alsf(t).t) ≠ crashed, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 65:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters,
W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v),
apcf(t) = (W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)), apcf(alsf(t).t) = W3, pcf(t) = W5,
alsf(t).t ≠ t, apcf(t) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;W5), pcf(alsf(t).t) ≠ crashed, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦
Rule argument
fma: W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v)
Additional information
Used formulas: W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v)
Proof step 65 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters,
W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v),
apcf(t) = (W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)), apcf(alsf(t).t) = W3, pcf(t) = W5,
alsf(t).t ≠ t, apcf(t) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;W5), pcf(alsf(t).t) ≠ crashed, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 66:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W5, alsf(t).t ≠ t, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf), SFTrailing(gs.bq),
ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ W3 ≠ W5; (s)
⊦ W3 ≠ W4; (s)
a: ⊦ (x + y) + z = x + y + z; from specification list
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
⊦ W(l, v) = W(l0, v0) ↔ l = l0 ∧ v = v0; (ws)
Proof step 66 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W5, alsf(t).t ≠ t, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf), SFTrailing(gs.bq),
ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ |
Heuristic quantifier closing applied rule all left
And closed the goal!
Rule argument
pos: left 51 terms: t
Additional information
Used terms: t
Proof step 67 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3,
apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic if-then-else split applied rule case distinction
And obtained the following new goals
- Proof step 68:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W7 → apcf(t) = W7, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W1 → apcf(t) = W1,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3, pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed,
pcf(t) = ready → apcf(t) = ready, pcf(t) = idle → apcf(t) = idle,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
- Proof step 87:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, apcf(t) = (FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)), W(lsf(t).loc, lsf(t).val) ≠ W(alsf(alsf(t).t).l, alsf(alsf(t).t).v),
pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(lsf(t).loc, lsf(t).val) ∈ bel, pcf(t) = W7 → apcf(t) = W7, pcf(t) = W3 → apcf(t) = W3,
pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
pos: left 11
Additional information
Proof step 68 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W7 → apcf(t) = W7, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W1 → apcf(t) = W1,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3, pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed,
pcf(t) = ready → apcf(t) = ready, pcf(t) = idle → apcf(t) = idle,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 69:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(alsf(t).t) ≠ crashed, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1, pcf(t) ≠ W4, pcf(t) ≠ W7,
pcf(t) ≠ W1, pcf(t) ≠ R4, pcf(t) ≠ R3, pcf(t) ≠ R2, pcf(t) ≠ R1, pcf(t) ≠ crashed, pcf(t) ≠ ready, pcf(t) ≠ idle, pcf(t) ≠ W2,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v, pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l,
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦ (pcf(t) = W3 → alsf(t).t ≠ t) ∧ (pcf(t) = W5 → (alsf(t).t = t ⊃ W4;W3) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ (pcf(t) = W6 → (alsf(t).t = t ⊃ W4;W3) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
Rule argument
Additional information
Used simplifier rules:
⊦ lstepf(gs, ls, W3, a) = ls; (s)
⊦ pcstepf(gs, ls, W3, a) = W4; (s)
⊦ W3 ≠ W4; (s)
⊦ W2 ≠ W3; (s)
⊦ W1 ≠ W3; (s)
⊦ W3 ≠ idle; (s)
⊦ W3 ≠ ready; (s)
⊦ W3 ≠ crashed; (s)
⊦ R1 ≠ W3; (s)
⊦ R2 ≠ W3; (s)
⊦ R3 ≠ W3; (s)
⊦ R4 ≠ W3; (s)
⊦ W3 ≠ W7; (s)
Proof step 69 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(alsf(t).t) ≠ crashed, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1, pcf(t) ≠ W4, pcf(t) ≠ W7,
pcf(t) ≠ W1, pcf(t) ≠ R4, pcf(t) ≠ R3, pcf(t) ≠ R2, pcf(t) ≠ R1, pcf(t) ≠ crashed, pcf(t) ≠ ready, pcf(t) ≠ idle, pcf(t) ≠ W2,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v, pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l,
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦ (pcf(t) = W3 → alsf(t).t ≠ t) ∧ (pcf(t) = W5 → (alsf(t).t = t ⊃ W4;W3) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ (pcf(t) = W6 → (alsf(t).t = t ⊃ W4;W3) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)))) |
Heuristic if-then-else split applied rule case distinction
And obtained the following new goals
- Proof step 70:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W5, (alsf(t).t = t ⊃ W4;W3) ≠ (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(alsf(t).t) ≠ crashed, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1, pcf(t) ≠ W4, pcf(t) ≠ W7, pcf(t) ≠ W1,
pcf(t) ≠ R4, pcf(t) ≠ R3, pcf(t) ≠ R2, pcf(t) ≠ R1, pcf(t) ≠ crashed, pcf(t) ≠ ready, pcf(t) ≠ idle, pcf(t) ≠ W2,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l,
pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦
- Proof step 79:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W6,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))), pcf(alsf(t).t) ≠ crashed,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1, pcf(t) ≠ W4, pcf(t) ≠ W7, pcf(t) ≠ W1, pcf(t) ≠ R4, pcf(t) ≠ R3, pcf(t) ≠ R2,
pcf(t) ≠ R1, pcf(t) ≠ crashed, pcf(t) ≠ ready, pcf(t) ≠ idle, pcf(t) ≠ W2,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l,
pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦
Rule argument
pos: right 1
Additional information
Used simplifier rules:
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
a: ⊦ (x + y) + z = x + y + z; from specification list
Proof step 70 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W5, (alsf(t).t = t ⊃ W4;W3) ≠ (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(alsf(t).t) ≠ crashed, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1, pcf(t) ≠ W4, pcf(t) ≠ W7, pcf(t) ≠ W1,
pcf(t) ≠ R4, pcf(t) ≠ R3, pcf(t) ≠ R2, pcf(t) ≠ R1, pcf(t) ≠ crashed, pcf(t) ≠ ready, pcf(t) ≠ idle, pcf(t) ≠ W2,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l,
pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 71:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W5,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ W4 ≠ W5; (s)
⊦ W5 ≠ W7; (s)
⊦ W1 ≠ W5; (s)
⊦ R4 ≠ W5; (s)
⊦ R3 ≠ W5; (s)
⊦ R2 ≠ W5; (s)
⊦ R1 ≠ W5; (s)
⊦ W5 ≠ crashed; (s)
⊦ W5 ≠ ready; (s)
⊦ W5 ≠ idle; (s)
⊦ W2 ≠ W5; (s)
Proof step 71 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W5,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 72:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(t) = W5,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦
Rule argument
fma: W(alsf(t).l, alsf(t).v) ∈ bel
Additional information
Used simplifier rules:
⊦ W3 ≠ W4; (s)
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
a: ⊦ (x + y) + z = x + y + z; from specification list
⊦ W5 ≠ crashed; (s)
⊦ W5 ≠ ready; (s)
⊦ W5 ≠ idle; (s)
⊦ R4 ≠ W5; (s)
⊦ R3 ≠ W5; (s)
⊦ R2 ≠ W5; (s)
⊦ R1 ≠ W5; (s)
⊦ W5 ≠ W7; (s)
⊦ W3 ≠ W5; (s)
⊦ W2 ≠ W5; (s)
⊦ W1 ≠ W5; (s)
⊦ pendingOk(bq, pq) ∧ bq(t) = W(l, v) ' + bel0 → ¬ W(l, v0) ∈ bel0; (as)
Used formulas: W(alsf(t).l, alsf(t).v) ∈ bel
Proof step 72 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(t) = W5,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 73:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W5, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;W5), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
a: ⊦ (x + y) + z = x + y + z; from specification list
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
⊦ W(l, v) = W(l0, v0) ↔ l = l0 ∧ v = v0; (ws)
Proof step 73 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W5, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;W5), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 74:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, alsf(t).t = t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3,
pcf(t) = W5, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;W5), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦
- Proof step 77:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3,
pcf(t) = W5, alsf(t).t ≠ t, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;W5), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦
Rule argument
fma: alsf(t).t = t
Additional information
Used formulas: alsf(t).t = t
Proof step 74 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, alsf(t).t = t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3,
pcf(t) = W5, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;W5), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 75:
gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, gs.rfo(t) = [],
lsf(t).t = t, alsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, pcf(t) = W5,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, gs.bq(t), gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(t), ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ FO(alsf(t).l) ∈ bel, ¬ W(alsf(t).l, alsf(t).v) ∈ bel, ¬ SF ∈ bel,
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), gs.bq(t) = FO(alsf(t).l) ' ∨ gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + FO(alsf(t).l) '
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ W4 ≠ W5; (s)
⊦ W5 ≠ W6; (s)
⊦ W(l, v) = W(l0, v0) ↔ l = l0 ∧ v = v0; (ws)
⊦ W1 ≠ W5; (s)
⊦ W2 ≠ W5; (s)
⊦ W3 ≠ W5; (s)
⊦ W5 ≠ W7; (s)
⊦ R1 ≠ W5; (s)
⊦ R2 ≠ W5; (s)
⊦ R3 ≠ W5; (s)
⊦ R4 ≠ W5; (s)
⊦ W5 ≠ idle; (s)
⊦ W5 ≠ ready; (s)
⊦ W5 ≠ crashed; (s)
a: ⊦ (x + y) + z = x + y + z; from specification list
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
⊦ W4 ≠ W5; (s)
Proof step 75 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, gs.rfo(t) = [],
lsf(t).t = t, alsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, pcf(t) = W5,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, gs.bq(t), gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(t), ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ FO(alsf(t).l) ∈ bel, ¬ W(alsf(t).l, alsf(t).v) ∈ bel, ¬ SF ∈ bel,
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), gs.bq(t) = FO(alsf(t).l) ' ∨ gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + FO(alsf(t).l) '
⊦ |
User applied rule case distinction
And obtained the following new goals
- Proof step 76:
gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + bel, gs.bq(t) = FO(alsf(t).l) ', ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l,
ags.mem = gs.pmem, gs.rfo(t) = [], alsf(t).t = t, lsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters,
apcf(t) = W3, pcf(t) = W5, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, gs.bq(t), gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(t), ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ FO(alsf(t).l) ∈ bel, ¬ W(alsf(t).l, alsf(t).v) ∈ bel, ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 35
Additional information
Used simplifier rules:
eq-05: ⊦ x = a ' + y ∧ x = a0 ' + z → a = a0 ∧ y = z; (forward) from specification list
in-15: ⊦ x + a ' = y → a ∈ y; (forward) from specification list
a: ⊦ (x + y) + z = x + y + z; from specification list
⊦ FO(l) ≠ SF; (s)
⊦ W(l, v) ≠ FO(l0); (s)
⊦ a ∈ a0 ' ↔ a = a0; (s)
Proof step 76 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + bel, gs.bq(t) = FO(alsf(t).l) ', ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l,
ags.mem = gs.pmem, gs.rfo(t) = [], alsf(t).t = t, lsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters,
apcf(t) = W3, pcf(t) = W5, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, gs.bq(t), gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(t), ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ FO(alsf(t).l) ∈ bel, ¬ W(alsf(t).l, alsf(t).v) ∈ bel, ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ |
User applied rule subst equation
And closed the goal!
Rule argument
pos: left 2, flags: discard
Additional information
Used simplifier rules:
⊦ a ' = a0 ' + x ↔ a = a0 ∧ x = []; (ws)
⊦ W(l, v) ≠ FO(l0); (s)
a: ⊦ (x + y) + z = x + y + z; from specification list
Proof step 77 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3,
pcf(t) = W5, alsf(t).t ≠ t, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;W5), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 78:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W5, alsf(t).t ≠ t, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf), SFTrailing(gs.bq),
ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ W3 ≠ W5; (s)
⊦ W3 ≠ W4; (s)
Proof step 78 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W5, alsf(t).t ≠ t, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf), SFTrailing(gs.bq),
ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ |
Heuristic quantifier closing applied rule all left
And closed the goal!
Rule argument
pos: left 53 terms: t
Additional information
Used terms: t
Proof step 79 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W6,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))), pcf(alsf(t).t) ≠ crashed,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1, pcf(t) ≠ W4, pcf(t) ≠ W7, pcf(t) ≠ W1, pcf(t) ≠ R4, pcf(t) ≠ R3, pcf(t) ≠ R2,
pcf(t) ≠ R1, pcf(t) ≠ crashed, pcf(t) ≠ ready, pcf(t) ≠ idle, pcf(t) ≠ W2,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l,
pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 80:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W6,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ W4 ≠ W6; (s)
⊦ W6 ≠ W7; (s)
⊦ W1 ≠ W6; (s)
⊦ R4 ≠ W6; (s)
⊦ R3 ≠ W6; (s)
⊦ R2 ≠ W6; (s)
⊦ R1 ≠ W6; (s)
⊦ W6 ≠ crashed; (s)
⊦ W6 ≠ ready; (s)
⊦ W6 ≠ idle; (s)
⊦ W2 ≠ W6; (s)
Proof step 80 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W6,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 81:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(t) = W6,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦
Rule argument
fma: W(alsf(t).l, alsf(t).v) ∈ bel
Additional information
Used simplifier rules:
⊦ W3 ≠ W4; (s)
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
a: ⊦ (x + y) + z = x + y + z; from specification list
⊦ W6 ≠ crashed; (s)
⊦ W6 ≠ ready; (s)
⊦ W6 ≠ idle; (s)
⊦ R4 ≠ W6; (s)
⊦ R3 ≠ W6; (s)
⊦ R2 ≠ W6; (s)
⊦ R1 ≠ W6; (s)
⊦ W6 ≠ W7; (s)
⊦ W3 ≠ W6; (s)
⊦ W2 ≠ W6; (s)
⊦ W1 ≠ W6; (s)
⊦ pendingOk(bq, pq) ∧ bq(t) = W(l, v) ' + bel0 → ¬ W(l, v0) ∈ bel0; (as)
Used formulas: W(alsf(t).l, alsf(t).v) ∈ bel
Proof step 81 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(t) = W6,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 82:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W6, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
a: ⊦ (x + y) + z = x + y + z; from specification list
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
⊦ W(l, v) = W(l0, v0) ↔ l = l0 ∧ v = v0; (ws)
Proof step 82 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W6, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 83:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, alsf(t).t = t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3,
pcf(t) = W6, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦
- Proof step 85:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3,
pcf(t) = W6, alsf(t).t ≠ t, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf), SFTrailing(gs.bq),
ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦
Rule argument
fma: alsf(t).t = t
Additional information
Used formulas: alsf(t).t = t
Proof step 83 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, alsf(t).t = t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3,
pcf(t) = W6, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 84:
gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, gs.rfo(t) = [],
lsf(t).t = t, alsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, pcf(t) = W6,
gs.bq(t) ≠ FO(alsf(t).l) ' + SF ', FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, gs.bq(t), gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(t), ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ FO(alsf(t).l) ∈ bel, ¬ W(alsf(t).l, alsf(t).v) ∈ bel, ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + FO(alsf(t).l) ' + SF ' ∨ gs.bq(t) = SF '
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ W5 ≠ W6; (s)
⊦ W4 ≠ W6; (s)
⊦ W(l, v) ≠ FO(l0); (s)
a: ⊦ (x + y) + z = x + y + z; from specification list
in-15: ⊦ x + a ' = y → a ∈ y; (forward) from specification list
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
eq-05: ⊦ x = a ' + y ∧ x = a0 ' + z → a = a0 ∧ y = z; (forward) from specification list
⊦ W(l, v) = W(l0, v0) ↔ l = l0 ∧ v = v0; (ws)
⊦ W1 ≠ W6; (s)
⊦ W2 ≠ W6; (s)
⊦ W3 ≠ W6; (s)
⊦ W6 ≠ W7; (s)
⊦ R1 ≠ W6; (s)
⊦ R2 ≠ W6; (s)
⊦ R3 ≠ W6; (s)
⊦ R4 ≠ W6; (s)
⊦ W6 ≠ idle; (s)
⊦ W6 ≠ ready; (s)
⊦ W6 ≠ crashed; (s)
⊦ W4 ≠ W6; (s)
⊦ W4 ≠ W5; (s)
Proof step 84 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, gs.rfo(t) = [],
lsf(t).t = t, alsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, pcf(t) = W6,
gs.bq(t) ≠ FO(alsf(t).l) ' + SF ', FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, gs.bq(t), gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(t), ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ FO(alsf(t).l) ∈ bel, ¬ W(alsf(t).l, alsf(t).v) ∈ bel, ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + FO(alsf(t).l) ' + SF ' ∨ gs.bq(t) = SF '
⊦ |
User applied rule case distinction
And closed the goal!
Rule argument
pos: left 35
Additional information
Used simplifier rules:
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
⊦ a ' = a0 ' + x ↔ a = a0 ∧ x = []; (ws)
⊦ W(l, v) ≠ SF; (s)
a: ⊦ (x + y) + z = x + y + z; from specification list
eq-05: ⊦ x = a ' + y ∧ x = a0 ' + z → a = a0 ∧ y = z; (forward) from specification list
in-15: ⊦ x + a ' = y → a ∈ y; (forward) from specification list
⊦ W(l, v) ≠ FO(l0); (s)
⊦ a ∈ a0 ' ↔ a = a0; (s)
⊦ a ∈ a0 ' + x ↔ ¬(a ≠ a0 ∧ ¬ a ∈ x); (ss)
Proof step 85 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3,
pcf(t) = W6, alsf(t).t ≠ t, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf), SFTrailing(gs.bq),
ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 86:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W6, alsf(t).t ≠ t, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf), SFTrailing(gs.bq),
ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ W3 ≠ W6; (s)
⊦ W3 ≠ W5; (s)
⊦ W3 ≠ W4; (s)
Proof step 86 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W6, alsf(t).t ≠ t, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf), SFTrailing(gs.bq),
ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ |
Heuristic quantifier closing applied rule all left
And closed the goal!
Rule argument
pos: left 53 terms: t
Additional information
Used terms: t
Proof step 87 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, apcf(t) = (FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)), W(lsf(t).loc, lsf(t).val) ≠ W(alsf(alsf(t).t).l, alsf(alsf(t).t).v),
pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(lsf(t).loc, lsf(t).val) ∈ bel, pcf(t) = W7 → apcf(t) = W7, pcf(t) = W3 → apcf(t) = W3,
pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 88:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(t) = (FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)), apcf(alsf(t).t) = W3, W(lsf(t).loc, lsf(t).val) ≠ W(alsf(alsf(t).t).l, alsf(alsf(t).t).v),
pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(lsf(t).loc, lsf(t).val) ∈ bel,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W5 → apcf(t) = (FO(lsf(t).loc) ∈ bel ⊃ W4;W5), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (FO(lsf(t).loc) ∈ bel ⊃ W4;W5))
∧ (pcf(t) = W6 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = apcf(t))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
Additional information
Proof step 88 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(t) = (FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)), apcf(alsf(t).t) = W3, W(lsf(t).loc, lsf(t).val) ≠ W(alsf(alsf(t).t).l, alsf(alsf(t).t).v),
pcf(t) ≠ W4, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(lsf(t).loc, lsf(t).val) ∈ bel,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W5 → apcf(t) = (FO(lsf(t).loc) ∈ bel ⊃ W4;W5), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (FO(lsf(t).loc) ∈ bel ⊃ W4;W5))
∧ (pcf(t) = W6 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = apcf(t))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: alsf(t).t = t
Additional information
Used simplifier rules:
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
a: ⊦ (x + y) + z = x + y + z; from specification list
⊦ W3 ≠ W4; (s)
⊦ W3 ≠ W5; (s)
⊦ W3 ≠ W6; (s)
Used formulas: alsf(t).t = t
Proof step 89 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, apcf(t) = (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4),
pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3,
pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [], pcf(t) = idle → apcf(t) = idle,
pcf(t) = ready → apcf(t) = ready, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = R1 → apcf(t) = R1, pcf(t) = R2 → apcf(t) = R2,
pcf(t) = R3 → apcf(t) = R3, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l,
pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v, pcf(t) = W1 → apcf(t) = W1, pcf(t) = W3 → apcf(t) = W3, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic if-then-else split applied rule case distinction
And obtained the following new goals
- Proof step 90:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W3 → apcf(t) = W3, pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
- Proof step 113:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, apcf(t) = W4, W(lsf(t).loc, lsf(t).val) ≠ W(alsf(alsf(t).t).l, alsf(alsf(t).t).v), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(lsf(t).loc, lsf(t).val) ∈ bel,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W3 → apcf(t) = W3, pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
Rule argument
pos: left 11
Additional information
Proof step 90 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W3 → apcf(t) = W3, pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 91:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(alsf(t).t) ≠ crashed, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1, pcf(t) ≠ W7, pcf(t) ≠ W1,
pcf(t) ≠ R4, pcf(t) ≠ R3, pcf(t) ≠ R2, pcf(t) ≠ R1, pcf(t) ≠ crashed, pcf(t) ≠ ready, pcf(t) ≠ idle, pcf(t) ≠ W2,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v,
pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l, ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦ (pcf(t) = W3 → alsf(t).t ≠ t) ∧ (pcf(t) = W4 → (alsf(t).t = t ⊃ W4;W3) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ (pcf(t) = W5 → (alsf(t).t = t ⊃ W4;W3) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ (pcf(t) = W6 → (alsf(t).t = t ⊃ W4;W3) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
Rule argument
Additional information
Used simplifier rules:
⊦ lstepf(gs, ls, W3, a) = ls; (s)
⊦ pcstepf(gs, ls, W3, a) = W4; (s)
⊦ W3 ≠ W4; (s)
⊦ W2 ≠ W3; (s)
⊦ W1 ≠ W3; (s)
⊦ W3 ≠ idle; (s)
⊦ W3 ≠ ready; (s)
⊦ W3 ≠ crashed; (s)
⊦ R1 ≠ W3; (s)
⊦ R2 ≠ W3; (s)
⊦ R3 ≠ W3; (s)
⊦ R4 ≠ W3; (s)
⊦ W3 ≠ W7; (s)
Proof step 91 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(alsf(t).t) ≠ crashed, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1, pcf(t) ≠ W7, pcf(t) ≠ W1,
pcf(t) ≠ R4, pcf(t) ≠ R3, pcf(t) ≠ R2, pcf(t) ≠ R1, pcf(t) ≠ crashed, pcf(t) ≠ ready, pcf(t) ≠ idle, pcf(t) ≠ W2,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v,
pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l, ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦ (pcf(t) = W3 → alsf(t).t ≠ t) ∧ (pcf(t) = W4 → (alsf(t).t = t ⊃ W4;W3) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ (pcf(t) = W5 → (alsf(t).t = t ⊃ W4;W3) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ (pcf(t) = W6 → (alsf(t).t = t ⊃ W4;W3) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)))) |
Heuristic if-then-else split applied rule case distinction
And obtained the following new goals
- Proof step 92:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W4, (alsf(t).t = t ⊃ W4;W3) ≠ (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4), pcf(alsf(t).t) ≠ crashed,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1, pcf(t) ≠ W7, pcf(t) ≠ W1, pcf(t) ≠ R4, pcf(t) ≠ R3, pcf(t) ≠ R2, pcf(t) ≠ R1,
pcf(t) ≠ crashed, pcf(t) ≠ ready, pcf(t) ≠ idle, pcf(t) ≠ W2,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l,
pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦
- Proof step 96:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W5, (alsf(t).t = t ⊃ W4;W3) ≠ (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(alsf(t).t) ≠ crashed, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1, pcf(t) ≠ W7, pcf(t) ≠ W1, pcf(t) ≠ R4,
pcf(t) ≠ R3, pcf(t) ≠ R2, pcf(t) ≠ R1, pcf(t) ≠ crashed, pcf(t) ≠ ready, pcf(t) ≠ idle, pcf(t) ≠ W2,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l,
pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦
- Proof step 105:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W6,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))), pcf(alsf(t).t) ≠ crashed,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1, pcf(t) ≠ W7, pcf(t) ≠ W1, pcf(t) ≠ R4, pcf(t) ≠ R3, pcf(t) ≠ R2, pcf(t) ≠ R1,
pcf(t) ≠ crashed, pcf(t) ≠ ready, pcf(t) ≠ idle, pcf(t) ≠ W2,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l,
pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦
Rule argument
pos: right 1
Additional information
Used simplifier rules:
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
a: ⊦ (x + y) + z = x + y + z; from specification list
Proof step 92 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W4, (alsf(t).t = t ⊃ W4;W3) ≠ (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4), pcf(alsf(t).t) ≠ crashed,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1, pcf(t) ≠ W7, pcf(t) ≠ W1, pcf(t) ≠ R4, pcf(t) ≠ R3, pcf(t) ≠ R2, pcf(t) ≠ R1,
pcf(t) ≠ crashed, pcf(t) ≠ ready, pcf(t) ≠ idle, pcf(t) ≠ W2,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l,
pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 93:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W4,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;W4), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ W4 ≠ W7; (s)
⊦ W1 ≠ W4; (s)
⊦ R4 ≠ W4; (s)
⊦ R3 ≠ W4; (s)
⊦ R2 ≠ W4; (s)
⊦ R1 ≠ W4; (s)
⊦ W4 ≠ crashed; (s)
⊦ W4 ≠ ready; (s)
⊦ W4 ≠ idle; (s)
⊦ W2 ≠ W4; (s)
Proof step 93 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W4,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;W4), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 94:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(t) = W4,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;W4), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦
Rule argument
fma: W(alsf(t).l, alsf(t).v) ∈ bel
Additional information
Used simplifier rules:
⊦ W3 ≠ W4; (s)
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
a: ⊦ (x + y) + z = x + y + z; from specification list
⊦ W4 ≠ crashed; (s)
⊦ W4 ≠ ready; (s)
⊦ W4 ≠ idle; (s)
⊦ R4 ≠ W4; (s)
⊦ R3 ≠ W4; (s)
⊦ R2 ≠ W4; (s)
⊦ R1 ≠ W4; (s)
⊦ W4 ≠ W7; (s)
⊦ W3 ≠ W4; (s)
⊦ W2 ≠ W4; (s)
⊦ W1 ≠ W4; (s)
⊦ pendingOk(bq, pq) ∧ bq(t) = W(l, v) ' + bel0 → ¬ W(l, v0) ∈ bel0; (as)
Used formulas: W(alsf(t).l, alsf(t).v) ∈ bel
Proof step 94 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(t) = W4,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;W4), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 95:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W4, alsf(t).t ≠ t, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf), SFTrailing(gs.bq),
ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
a: ⊦ (x + y) + z = x + y + z; from specification list
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
⊦ W(l, v) = W(l0, v0) ↔ l = l0 ∧ v = v0; (ws)
⊦ W3 ≠ W4; (s)
Proof step 95 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W4, alsf(t).t ≠ t, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf), SFTrailing(gs.bq),
ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ |
Heuristic quantifier closing applied rule all left
And closed the goal!
Rule argument
pos: left 53 terms: t
Additional information
Used terms: t
Proof step 96 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W5, (alsf(t).t = t ⊃ W4;W3) ≠ (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(alsf(t).t) ≠ crashed, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2,
pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1, pcf(t) ≠ W7, pcf(t) ≠ W1, pcf(t) ≠ R4,
pcf(t) ≠ R3, pcf(t) ≠ R2, pcf(t) ≠ R1, pcf(t) ≠ crashed, pcf(t) ≠ ready, pcf(t) ≠ idle, pcf(t) ≠ W2,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l,
pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 97:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W5,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ W5 ≠ W7; (s)
⊦ W1 ≠ W5; (s)
⊦ R4 ≠ W5; (s)
⊦ R3 ≠ W5; (s)
⊦ R2 ≠ W5; (s)
⊦ R1 ≠ W5; (s)
⊦ W5 ≠ crashed; (s)
⊦ W5 ≠ ready; (s)
⊦ W5 ≠ idle; (s)
⊦ W2 ≠ W5; (s)
Proof step 97 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W5,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 98:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(t) = W5,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦
Rule argument
fma: W(alsf(t).l, alsf(t).v) ∈ bel
Additional information
Used simplifier rules:
⊦ W3 ≠ W4; (s)
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
a: ⊦ (x + y) + z = x + y + z; from specification list
⊦ W5 ≠ crashed; (s)
⊦ W5 ≠ ready; (s)
⊦ W5 ≠ idle; (s)
⊦ R4 ≠ W5; (s)
⊦ R3 ≠ W5; (s)
⊦ R2 ≠ W5; (s)
⊦ R1 ≠ W5; (s)
⊦ W5 ≠ W7; (s)
⊦ W3 ≠ W5; (s)
⊦ W2 ≠ W5; (s)
⊦ W1 ≠ W5; (s)
⊦ pendingOk(bq, pq) ∧ bq(t) = W(l, v) ' + bel0 → ¬ W(l, v0) ∈ bel0; (as)
Used formulas: W(alsf(t).l, alsf(t).v) ∈ bel
Proof step 98 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(t) = W5,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;W5)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 99:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W5, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;W5), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
a: ⊦ (x + y) + z = x + y + z; from specification list
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
⊦ W(l, v) = W(l0, v0) ↔ l = l0 ∧ v = v0; (ws)
Proof step 99 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W5, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;W5), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 100:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, alsf(t).t = t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3,
pcf(t) = W5, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;W5), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦
- Proof step 103:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3,
pcf(t) = W5, alsf(t).t ≠ t, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;W5), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦
Rule argument
fma: alsf(t).t = t
Additional information
Used formulas: alsf(t).t = t
Proof step 100 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, alsf(t).t = t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3,
pcf(t) = W5, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;W5), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 101:
gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, gs.rfo(t) = [],
lsf(t).t = t, alsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, pcf(t) = W5,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, gs.bq(t), gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(t), ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ FO(alsf(t).l) ∈ bel, ¬ W(alsf(t).l, alsf(t).v) ∈ bel, ¬ SF ∈ bel,
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), gs.bq(t) = FO(alsf(t).l) ' ∨ gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + FO(alsf(t).l) '
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ W4 ≠ W5; (s)
⊦ W5 ≠ W6; (s)
⊦ W(l, v) = W(l0, v0) ↔ l = l0 ∧ v = v0; (ws)
⊦ W1 ≠ W5; (s)
⊦ W2 ≠ W5; (s)
⊦ W3 ≠ W5; (s)
⊦ W5 ≠ W7; (s)
⊦ R1 ≠ W5; (s)
⊦ R2 ≠ W5; (s)
⊦ R3 ≠ W5; (s)
⊦ R4 ≠ W5; (s)
⊦ W5 ≠ idle; (s)
⊦ W5 ≠ ready; (s)
⊦ W5 ≠ crashed; (s)
a: ⊦ (x + y) + z = x + y + z; from specification list
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
⊦ W4 ≠ W5; (s)
Proof step 101 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, gs.rfo(t) = [],
lsf(t).t = t, alsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, pcf(t) = W5,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, gs.bq(t), gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(t), ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ FO(alsf(t).l) ∈ bel, ¬ W(alsf(t).l, alsf(t).v) ∈ bel, ¬ SF ∈ bel,
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), gs.bq(t) = FO(alsf(t).l) ' ∨ gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + FO(alsf(t).l) '
⊦ |
User applied rule case distinction
And obtained the following new goals
- Proof step 102:
gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + bel, gs.bq(t) = FO(alsf(t).l) ', ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l,
ags.mem = gs.pmem, gs.rfo(t) = [], alsf(t).t = t, lsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters,
apcf(t) = W3, pcf(t) = W5, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, gs.bq(t), gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(t), ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ FO(alsf(t).l) ∈ bel, ¬ W(alsf(t).l, alsf(t).v) ∈ bel, ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦
Rule argument
pos: left 35
Additional information
Used simplifier rules:
eq-05: ⊦ x = a ' + y ∧ x = a0 ' + z → a = a0 ∧ y = z; (forward) from specification list
in-15: ⊦ x + a ' = y → a ∈ y; (forward) from specification list
a: ⊦ (x + y) + z = x + y + z; from specification list
⊦ FO(l) ≠ SF; (s)
⊦ W(l, v) ≠ FO(l0); (s)
⊦ a ∈ a0 ' ↔ a = a0; (s)
Proof step 102 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + bel, gs.bq(t) = FO(alsf(t).l) ', ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l,
ags.mem = gs.pmem, gs.rfo(t) = [], alsf(t).t = t, lsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters,
apcf(t) = W3, pcf(t) = W5, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, gs.bq(t), gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(t), ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ FO(alsf(t).l) ∈ bel, ¬ W(alsf(t).l, alsf(t).v) ∈ bel, ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ |
User applied rule subst equation
And closed the goal!
Rule argument
pos: left 2, flags: discard
Additional information
Used simplifier rules:
⊦ a ' = a0 ' + x ↔ a = a0 ∧ x = []; (ws)
⊦ W(l, v) ≠ FO(l0); (s)
a: ⊦ (x + y) + z = x + y + z; from specification list
Proof step 103 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3,
pcf(t) = W5, alsf(t).t ≠ t, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;W5), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 104:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W5, alsf(t).t ≠ t, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf), SFTrailing(gs.bq),
ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ W3 ≠ W5; (s)
⊦ W3 ≠ W4; (s)
Proof step 104 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W5, alsf(t).t ≠ t, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf), SFTrailing(gs.bq),
ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ |
Heuristic quantifier closing applied rule all left
And closed the goal!
Rule argument
pos: left 53 terms: t
Additional information
Used terms: t
Proof step 105 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W6,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))), pcf(alsf(t).t) ≠ crashed,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1, pcf(t) ≠ W7, pcf(t) ≠ W1, pcf(t) ≠ R4, pcf(t) ≠ R3, pcf(t) ≠ R2, pcf(t) ≠ R1,
pcf(t) ≠ crashed, pcf(t) ≠ ready, pcf(t) ≠ idle, pcf(t) ≠ W2,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l,
pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 106:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W6,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ W6 ≠ W7; (s)
⊦ W1 ≠ W6; (s)
⊦ R4 ≠ W6; (s)
⊦ R3 ≠ W6; (s)
⊦ R2 ≠ W6; (s)
⊦ R1 ≠ W6; (s)
⊦ W6 ≠ crashed; (s)
⊦ W6 ≠ ready; (s)
⊦ W6 ≠ idle; (s)
⊦ W2 ≠ W6; (s)
Proof step 106 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3, pcf(t) = W6,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 107:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(t) = W6,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦
Rule argument
fma: W(alsf(t).l, alsf(t).v) ∈ bel
Additional information
Used simplifier rules:
⊦ W3 ≠ W4; (s)
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
a: ⊦ (x + y) + z = x + y + z; from specification list
⊦ W6 ≠ crashed; (s)
⊦ W6 ≠ ready; (s)
⊦ W6 ≠ idle; (s)
⊦ R4 ≠ W6; (s)
⊦ R3 ≠ W6; (s)
⊦ R2 ≠ W6; (s)
⊦ R1 ≠ W6; (s)
⊦ W6 ≠ W7; (s)
⊦ W3 ≠ W6; (s)
⊦ W2 ≠ W6; (s)
⊦ W1 ≠ W6; (s)
⊦ pendingOk(bq, pq) ∧ bq(t) = W(l, v) ' + bel0 → ¬ W(l, v0) ∈ bel0; (as)
Used formulas: W(alsf(t).l, alsf(t).v) ∈ bel
Proof step 107 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
bq(alsf(t).t).head.v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3, pcf(t) = W6,
(alsf(t).t = t ⊃ W4;W3) ≠ (W(alsf(t).l, alsf(t).v) ∈ bel ⊃ W3;(FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)), W(alsf(t).l, alsf(t).v) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(alsf(t).l, alsf(t).v) ∈ bel
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 108:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W6, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
a: ⊦ (x + y) + z = x + y + z; from specification list
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
⊦ W(l, v) = W(l0, v0) ↔ l = l0 ∧ v = v0; (ws)
Proof step 108 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W6, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 109:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, alsf(t).t = t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3,
pcf(t) = W6, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦
- Proof step 111:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3,
pcf(t) = W6, alsf(t).t ≠ t, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf), SFTrailing(gs.bq),
ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦
Rule argument
fma: alsf(t).t = t
Additional information
Used formulas: alsf(t).t = t
Proof step 109 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, alsf(t).t = t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3,
pcf(t) = W6, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3,
pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready,
pcf(alsf(t).t) ≠ crashed, FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t),
¬ noPending(alsf(t).t, gs.bq, gs.pq), ¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 110:
gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, gs.rfo(t) = [],
lsf(t).t = t, alsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, pcf(t) = W6,
gs.bq(t) ≠ FO(alsf(t).l) ' + SF ', FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, gs.bq(t), gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(t), ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ FO(alsf(t).l) ∈ bel, ¬ W(alsf(t).l, alsf(t).v) ∈ bel, ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + FO(alsf(t).l) ' + SF ' ∨ gs.bq(t) = SF '
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ W5 ≠ W6; (s)
⊦ W4 ≠ W6; (s)
⊦ W(l, v) ≠ FO(l0); (s)
a: ⊦ (x + y) + z = x + y + z; from specification list
in-15: ⊦ x + a ' = y → a ∈ y; (forward) from specification list
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
eq-05: ⊦ x = a ' + y ∧ x = a0 ' + z → a = a0 ∧ y = z; (forward) from specification list
⊦ W(l, v) = W(l0, v0) ↔ l = l0 ∧ v = v0; (ws)
⊦ W1 ≠ W6; (s)
⊦ W2 ≠ W6; (s)
⊦ W3 ≠ W6; (s)
⊦ W6 ≠ W7; (s)
⊦ R1 ≠ W6; (s)
⊦ R2 ≠ W6; (s)
⊦ R3 ≠ W6; (s)
⊦ R4 ≠ W6; (s)
⊦ W6 ≠ idle; (s)
⊦ W6 ≠ ready; (s)
⊦ W6 ≠ crashed; (s)
⊦ W4 ≠ W6; (s)
⊦ W4 ≠ W5; (s)
Proof step 110 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(t).head.l = alsf(t).l, lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, gs.rfo(t) = [],
lsf(t).t = t, alsf(t).t = t, bq(t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, pcf(t) = W6,
gs.bq(t) ≠ FO(alsf(t).l) ' + SF ', FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, t) ')).bq:= gs.bq(t := bel), lsf, pcf),
FOFollowsW(t, gs.bq(t), gs.pq(alsf(t).l), alsf(t).l), SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), notMember(t, gs.freaders),
oneMember(t, alsf(t).l, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(t), ¬ noPending(t, gs.bq, gs.pq),
¬ noPendingW(t, gs.bq, gs.pq), ¬ FO(alsf(t).l) ∈ bel, ¬ W(alsf(t).l, alsf(t).v) ∈ bel, ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
gs.bq(t) = W(alsf(t).l, alsf(t).v) ' + FO(alsf(t).l) ' + SF ' ∨ gs.bq(t) = SF '
⊦ |
User applied rule case distinction
And closed the goal!
Rule argument
pos: left 35
Additional information
Used simplifier rules:
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
⊦ a ' = a0 ' + x ↔ a = a0 ∧ x = []; (ws)
⊦ W(l, v) ≠ SF; (s)
a: ⊦ (x + y) + z = x + y + z; from specification list
eq-05: ⊦ x = a ' + y ∧ x = a0 ' + z → a = a0 ∧ y = z; (forward) from specification list
in-15: ⊦ x + a ' = y → a ∈ y; (forward) from specification list
⊦ W(l, v) ≠ FO(l0); (s)
⊦ a ∈ a0 ' ↔ a = a0; (s)
⊦ a ∈ a0 ' + x ↔ ¬(a ≠ a0 ∧ ¬ a ∈ x); (ss)
Proof step 111 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, alsf(t).l = alsf(alsf(t).t).l, bq(alsf(t).t).head.l = alsf(t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t,
alsf(t).v = alsf(alsf(t).t).v, bq(alsf(t).t).head.v = alsf(t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(alsf(t).t) = W3, apcf(t) = W3,
pcf(t) = W6, alsf(t).t ≠ t, (alsf(t).t = t ⊃ W4;W3) ≠ (FO(alsf(t).l) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf), SFTrailing(gs.bq),
ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 112:
gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W6, alsf(t).t ≠ t, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf), SFTrailing(gs.bq),
ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ W3 ≠ W6; (s)
⊦ W3 ≠ W5; (s)
⊦ W3 ≠ W4; (s)
Proof step 112 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(t).l, alsf(t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(t).l, alsf(t).l = alsf(alsf(t).t).l,
lsf(t).loc = alsf(t).l, ags.mem = gs.pmem, alsf(t).t = alsf(alsf(t).t).t, lsf(t).t = alsf(t).t, lsf(alsf(t).t).t = alsf(t).t,
bq(alsf(t).t).head.v = alsf(t).v, alsf(t).v = alsf(alsf(t).t).v, lsf(t).val = alsf(t).v, ags.writers = gs.fwriters, apcf(t) = W3, apcf(alsf(t).t) = W3,
pcf(t) = W6, alsf(t).t ≠ t, pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1,
pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(t).l := gs.pq(alsf(t).l) + W(alsf(t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf), SFTrailing(gs.bq),
ctrok(gs.fctr, gs.fwriters), pendingOk(gs.bq, gs.pq), pendingOk(ags.p), readFOsOk(gs.rfo, gs.fwriters), reorder(ags.p, gs.pq, gs.rfo),
writersOk(gs.bq, gs.pq, gs.fwriters), writersOk(ags.p, gs.fwriters), W(alsf(t).l, alsf(t).v) ∈ gs.bq(alsf(t).t), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(alsf(t).l, alsf(t).v) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(t).l, alsf(t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t))
⊦ |
Heuristic quantifier closing applied rule all left
And closed the goal!
Rule argument
pos: left 53 terms: t
Additional information
Used terms: t
Proof step 113 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, apcf(t) = W4, W(lsf(t).loc, lsf(t).val) ≠ W(alsf(alsf(t).t).l, alsf(alsf(t).t).v), pcf(alsf(t).t) ≠ W1, pcf(alsf(t).t) ≠ W2,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W7, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ idle,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ crashed,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(lsf(t).loc, lsf(t).val) ∈ bel,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).val = alsf(t).v,
pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7 → lsf(t).loc = alsf(t).l, pcf(t) = W7 → apcf(t) = W7,
pcf(t) = W3 → apcf(t) = W3, pcf(t) = W1 → apcf(t) = W1, pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).val = alsf(t).v,
pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4 → lsf(t).loc = alsf(t).l, pcf(t) = R4 → apcf(t) = R4, pcf(t) = R3 → apcf(t) = R3,
pcf(t) = R2 → apcf(t) = R2, pcf(t) = R1 → apcf(t) = R1, pcf(t) = crashed → apcf(t) = crashed, pcf(t) = ready → apcf(t) = ready,
pcf(t) = idle → apcf(t) = idle, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W6
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel
⊃ W3
;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(t) = W5
→ apcf(t)
= (W(lsf(t).loc, lsf(t).val) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ∨ W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)),
pcf(t) = W2 → apcf(t) = (SF ∈ bel ⊃ W1;W2), pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ alsf(t).t = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).t
∧ (pcf(t) = idle → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = idle)
∧ (pcf(t) = ready → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = ready)
∧ (pcf(t) = crashed → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = crashed)
∧ (pcf(t) = R1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R1)
∧ (pcf(t) = R2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R2)
∧ (pcf(t) = R3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R3)
∧ (pcf(t) = R4 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = R4)
∧ ( pcf(t) = R1 ∨ pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = R2 ∨ pcf(t) = R3 ∨ pcf(t) = R4
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v)
∧ (pcf(t) = W1 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W1)
∧ (pcf(t) = W2 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (SF ∈ bel ⊃ W1;W2))
∧ (pcf(t) = W3 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W3)
∧ ( pcf(t) = W4
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;W4))
∧ ( pcf(t) = W5
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;W5)))
∧ ( pcf(t) = W6
→ (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))
= (W(lsf(t).loc, lsf(t).val) ∈ bel ⊃ W3;(FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))))
∧ (pcf(t) = W7 → (alsf(t).t = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t)) = W7)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).loc = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).l)
∧ ( pcf(t) = W1 ∨ pcf(t) = W2 ∨ pcf(t) = W3 ∨ pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 ∨ pcf(t) = W7
→ lsf(t).val = (alsf(t).t = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)).v) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 114:
gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, apcf(t) = W4, W(lsf(t).loc, lsf(t).val) ≠ W(alsf(alsf(t).t).l, alsf(alsf(t).t).v), pcf(alsf(t).t) ≠ crashed,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1, pcf(t) ≠ W7, pcf(t) ≠ W3, pcf(t) ≠ W1, pcf(t) ≠ R4, pcf(t) ≠ R3, pcf(t) ≠ R2,
pcf(t) ≠ R1, pcf(t) ≠ crashed, pcf(t) ≠ ready, pcf(t) ≠ idle, pcf(t) ≠ W2,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(lsf(t).loc, lsf(t).val) ∈ bel, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(t) = W6 → FO(lsf(t).loc) ∈ bel, pcf(t) = W5 → FO(lsf(t).loc) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v, pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l,
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ (pcf(t) = W4 → alsf(t).t ≠ t) ∧ (pcf(t) = W5 → (alsf(t).t = t ⊃ W5;W4) = (FO(lsf(t).loc) ∈ bel ⊃ W4;W5))
∧ (pcf(t) = W6 → (alsf(t).t = t ⊃ W5;W4) = (FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6)))
Rule argument
Additional information
Used simplifier rules:
⊦ lstepf(gs, ls, W4, a) = ls; (s)
⊦ pcstepf(gs, ls, W4, a) = W5; (s)
⊦ W4 ≠ W5; (s)
⊦ W2 ≠ W4; (s)
⊦ W1 ≠ W4; (s)
⊦ W4 ≠ idle; (s)
⊦ W4 ≠ ready; (s)
⊦ W4 ≠ crashed; (s)
⊦ R1 ≠ W4; (s)
⊦ R2 ≠ W4; (s)
⊦ R3 ≠ W4; (s)
⊦ R4 ≠ W4; (s)
⊦ W3 ≠ W4; (s)
⊦ W4 ≠ W7; (s)
⊦ W4 ≠ W6; (s)
Proof step 114 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(alsf(t).t) = W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) ' + bel, ags.ctr = gs.fctr, bq(alsf(t).t).head.l = alsf(alsf(t).t).l, ags.mem = gs.pmem,
lsf(alsf(t).t).t = alsf(t).t, lsf(t).t = alsf(t).t, alsf(t).t = alsf(alsf(t).t).t, bq(alsf(t).t).head.v = alsf(alsf(t).t).v, ags.writers = gs.fwriters,
apcf(alsf(t).t) = W3, apcf(t) = W4, W(lsf(t).loc, lsf(t).val) ≠ W(alsf(alsf(t).t).l, alsf(alsf(t).t).v), pcf(alsf(t).t) ≠ crashed,
pcf(alsf(t).t) ≠ ready, pcf(alsf(t).t) ≠ idle, pcf(alsf(t).t) ≠ R4, pcf(alsf(t).t) ≠ R3, pcf(alsf(t).t) ≠ R2, pcf(alsf(t).t) ≠ R1, pcf(alsf(t).t) ≠ W7,
pcf(alsf(t).t) ≠ W3, pcf(alsf(t).t) ≠ W2, pcf(alsf(t).t) ≠ W1, pcf(t) ≠ W7, pcf(t) ≠ W3, pcf(t) ≠ W1, pcf(t) ≠ R4, pcf(t) ≠ R3, pcf(t) ≠ R2,
pcf(t) ≠ R1, pcf(t) ≠ crashed, pcf(t) ≠ ready, pcf(t) ≠ idle, pcf(t) ≠ W2,
FLITInv((gs.pq:= gs.pq(alsf(alsf(t).t).l := gs.pq(alsf(alsf(t).t).l) + W(alsf(alsf(t).t).v, alsf(t).t) ')).bq:= gs.bq(alsf(t).t := bel), lsf, pcf),
SFTrailing(gs.bq), ctrok(gs.fctr, gs.fwriters), pendingOk(ags.p), pendingOk(gs.bq, gs.pq), readFOsOk(gs.rfo, gs.fwriters),
reorder(ags.p, gs.pq, gs.rfo), writersOk(ags.p, gs.fwriters), writersOk(gs.bq, gs.pq, gs.fwriters), ¬ noPending(alsf(t).t, gs.bq, gs.pq),
¬ noPendingW(alsf(t).t, gs.bq, gs.pq), ¬ W(lsf(t).loc, lsf(t).val) ∈ bel, pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 → ¬ SF ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → W(alsf(alsf(t).t).l, alsf(alsf(t).t).v) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val),
pcf(t) = W6 → FO(lsf(t).loc) ∈ bel, pcf(t) = W5 → FO(lsf(t).loc) ∈ bel,
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → gs.rfo(alsf(t).t) = [],
pcf(alsf(t).t) = W4 → gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ',
pcf(alsf(t).t) = W5
→ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' ∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ',
pcf(alsf(t).t) = W6
→ gs.bq(alsf(t).t) = SF ' ∨ gs.bq(alsf(t).t) = FO(lsf(alsf(t).t).loc) ' + SF '
∨ gs.bq(alsf(t).t) = W(lsf(alsf(t).t).loc, lsf(alsf(t).t).val) ' + FO(lsf(alsf(t).t).loc) ' + SF ',
pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → FOFollowsW(alsf(t).t, gs.bq(alsf(t).t), gs.pq(lsf(alsf(t).t).loc), lsf(alsf(t).t).loc),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → notMember(alsf(t).t, gs.freaders),
pcf(alsf(t).t) = W4 ∨ pcf(alsf(t).t) = W5 ∨ pcf(alsf(t).t) = W6 → oneMember(alsf(t).t, lsf(alsf(t).t).loc, gs.fwriters),
pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).val = alsf(t).v, pcf(t) = W4 ∨ pcf(t) = W5 ∨ pcf(t) = W6 → lsf(t).loc = alsf(t).l,
∀ t. alsf(t).t = t ∧ FLITPSCLInv(ags, alsf(t), apcf(t)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ (pcf(t) = W4 → alsf(t).t ≠ t) ∧ (pcf(t) = W5 → (alsf(t).t = t ⊃ W5;W4) = (FO(lsf(t).loc) ∈ bel ⊃ W4;W5))
∧ (pcf(t) = W6 → (alsf(t).t = t ⊃ W5;W4) = (FO(lsf(t).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))) |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: alsf(t).t = t
Additional information
Used simplifier rules:
⊦ W4 ≠ W5; (s)
⊦ W4 ≠ W6; (s)
⊦ W5 ≠ W6; (s)
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
a: ⊦ (x + y) + z = x + y + z; from specification list
⊦ W3 ≠ W4; (s)
Used formulas: alsf(t).t = t
Proof step 115 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.bq(tid0) ≠ [],
apcf(tid0) ≠ W3, FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)), reorder(ags.p, gs.pq, gs.rfo),
W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
= gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf(tid0 := lstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf(tid0 := pcstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).mem = gs.pmem
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).ctr = gs.fctr
∧ reorder
(gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).p,
gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).writers = gs.fwriters
∧ labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))) |
User applied rule constructor cut
And closed the goal!
Rule argument
term: apcf(tid0)
Additional information
Used simplifier rules:
FLITPSCPC
freely generated by R1, R2, R3, R4, W1, W2, W3, W4, W5, W6, W7, crashed, idle, ready
;;
⊦ W3 ≠ ready; (s)
⊦ pre(gs, ls, ready, a)
↔ (∃ l0, v0. a = invFLITPSCWRITE(ls.t, l0, v0)) ∨ (∃ l0. a = invFLITPSCREAD(ls.t, l0))
∨ a = callPSCCOMPLETE(ls.t) ∧ (∀ l. ¬ FO(ls.t) ∈ gs.p(l)); (s)
⊦ doWritePSC(t, l, v) ≠ invFLITPSCWRITE(t0, l0, v0); (s)
⊦ doWritePSC(t, l, v) ≠ invFLITPSCREAD(t0, l0); (s)
⊦ callPSCCOMPLETE(t) ≠ doWritePSC(t0, l, v); (s)
⊦ W3 ≠ idle; (s)
⊦ pre(gs, ls, idle, a) ↔ a = callPSCRUN(ls.t); (s)
⊦ callPSCRUN(t) ≠ doWritePSC(t0, l, v); (s)
⊦ W3 ≠ crashed; (s)
⊦ pre(gs, ls, crashed, a) ↔ false; (s)
⊦ W3 ≠ W7; (s)
⊦ pre(gs, ls, W7, a) ↔ a = retFLITPSCWRITE(ls.t); (s)
⊦ doWritePSC(t, l, v) ≠ retFLITPSCWRITE(t0); (s)
⊦ W3 ≠ W6; (s)
⊦ pre(gs, ls, W6, a) ↔ a = ctrDecPSC(ls.t, ls.l); (s)
⊦ ctrDecPSC(t, l) ≠ doWritePSC(t0, l0, v); (s)
⊦ W3 ≠ W5; (s)
⊦ pre(gs, ls, W5, a) ↔ (∀ l. ¬ FO(ls.t) ∈ gs.p(l)) ∧ a = sfencePSC(ls.t); (s)
⊦ reorder(p, pq, rfo) → (FO(t) ∈ p(l) ↔ FO(t) ∈ pq(l) ∨ FO(l) ∈ rfo(t)); (s)
⊦ doWritePSC(t, l, v) ≠ sfencePSC(t0); (s)
⊦ W3 ≠ W4; (s)
⊦ pre(gs, ls, W4, a) ↔ a = pwbPSC(ls.t, ls.l); (s)
⊦ doWritePSC(t, l, v) ≠ pwbPSC(t0, l0); (s)
⊦ W2 ≠ W3; (s)
⊦ pre(gs, ls, W2, a) ↔ a = ctrIncPSC(ls.t, ls.l); (s)
⊦ ctrIncPSC(t, l) ≠ doWritePSC(t0, l0, v); (s)
⊦ W1 ≠ W3; (s)
⊦ pre(gs, ls, W1, a) ↔ (∀ l. ¬ FO(ls.t) ∈ gs.p(l)) ∧ a = sfencePSC(ls.t); (s)
⊦ R4 ≠ W3; (s)
⊦ pre(gs, ls, R4, a) ↔ a = retFLITPSCREAD(ls.t, ls.v); (s)
⊦ doWritePSC(t, l, v) ≠ retFLITPSCREAD(t0, v0); (s)
⊦ R3 ≠ W3; (s)
⊦ pre(gs, ls, R3, a) ↔ a = pwbPSC(ls.t, ls.l); (s)
⊦ R2 ≠ W3; (s)
⊦ pre(gs, ls, R2, a) ↔ a = ctrReadPSC(ls.t, ls.l, gs.ctr(ls.l)); (s)
⊦ ctrReadPSC(t, l, n) ≠ doWritePSC(t0, l0, v); (s)
⊦ R1 ≠ W3; (s)
⊦ pre(gs, ls, R1, a) ↔ a = doReadPSC(ls.t, ls.l, ((gs.mem ⊕ gs.p))(ls.l)); (s)
⊦ ((mem ⊕ p))(l) = mem(l) ⊕ p(l); (s)
⊦ doReadPSC(t, l, v) ≠ doWritePSC(t0, l0, v0); (s)
Proof step 116 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ (∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
= gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
∧ alsf(tid0 := lstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
∧ apcf(tid0 := pcstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)))
= apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))))
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).mem = gs.pmem
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).ctr = gs.fctr
∧ reorder
(gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).p,
gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) '), gs.rfo)
∧ gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)).writers = gs.fwriters
∧ labs
((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf(t), pcf(t),
gstepf(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
(tid0 = t ⊃ lstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));alsf(t)),
(tid0 = t ⊃ pcstepf(ags, alsf(t), apcf(t), doWritePSC(t, bq(t).head.l, bq(t).head.v));apcf(t))) |
User applied rule weakening
And obtained the following new goals
- Proof step 117:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦
Rule argument
poslist: left 4, right 1
Additional information
Proof step 117 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, gs.bq(tid0) ≠ [], FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ |
User applied rule all left
And obtained the following new goals
- Proof step 118:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), labs(gs, lsf(tid0), pcf(tid0), ags, alsf(tid0), apcf(tid0)), reorder(ags.p, gs.pq, gs.rfo),
W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0), ¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
⊦
Rule argument
pos: left 11 terms: tid0 abort: F discard: T computed: T
Additional information
Used terms: tid0
Proof step 118 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, gs.bq(tid0) ≠ [],
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), labs(gs, lsf(tid0), pcf(tid0), ags, alsf(tid0), apcf(tid0)), reorder(ags.p, gs.pq, gs.rfo),
W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0), ¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v))
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 119:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, lsf(tid0).t = alsf(tid0).t, gs.bq(tid0) ≠ [],
FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)), pcf(tid0) = idle → apcf(tid0) = idle,
pcf(tid0) = ready → apcf(tid0) = ready, pcf(tid0) = crashed → apcf(tid0) = crashed, pcf(tid0) = R1 → apcf(tid0) = R1, pcf(tid0) = R2 → apcf(tid0) = R2,
pcf(tid0) = R3 → apcf(tid0) = R3, pcf(tid0) = R4 → apcf(tid0) = R4,
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).val = alsf(tid0).v, pcf(tid0) = W1 → apcf(tid0) = W1,
pcf(tid0) = W2 → apcf(tid0) = (SF ∈ gs.bq(alsf(tid0).t) ⊃ W1;W2), pcf(tid0) = W3 → apcf(tid0) = W3,
pcf(tid0) = W4 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;W4),
pcf(tid0) = W5 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(alsf(tid0).t) ⊃ W4;W5)),
pcf(tid0) = W6
→ apcf(tid0)
= (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(alsf(tid0).t) ⊃ W4;(SF ∈ gs.bq(alsf(tid0).t) ⊃ W5;W6))),
pcf(tid0) = W7 → apcf(tid0) = W7,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).val = alsf(tid0).v
⊦
Rule argument
Additional information
Used simplifier rules:
labs-def: ⊦ labs(gs, ls, pc, ags, als, apc)
↔ ls.t = als.t ∧ (pc = idle → apc = idle) ∧ (pc = ready → apc = ready)
∧ (pc = crashed → apc = crashed) ∧ (pc = R1 → apc = R1) ∧ (pc = R2 → apc = R2)
∧ (pc = R3 → apc = R3) ∧ (pc = R4 → apc = R4)
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → ls.loc = als.l)
∧ (pc = R2 ∨ pc = R3 ∨ pc = R4 → ls.val = als.v) ∧ (pc = W1 → apc = W1)
∧ (pc = W2 → apc = (SF ∈ gs.bq(ls.t) ⊃ W1;W2)) ∧ (pc = W3 → apc = W3)
∧ (pc = W4 → apc = (W(ls.loc, ls.val) ∈ gs.bq(ls.t) ⊃ W3;W4))
∧ ( pc = W5
→ apc = (W(ls.loc, ls.val) ∈ gs.bq(ls.t) ⊃ W3;(FO(ls.loc) ∈ gs.bq(ls.t) ⊃ W4;W5)))
∧ ( pc = W6
→ apc
= (W(ls.loc, ls.val) ∈ gs.bq(ls.t)
⊃ W3
;(FO(ls.loc) ∈ gs.bq(ls.t) ⊃ W4;(SF ∈ gs.bq(ls.t) ⊃ W5;W6))
))
∧ (pc = W7 → apc = W7)
∧ ( pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7
→ ls.loc = als.l)
∧ ( pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7
→ ls.val = als.v);
Proof step 119 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, lsf(tid0).t = alsf(tid0).t, gs.bq(tid0) ≠ [],
FLITInv(gs, lsf, pcf),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)), pcf(tid0) = idle → apcf(tid0) = idle,
pcf(tid0) = ready → apcf(tid0) = ready, pcf(tid0) = crashed → apcf(tid0) = crashed, pcf(tid0) = R1 → apcf(tid0) = R1, pcf(tid0) = R2 → apcf(tid0) = R2,
pcf(tid0) = R3 → apcf(tid0) = R3, pcf(tid0) = R4 → apcf(tid0) = R4,
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).val = alsf(tid0).v, pcf(tid0) = W1 → apcf(tid0) = W1,
pcf(tid0) = W2 → apcf(tid0) = (SF ∈ gs.bq(alsf(tid0).t) ⊃ W1;W2), pcf(tid0) = W3 → apcf(tid0) = W3,
pcf(tid0) = W4 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;W4),
pcf(tid0) = W5 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(alsf(tid0).t) ⊃ W4;W5)),
pcf(tid0) = W6
→ apcf(tid0)
= (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(alsf(tid0).t) ⊃ W4;(SF ∈ gs.bq(alsf(tid0).t) ⊃ W5;W6))),
pcf(tid0) = W7 → apcf(tid0) = W7,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).val = alsf(tid0).v
⊦ |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 120:
⊦ FLITInv(gs, lsf, pcf) ↔ FLITGInv(gs) ∧ (∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t)))
- Proof step 121:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, lsf(tid0).t = alsf(tid0).t, gs.bq(tid0) ≠ [],
FLITGInv(gs), FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).val = alsf(tid0).v,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = W7 → apcf(tid0) = W7,
pcf(tid0) = W6
→ apcf(tid0)
= (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(alsf(tid0).t) ⊃ W4;(SF ∈ gs.bq(alsf(tid0).t) ⊃ W5;W6))),
pcf(tid0) = W5 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(alsf(tid0).t) ⊃ W4;W5)),
pcf(tid0) = W4 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;W4), pcf(tid0) = W3 → apcf(tid0) = W3,
pcf(tid0) = W2 → apcf(tid0) = (SF ∈ gs.bq(alsf(tid0).t) ⊃ W1;W2), pcf(tid0) = W1 → apcf(tid0) = W1,
pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).val = alsf(tid0).v,
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).loc = alsf(tid0).l, pcf(tid0) = R4 → apcf(tid0) = R4,
pcf(tid0) = R3 → apcf(tid0) = R3, pcf(tid0) = R2 → apcf(tid0) = R2, pcf(tid0) = R1 → apcf(tid0) = R1, pcf(tid0) = crashed → apcf(tid0) = crashed,
pcf(tid0) = ready → apcf(tid0) = ready, pcf(tid0) = idle → apcf(tid0) = idle, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦
Rule argument
spec: FLIT, name:FLITInv,
seq:⊦ FLITInv(gs, lsf, pcf)
↔ FLITGInv(gs) ∧ (∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))),
subst:[gs, lsf, pcf] → [gs, lsf, pcf], <all paths>
Additional information
Used terms: gs, lsf, pcf
Proof step 120 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⊦ FLITInv(gs, lsf, pcf) ↔ FLITGInv(gs) ∧ (∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))) |
A spec-lemma
Proof step 121 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, lsf(tid0).t = alsf(tid0).t, gs.bq(tid0) ≠ [],
FLITGInv(gs), FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).val = alsf(tid0).v,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = W7 → apcf(tid0) = W7,
pcf(tid0) = W6
→ apcf(tid0)
= (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(alsf(tid0).t) ⊃ W4;(SF ∈ gs.bq(alsf(tid0).t) ⊃ W5;W6))),
pcf(tid0) = W5 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(alsf(tid0).t) ⊃ W4;W5)),
pcf(tid0) = W4 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;W4), pcf(tid0) = W3 → apcf(tid0) = W3,
pcf(tid0) = W2 → apcf(tid0) = (SF ∈ gs.bq(alsf(tid0).t) ⊃ W1;W2), pcf(tid0) = W1 → apcf(tid0) = W1,
pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).val = alsf(tid0).v,
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).loc = alsf(tid0).l, pcf(tid0) = R4 → apcf(tid0) = R4,
pcf(tid0) = R3 → apcf(tid0) = R3, pcf(tid0) = R2 → apcf(tid0) = R2, pcf(tid0) = R1 → apcf(tid0) = R1, pcf(tid0) = crashed → apcf(tid0) = crashed,
pcf(tid0) = ready → apcf(tid0) = ready, pcf(tid0) = idle → apcf(tid0) = idle, ∀ t. lsf(t).t = t ∧ FLITLInv(gs, lsf(t), pcf(t))
⊦ |
User applied rule all left
And obtained the following new goals
- Proof step 122:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, lsf(tid0).t = alsf(tid0).t, lsf(tid0).t = tid0,
gs.bq(tid0) ≠ [], FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITLInv(gs, lsf(tid0), pcf(tid0)), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)), pcf(tid0) = idle → apcf(tid0) = idle,
pcf(tid0) = ready → apcf(tid0) = ready, pcf(tid0) = crashed → apcf(tid0) = crashed, pcf(tid0) = R1 → apcf(tid0) = R1, pcf(tid0) = R2 → apcf(tid0) = R2,
pcf(tid0) = R3 → apcf(tid0) = R3, pcf(tid0) = R4 → apcf(tid0) = R4,
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).val = alsf(tid0).v, pcf(tid0) = W1 → apcf(tid0) = W1,
pcf(tid0) = W2 → apcf(tid0) = (SF ∈ gs.bq(alsf(tid0).t) ⊃ W1;W2), pcf(tid0) = W3 → apcf(tid0) = W3,
pcf(tid0) = W4 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;W4),
pcf(tid0) = W5 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(alsf(tid0).t) ⊃ W4;W5)),
pcf(tid0) = W6
→ apcf(tid0)
= (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(alsf(tid0).t) ⊃ W4;(SF ∈ gs.bq(alsf(tid0).t) ⊃ W5;W6))),
pcf(tid0) = W7 → apcf(tid0) = W7,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).val = alsf(tid0).v
⊦
Rule argument
pos: left 30 terms: tid0 abort: F discard: T computed: F
Additional information
Used terms: tid0
Proof step 122 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, lsf(tid0).t = alsf(tid0).t, lsf(tid0).t = tid0,
gs.bq(tid0) ≠ [], FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITLInv(gs, lsf(tid0), pcf(tid0)), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)), pcf(tid0) = idle → apcf(tid0) = idle,
pcf(tid0) = ready → apcf(tid0) = ready, pcf(tid0) = crashed → apcf(tid0) = crashed, pcf(tid0) = R1 → apcf(tid0) = R1, pcf(tid0) = R2 → apcf(tid0) = R2,
pcf(tid0) = R3 → apcf(tid0) = R3, pcf(tid0) = R4 → apcf(tid0) = R4,
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).val = alsf(tid0).v, pcf(tid0) = W1 → apcf(tid0) = W1,
pcf(tid0) = W2 → apcf(tid0) = (SF ∈ gs.bq(alsf(tid0).t) ⊃ W1;W2), pcf(tid0) = W3 → apcf(tid0) = W3,
pcf(tid0) = W4 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;W4),
pcf(tid0) = W5 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(alsf(tid0).t) ⊃ W4;W5)),
pcf(tid0) = W6
→ apcf(tid0)
= (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(alsf(tid0).t) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(alsf(tid0).t) ⊃ W4;(SF ∈ gs.bq(alsf(tid0).t) ⊃ W5;W6))),
pcf(tid0) = W7 → apcf(tid0) = W7,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).val = alsf(tid0).v
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 123:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, alsf(tid0).t = tid0, lsf(tid0).t = tid0,
gs.bq(tid0) ≠ [], FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITLInv(gs, lsf(tid0), pcf(tid0)), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).val = alsf(tid0).v,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = W7 → apcf(tid0) = W7,
pcf(tid0) = W6 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(tid0) ⊃ W4;(SF ∈ gs.bq(tid0) ⊃ W5;W6))),
pcf(tid0) = W5 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(tid0) ⊃ W4;W5)),
pcf(tid0) = W4 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;W4), pcf(tid0) = W3 → apcf(tid0) = W3,
pcf(tid0) = W2 → apcf(tid0) = (SF ∈ gs.bq(tid0) ⊃ W1;W2), pcf(tid0) = W1 → apcf(tid0) = W1,
pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).val = alsf(tid0).v,
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).loc = alsf(tid0).l, pcf(tid0) = R4 → apcf(tid0) = R4,
pcf(tid0) = R3 → apcf(tid0) = R3, pcf(tid0) = R2 → apcf(tid0) = R2, pcf(tid0) = R1 → apcf(tid0) = R1, pcf(tid0) = crashed → apcf(tid0) = crashed,
pcf(tid0) = ready → apcf(tid0) = ready, pcf(tid0) = idle → apcf(tid0) = idle
⊦
Rule argument
Additional information
Proof step 123 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, alsf(tid0).t = tid0, lsf(tid0).t = tid0,
gs.bq(tid0) ≠ [], FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITLInv(gs, lsf(tid0), pcf(tid0)), FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).val = alsf(tid0).v,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = W7 → apcf(tid0) = W7,
pcf(tid0) = W6 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(tid0) ⊃ W4;(SF ∈ gs.bq(tid0) ⊃ W5;W6))),
pcf(tid0) = W5 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(tid0) ⊃ W4;W5)),
pcf(tid0) = W4 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;W4), pcf(tid0) = W3 → apcf(tid0) = W3,
pcf(tid0) = W2 → apcf(tid0) = (SF ∈ gs.bq(tid0) ⊃ W1;W2), pcf(tid0) = W1 → apcf(tid0) = W1,
pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).val = alsf(tid0).v,
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).loc = alsf(tid0).l, pcf(tid0) = R4 → apcf(tid0) = R4,
pcf(tid0) = R3 → apcf(tid0) = R3, pcf(tid0) = R2 → apcf(tid0) = R2, pcf(tid0) = R1 → apcf(tid0) = R1, pcf(tid0) = crashed → apcf(tid0) = crashed,
pcf(tid0) = ready → apcf(tid0) = ready, pcf(tid0) = idle → apcf(tid0) = idle
⊦ |
User applied rule apply rewrite lemma
And obtained the following new goals
- Proof step 124:
⊦ FLITLInv(gs, ls, pc)
↔ (pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7 → notMember(ls.t, gs.freaders))
∧ (pc = W1 ∨ pc = W2 ∨ pc = W7 → notMember(ls.t, gs.fwriters)) ∧ (pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 → oneMember(ls.t, ls.loc, gs.fwriters))
∧ (pc = W1 ∨ pc = W2 → noPendingW(ls.t, gs.bq, gs.pq)) ∧ (pc = W3 ∨ pc = W7 → noPending(ls.t, gs.bq, gs.pq))
∧ (pc = W5 ∨ pc = W6 → FOFollowsW(ls.t, gs.bq(ls.t), gs.pq(ls.loc), ls.loc))
∧ (pc = W1 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W7 → ¬ SF ∈ gs.bq(ls.t)) ∧ (pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7 → gs.rfo(ls.t) = [])
∧ (pc = W3 → gs.bq(ls.t) = []) ∧ (pc = W4 → gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = W(ls.loc, ls.val) ')
∧ (pc = W5 → gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = FO(ls.loc) ' ∨ gs.bq(ls.t) = W(ls.loc, ls.val) ' + FO(ls.loc) ')
∧ (pc = W6 → gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = SF ' ∨ gs.bq(ls.t) = FO(ls.loc) ' + SF ' ∨ gs.bq(ls.t) = W(ls.loc, ls.val) ' + FO(ls.loc) ' + SF ')
∧ (pc = W4 ∨ pc = W5 ∨ pc = W6 → gs.bq(ls.t) ≠ [] ∧ gs.bq(ls.t).head.W? → gs.bq(ls.t).head = W(ls.loc, ls.val))
∧ (pc = W1 ∨ pc = W7 → gs.rfo(ls.t) = gs.bq(ls.t)) ∧ (pc = W2 → gs.rfo(ls.t) = gs.bq(ls.t) ∨ gs.rfo(ls.t) + SF ' = gs.bq(ls.t))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → noPendingW(ls.t, gs.bq, gs.pq))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → notMember(ls.t, gs.fwriters)) ∧ (pc = R1 ∨ pc = R4 → notMember(ls.t, gs.freaders))
∧ (pc = R2 ∨ pc = R3 → oneMember(ls.t, ls.loc, gs.freaders)) ∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → ¬ SF ∈ gs.bq(ls.t))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → gs.rfo(ls.t) = gs.bq(ls.t)) ∧ (pc = idle ∨ pc = ready ∨ pc = crashed → notMember(ls.t, gs.fwriters))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → notMember(ls.t, gs.freaders))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → noPendingW(ls.t, gs.bq, gs.pq)) ∧ (pc = idle ∨ pc = crashed → noPending(ls.t, gs.bq, gs.pq))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → ¬ SF ∈ gs.bq(ls.t)) ∧ (pc = idle ∨ pc = ready ∨ pc = crashed → gs.rfo(ls.t) = gs.bq(ls.t))
- Proof step 125:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, lsf(tid0).t = tid0, alsf(tid0).t = tid0,
gs.bq(tid0) ≠ [], FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)), pcf(tid0) = idle → apcf(tid0) = idle,
pcf(tid0) = ready → apcf(tid0) = ready, pcf(tid0) = crashed → apcf(tid0) = crashed, pcf(tid0) = R1 → apcf(tid0) = R1, pcf(tid0) = R2 → apcf(tid0) = R2,
pcf(tid0) = R3 → apcf(tid0) = R3, pcf(tid0) = R4 → apcf(tid0) = R4,
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).val = alsf(tid0).v, pcf(tid0) = W1 → apcf(tid0) = W1,
pcf(tid0) = W2 → apcf(tid0) = (SF ∈ gs.bq(tid0) ⊃ W1;W2), pcf(tid0) = W3 → apcf(tid0) = W3,
pcf(tid0) = W4 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;W4),
pcf(tid0) = W5 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(tid0) ⊃ W4;W5)),
pcf(tid0) = W6 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(tid0) ⊃ W4;(SF ∈ gs.bq(tid0) ⊃ W5;W6))),
pcf(tid0) = W7 → apcf(tid0) = W7,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).val = alsf(tid0).v,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7
→ notMember(lsf(tid0).t, gs.freaders),
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W7 → notMember(lsf(tid0).t, gs.fwriters),
pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → oneMember(lsf(tid0).t, lsf(tid0).loc, gs.fwriters),
pcf(tid0) = W1 ∨ pcf(tid0) = W2 → noPendingW(lsf(tid0).t, gs.bq, gs.pq), pcf(tid0) = W3 ∨ pcf(tid0) = W7 → noPending(lsf(tid0).t, gs.bq, gs.pq),
pcf(tid0) = W5 ∨ pcf(tid0) = W6 → FOFollowsW(lsf(tid0).t, gs.bq(lsf(tid0).t), gs.pq(lsf(tid0).loc), lsf(tid0).loc),
pcf(tid0) = W1 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W7 → ¬ SF ∈ gs.bq(lsf(tid0).t),
pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → gs.rfo(lsf(tid0).t) = [],
pcf(tid0) = W3 → gs.bq(lsf(tid0).t) = [], pcf(tid0) = W4 → gs.bq(lsf(tid0).t) = [] ∨ gs.bq(lsf(tid0).t) = W(lsf(tid0).loc, lsf(tid0).val) ',
pcf(tid0) = W5
→ gs.bq(lsf(tid0).t) = [] ∨ gs.bq(lsf(tid0).t) = FO(lsf(tid0).loc) ' ∨ gs.bq(lsf(tid0).t) = W(lsf(tid0).loc, lsf(tid0).val) ' + FO(lsf(tid0).loc) ',
pcf(tid0) = W6
→ gs.bq(lsf(tid0).t) = [] ∨ gs.bq(lsf(tid0).t) = SF ' ∨ gs.bq(lsf(tid0).t) = FO(lsf(tid0).loc) ' + SF '
∨ gs.bq(lsf(tid0).t) = W(lsf(tid0).loc, lsf(tid0).val) ' + FO(lsf(tid0).loc) ' + SF ',
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → gs.bq(lsf(tid0).t) ≠ [] ∧ gs.bq(lsf(tid0).t).head.W?
→ gs.bq(lsf(tid0).t).head = W(lsf(tid0).loc, lsf(tid0).val),
pcf(tid0) = W1 ∨ pcf(tid0) = W7 → gs.rfo(lsf(tid0).t) = gs.bq(lsf(tid0).t),
pcf(tid0) = W2 → gs.rfo(lsf(tid0).t) = gs.bq(lsf(tid0).t) ∨ gs.rfo(lsf(tid0).t) + SF ' = gs.bq(lsf(tid0).t),
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → noPendingW(lsf(tid0).t, gs.bq, gs.pq),
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → notMember(lsf(tid0).t, gs.fwriters),
pcf(tid0) = R1 ∨ pcf(tid0) = R4 → notMember(lsf(tid0).t, gs.freaders),
pcf(tid0) = R2 ∨ pcf(tid0) = R3 → oneMember(lsf(tid0).t, lsf(tid0).loc, gs.freaders),
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → ¬ SF ∈ gs.bq(lsf(tid0).t),
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → gs.rfo(lsf(tid0).t) = gs.bq(lsf(tid0).t),
pcf(tid0) = idle ∨ pcf(tid0) = ready ∨ pcf(tid0) = crashed → notMember(lsf(tid0).t, gs.fwriters),
pcf(tid0) = idle ∨ pcf(tid0) = ready ∨ pcf(tid0) = crashed → notMember(lsf(tid0).t, gs.freaders),
pcf(tid0) = idle ∨ pcf(tid0) = ready ∨ pcf(tid0) = crashed → noPendingW(lsf(tid0).t, gs.bq, gs.pq),
pcf(tid0) = idle ∨ pcf(tid0) = crashed → noPending(lsf(tid0).t, gs.bq, gs.pq),
pcf(tid0) = idle ∨ pcf(tid0) = ready ∨ pcf(tid0) = crashed → ¬ SF ∈ gs.bq(lsf(tid0).t),
pcf(tid0) = idle ∨ pcf(tid0) = ready ∨ pcf(tid0) = crashed → gs.rfo(lsf(tid0).t) = gs.bq(lsf(tid0).t)
⊦
Rule argument
spec: FLIT, name:FLITLInv,
seq:⊦ FLITLInv(gs, ls, pc)
↔ ( pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7
→ notMember(ls.t, gs.freaders))
∧ (pc = W1 ∨ pc = W2 ∨ pc = W7 → notMember(ls.t, gs.fwriters))
∧ (pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 → oneMember(ls.t, ls.loc, gs.fwriters))
∧ (pc = W1 ∨ pc = W2 → noPendingW(ls.t, gs.bq, gs.pq))
∧ (pc = W3 ∨ pc = W7 → noPending(ls.t, gs.bq, gs.pq))
∧ (pc = W5 ∨ pc = W6 → FOFollowsW(ls.t, gs.bq(ls.t), gs.pq(ls.loc), ls.loc))
∧ (pc = W1 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W7 → ¬ SF ∈ gs.bq(ls.t))
∧ (pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7 → gs.rfo(ls.t) = [])
∧ (pc = W3 → gs.bq(ls.t) = [])
∧ (pc = W4 → gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = W(ls.loc, ls.val) ')
∧ ( pc = W5
→ gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = FO(ls.loc) '
∨ gs.bq(ls.t) = W(ls.loc, ls.val) ' + FO(ls.loc) ')
∧ ( pc = W6
→ gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = SF ' ∨ gs.bq(ls.t) = FO(ls.loc) ' + SF '
∨ gs.bq(ls.t) = W(ls.loc, ls.val) ' + FO(ls.loc) ' + SF ')
∧ ( pc = W4 ∨ pc = W5 ∨ pc = W6 → gs.bq(ls.t) ≠ [] ∧ gs.bq(ls.t).head.W?
→ gs.bq(ls.t).head = W(ls.loc, ls.val))
∧ (pc = W1 ∨ pc = W7 → gs.rfo(ls.t) = gs.bq(ls.t))
∧ (pc = W2 → gs.rfo(ls.t) = gs.bq(ls.t) ∨ gs.rfo(ls.t) + SF ' = gs.bq(ls.t))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → noPendingW(ls.t, gs.bq, gs.pq))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → notMember(ls.t, gs.fwriters))
∧ (pc = R1 ∨ pc = R4 → notMember(ls.t, gs.freaders))
∧ (pc = R2 ∨ pc = R3 → oneMember(ls.t, ls.loc, gs.freaders))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → ¬ SF ∈ gs.bq(ls.t))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → gs.rfo(ls.t) = gs.bq(ls.t))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → notMember(ls.t, gs.fwriters))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → notMember(ls.t, gs.freaders))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → noPendingW(ls.t, gs.bq, gs.pq))
∧ (pc = idle ∨ pc = crashed → noPending(ls.t, gs.bq, gs.pq))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → ¬ SF ∈ gs.bq(ls.t))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → gs.rfo(ls.t) = gs.bq(ls.t)),
subst:[gs, ls, pc] → [gs, lsf(tid0), pcf(tid0)], <all paths>
Additional information
Used terms: gs, lsf(tid0), pcf(tid0)
Proof step 124 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⊦ FLITLInv(gs, ls, pc)
↔ (pc = W1 ∨ pc = W2 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7 → notMember(ls.t, gs.freaders))
∧ (pc = W1 ∨ pc = W2 ∨ pc = W7 → notMember(ls.t, gs.fwriters)) ∧ (pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 → oneMember(ls.t, ls.loc, gs.fwriters))
∧ (pc = W1 ∨ pc = W2 → noPendingW(ls.t, gs.bq, gs.pq)) ∧ (pc = W3 ∨ pc = W7 → noPending(ls.t, gs.bq, gs.pq))
∧ (pc = W5 ∨ pc = W6 → FOFollowsW(ls.t, gs.bq(ls.t), gs.pq(ls.loc), ls.loc))
∧ (pc = W1 ∨ pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W7 → ¬ SF ∈ gs.bq(ls.t)) ∧ (pc = W3 ∨ pc = W4 ∨ pc = W5 ∨ pc = W6 ∨ pc = W7 → gs.rfo(ls.t) = [])
∧ (pc = W3 → gs.bq(ls.t) = []) ∧ (pc = W4 → gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = W(ls.loc, ls.val) ')
∧ (pc = W5 → gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = FO(ls.loc) ' ∨ gs.bq(ls.t) = W(ls.loc, ls.val) ' + FO(ls.loc) ')
∧ (pc = W6 → gs.bq(ls.t) = [] ∨ gs.bq(ls.t) = SF ' ∨ gs.bq(ls.t) = FO(ls.loc) ' + SF ' ∨ gs.bq(ls.t) = W(ls.loc, ls.val) ' + FO(ls.loc) ' + SF ')
∧ (pc = W4 ∨ pc = W5 ∨ pc = W6 → gs.bq(ls.t) ≠ [] ∧ gs.bq(ls.t).head.W? → gs.bq(ls.t).head = W(ls.loc, ls.val))
∧ (pc = W1 ∨ pc = W7 → gs.rfo(ls.t) = gs.bq(ls.t)) ∧ (pc = W2 → gs.rfo(ls.t) = gs.bq(ls.t) ∨ gs.rfo(ls.t) + SF ' = gs.bq(ls.t))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → noPendingW(ls.t, gs.bq, gs.pq))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → notMember(ls.t, gs.fwriters)) ∧ (pc = R1 ∨ pc = R4 → notMember(ls.t, gs.freaders))
∧ (pc = R2 ∨ pc = R3 → oneMember(ls.t, ls.loc, gs.freaders)) ∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → ¬ SF ∈ gs.bq(ls.t))
∧ (pc = R1 ∨ pc = R2 ∨ pc = R3 ∨ pc = R4 → gs.rfo(ls.t) = gs.bq(ls.t)) ∧ (pc = idle ∨ pc = ready ∨ pc = crashed → notMember(ls.t, gs.fwriters))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → notMember(ls.t, gs.freaders))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → noPendingW(ls.t, gs.bq, gs.pq)) ∧ (pc = idle ∨ pc = crashed → noPending(ls.t, gs.bq, gs.pq))
∧ (pc = idle ∨ pc = ready ∨ pc = crashed → ¬ SF ∈ gs.bq(ls.t)) ∧ (pc = idle ∨ pc = ready ∨ pc = crashed → gs.rfo(ls.t) = gs.bq(ls.t)) |
A spec-lemma
Proof step 125 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, lsf(tid0).t = tid0, alsf(tid0).t = tid0,
gs.bq(tid0) ≠ [], FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0),
¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)), pcf(tid0) = idle → apcf(tid0) = idle,
pcf(tid0) = ready → apcf(tid0) = ready, pcf(tid0) = crashed → apcf(tid0) = crashed, pcf(tid0) = R1 → apcf(tid0) = R1, pcf(tid0) = R2 → apcf(tid0) = R2,
pcf(tid0) = R3 → apcf(tid0) = R3, pcf(tid0) = R4 → apcf(tid0) = R4,
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → lsf(tid0).val = alsf(tid0).v, pcf(tid0) = W1 → apcf(tid0) = W1,
pcf(tid0) = W2 → apcf(tid0) = (SF ∈ gs.bq(tid0) ⊃ W1;W2), pcf(tid0) = W3 → apcf(tid0) = W3,
pcf(tid0) = W4 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;W4),
pcf(tid0) = W5 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(tid0) ⊃ W4;W5)),
pcf(tid0) = W6 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(tid0) ⊃ W4;(SF ∈ gs.bq(tid0) ⊃ W5;W6))),
pcf(tid0) = W7 → apcf(tid0) = W7,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → lsf(tid0).val = alsf(tid0).v,
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7
→ notMember(lsf(tid0).t, gs.freaders),
pcf(tid0) = W1 ∨ pcf(tid0) = W2 ∨ pcf(tid0) = W7 → notMember(lsf(tid0).t, gs.fwriters),
pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → oneMember(lsf(tid0).t, lsf(tid0).loc, gs.fwriters),
pcf(tid0) = W1 ∨ pcf(tid0) = W2 → noPendingW(lsf(tid0).t, gs.bq, gs.pq), pcf(tid0) = W3 ∨ pcf(tid0) = W7 → noPending(lsf(tid0).t, gs.bq, gs.pq),
pcf(tid0) = W5 ∨ pcf(tid0) = W6 → FOFollowsW(lsf(tid0).t, gs.bq(lsf(tid0).t), gs.pq(lsf(tid0).loc), lsf(tid0).loc),
pcf(tid0) = W1 ∨ pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W7 → ¬ SF ∈ gs.bq(lsf(tid0).t),
pcf(tid0) = W3 ∨ pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 ∨ pcf(tid0) = W7 → gs.rfo(lsf(tid0).t) = [],
pcf(tid0) = W3 → gs.bq(lsf(tid0).t) = [], pcf(tid0) = W4 → gs.bq(lsf(tid0).t) = [] ∨ gs.bq(lsf(tid0).t) = W(lsf(tid0).loc, lsf(tid0).val) ',
pcf(tid0) = W5
→ gs.bq(lsf(tid0).t) = [] ∨ gs.bq(lsf(tid0).t) = FO(lsf(tid0).loc) ' ∨ gs.bq(lsf(tid0).t) = W(lsf(tid0).loc, lsf(tid0).val) ' + FO(lsf(tid0).loc) ',
pcf(tid0) = W6
→ gs.bq(lsf(tid0).t) = [] ∨ gs.bq(lsf(tid0).t) = SF ' ∨ gs.bq(lsf(tid0).t) = FO(lsf(tid0).loc) ' + SF '
∨ gs.bq(lsf(tid0).t) = W(lsf(tid0).loc, lsf(tid0).val) ' + FO(lsf(tid0).loc) ' + SF ',
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → gs.bq(lsf(tid0).t) ≠ [] ∧ gs.bq(lsf(tid0).t).head.W?
→ gs.bq(lsf(tid0).t).head = W(lsf(tid0).loc, lsf(tid0).val),
pcf(tid0) = W1 ∨ pcf(tid0) = W7 → gs.rfo(lsf(tid0).t) = gs.bq(lsf(tid0).t),
pcf(tid0) = W2 → gs.rfo(lsf(tid0).t) = gs.bq(lsf(tid0).t) ∨ gs.rfo(lsf(tid0).t) + SF ' = gs.bq(lsf(tid0).t),
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → noPendingW(lsf(tid0).t, gs.bq, gs.pq),
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → notMember(lsf(tid0).t, gs.fwriters),
pcf(tid0) = R1 ∨ pcf(tid0) = R4 → notMember(lsf(tid0).t, gs.freaders),
pcf(tid0) = R2 ∨ pcf(tid0) = R3 → oneMember(lsf(tid0).t, lsf(tid0).loc, gs.freaders),
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → ¬ SF ∈ gs.bq(lsf(tid0).t),
pcf(tid0) = R1 ∨ pcf(tid0) = R2 ∨ pcf(tid0) = R3 ∨ pcf(tid0) = R4 → gs.rfo(lsf(tid0).t) = gs.bq(lsf(tid0).t),
pcf(tid0) = idle ∨ pcf(tid0) = ready ∨ pcf(tid0) = crashed → notMember(lsf(tid0).t, gs.fwriters),
pcf(tid0) = idle ∨ pcf(tid0) = ready ∨ pcf(tid0) = crashed → notMember(lsf(tid0).t, gs.freaders),
pcf(tid0) = idle ∨ pcf(tid0) = ready ∨ pcf(tid0) = crashed → noPendingW(lsf(tid0).t, gs.bq, gs.pq),
pcf(tid0) = idle ∨ pcf(tid0) = crashed → noPending(lsf(tid0).t, gs.bq, gs.pq),
pcf(tid0) = idle ∨ pcf(tid0) = ready ∨ pcf(tid0) = crashed → ¬ SF ∈ gs.bq(lsf(tid0).t),
pcf(tid0) = idle ∨ pcf(tid0) = ready ∨ pcf(tid0) = crashed → gs.rfo(lsf(tid0).t) = gs.bq(lsf(tid0).t)
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 126:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, lsf(tid0).t = tid0, alsf(tid0).t = tid0,
gs.bq(tid0) ≠ [], pcf(tid0) ≠ W1, pcf(tid0) ≠ W2, pcf(tid0) ≠ W3, pcf(tid0) ≠ W7, pcf(tid0) ≠ R1, pcf(tid0) ≠ R2, pcf(tid0) ≠ R3, pcf(tid0) ≠ R4,
pcf(tid0) ≠ idle, pcf(tid0) ≠ ready, pcf(tid0) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0), ¬ noPending(tid0, gs.bq, gs.pq),
¬ noPendingW(tid0, gs.bq, gs.pq), ¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
pcf(tid0) = W4 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;W4),
pcf(tid0) = W5 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(tid0) ⊃ W4;W5)),
pcf(tid0) = W6 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(tid0) ⊃ W4;(SF ∈ gs.bq(tid0) ⊃ W5;W6))),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 → ¬ SF ∈ gs.bq(tid0), pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → gs.rfo(tid0) = [],
pcf(tid0) = W4 → gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ',
pcf(tid0) = W5 → gs.bq(tid0) = FO(lsf(tid0).loc) ' ∨ gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ' + FO(lsf(tid0).loc) ',
pcf(tid0) = W6
→ gs.bq(tid0) = SF ' ∨ gs.bq(tid0) = FO(lsf(tid0).loc) ' + SF ' ∨ gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ' + FO(lsf(tid0).loc) ' + SF ',
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → gs.bq(tid0).head.W? → gs.bq(tid0).head = W(lsf(tid0).loc, lsf(tid0).val),
pcf(tid0) = W5 ∨ pcf(tid0) = W6 → FOFollowsW(tid0, gs.bq(tid0), gs.pq(lsf(tid0).loc), lsf(tid0).loc),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → lsf(tid0).val = alsf(tid0).v,
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → notMember(tid0, gs.freaders),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → oneMember(tid0, lsf(tid0).loc, gs.fwriters)
⊦
Rule argument
Additional information
Used simplifier rules:
a: ⊦ (x + y) + z = x + y + z; from specification list
⊦ noPending(t, bq, pq) → bq(t) ≠ W(l, v) ' + bel; (as)
⊦ noPendingW(t, bq, pq) → bq(t) ≠ W(l, v) ' + bel; (as)
Proof step 126 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, lsf(tid0).t = tid0, alsf(tid0).t = tid0,
gs.bq(tid0) ≠ [], pcf(tid0) ≠ W1, pcf(tid0) ≠ W2, pcf(tid0) ≠ W3, pcf(tid0) ≠ W7, pcf(tid0) ≠ R1, pcf(tid0) ≠ R2, pcf(tid0) ≠ R3, pcf(tid0) ≠ R4,
pcf(tid0) ≠ idle, pcf(tid0) ≠ ready, pcf(tid0) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0), ¬ noPending(tid0, gs.bq, gs.pq),
¬ noPendingW(tid0, gs.bq, gs.pq), ¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
pcf(tid0) = W4 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;W4),
pcf(tid0) = W5 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(tid0) ⊃ W4;W5)),
pcf(tid0) = W6 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(tid0) ⊃ W4;(SF ∈ gs.bq(tid0) ⊃ W5;W6))),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 → ¬ SF ∈ gs.bq(tid0), pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → gs.rfo(tid0) = [],
pcf(tid0) = W4 → gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ',
pcf(tid0) = W5 → gs.bq(tid0) = FO(lsf(tid0).loc) ' ∨ gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ' + FO(lsf(tid0).loc) ',
pcf(tid0) = W6
→ gs.bq(tid0) = SF ' ∨ gs.bq(tid0) = FO(lsf(tid0).loc) ' + SF ' ∨ gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ' + FO(lsf(tid0).loc) ' + SF ',
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → gs.bq(tid0).head.W? → gs.bq(tid0).head = W(lsf(tid0).loc, lsf(tid0).val),
pcf(tid0) = W5 ∨ pcf(tid0) = W6 → FOFollowsW(tid0, gs.bq(tid0), gs.pq(lsf(tid0).loc), lsf(tid0).loc),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → lsf(tid0).val = alsf(tid0).v,
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → notMember(tid0, gs.freaders),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → oneMember(tid0, lsf(tid0).loc, gs.fwriters)
⊦ |
Heuristic elimination applied rule apply elim lemma
And obtained the following new goals
- Proof step 127:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, gs.bq(tid0) = head + bel0, ags.ctr = gs.fctr, ags.mem = gs.pmem, alsf(tid0).t = tid0,
lsf(tid0).t = tid0, gs.bq(tid0) ≠ [], pcf(tid0) ≠ W1, pcf(tid0) ≠ W2, pcf(tid0) ≠ W3, pcf(tid0) ≠ W7, pcf(tid0) ≠ R1, pcf(tid0) ≠ R2, pcf(tid0) ≠ R3,
pcf(tid0) ≠ R4, pcf(tid0) ≠ idle, pcf(tid0) ≠ ready, pcf(tid0) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0), ¬ noPending(tid0, gs.bq, gs.pq),
¬ noPendingW(tid0, gs.bq, gs.pq), ¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → oneMember(tid0, lsf(tid0).loc, gs.fwriters),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → notMember(tid0, gs.freaders),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → lsf(tid0).val = alsf(tid0).v,
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = W5 ∨ pcf(tid0) = W6 → FOFollowsW(tid0, gs.bq(tid0), gs.pq(lsf(tid0).loc), lsf(tid0).loc),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → head.W? → head = W(lsf(tid0).loc, lsf(tid0).val),
pcf(tid0) = W6
→ gs.bq(tid0) = SF ' ∨ gs.bq(tid0) = FO(lsf(tid0).loc) ' + SF ' ∨ gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ' + FO(lsf(tid0).loc) ' + SF ',
pcf(tid0) = W5 → gs.bq(tid0) = FO(lsf(tid0).loc) ' ∨ gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ' + FO(lsf(tid0).loc) ',
pcf(tid0) = W4 → gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ', pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → gs.rfo(tid0) = [],
pcf(tid0) = W4 ∨ pcf(tid0) = W5 → ¬ SF ∈ gs.bq(tid0),
pcf(tid0) = W6 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(tid0) ⊃ W4;(SF ∈ gs.bq(tid0) ⊃ W5;W6))),
pcf(tid0) = W5 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(tid0) ⊃ W4;W5)),
pcf(tid0) = W4 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;W4)
⊦
Rule argument
spec: list-data, name:elim-add,
seq: ⊦ x ≠ [] → (head = x.head ∧ tail = x.tail ↔ x = head + tail),
subst:[x, head, tail] → [gs.bq(tid0), head, bel0]; ['a] → [Bevent]
Additional information
Used simplifier rules:
⊦ x ≠ [] → (head = x.head ∧ tail = x.tail ↔ x = head + tail); (elim)
Used terms: gs.bq(tid0), head, bel0
Proof step 127 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, gs.bq(tid0) = head + bel0, ags.ctr = gs.fctr, ags.mem = gs.pmem, alsf(tid0).t = tid0,
lsf(tid0).t = tid0, gs.bq(tid0) ≠ [], pcf(tid0) ≠ W1, pcf(tid0) ≠ W2, pcf(tid0) ≠ W3, pcf(tid0) ≠ W7, pcf(tid0) ≠ R1, pcf(tid0) ≠ R2, pcf(tid0) ≠ R3,
pcf(tid0) ≠ R4, pcf(tid0) ≠ idle, pcf(tid0) ≠ ready, pcf(tid0) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), W(bq(tid0).head.l, bq(tid0).head.v) ∈ gs.bq(tid0), ¬ noPending(tid0, gs.bq, gs.pq),
¬ noPendingW(tid0, gs.bq, gs.pq), ¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → oneMember(tid0, lsf(tid0).loc, gs.fwriters),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → notMember(tid0, gs.freaders),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → lsf(tid0).val = alsf(tid0).v,
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = W5 ∨ pcf(tid0) = W6 → FOFollowsW(tid0, gs.bq(tid0), gs.pq(lsf(tid0).loc), lsf(tid0).loc),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → head.W? → head = W(lsf(tid0).loc, lsf(tid0).val),
pcf(tid0) = W6
→ gs.bq(tid0) = SF ' ∨ gs.bq(tid0) = FO(lsf(tid0).loc) ' + SF ' ∨ gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ' + FO(lsf(tid0).loc) ' + SF ',
pcf(tid0) = W5 → gs.bq(tid0) = FO(lsf(tid0).loc) ' ∨ gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ' + FO(lsf(tid0).loc) ',
pcf(tid0) = W4 → gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ', pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → gs.rfo(tid0) = [],
pcf(tid0) = W4 ∨ pcf(tid0) = W5 → ¬ SF ∈ gs.bq(tid0),
pcf(tid0) = W6 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(tid0) ⊃ W4;(SF ∈ gs.bq(tid0) ⊃ W5;W6))),
pcf(tid0) = W5 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;(FO(lsf(tid0).loc) ∈ gs.bq(tid0) ⊃ W4;W5)),
pcf(tid0) = W4 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) ∈ gs.bq(tid0) ⊃ W3;W4)
⊦ |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 128:
gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, lsf(tid0).t = tid0, alsf(tid0).t = tid0,
pcf(tid0) ≠ W1, pcf(tid0) ≠ W2, pcf(tid0) ≠ W3, pcf(tid0) ≠ W7, pcf(tid0) ≠ R1, pcf(tid0) ≠ R2, pcf(tid0) ≠ R3, pcf(tid0) ≠ R4, pcf(tid0) ≠ idle,
pcf(tid0) ≠ ready, pcf(tid0) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ¬ noPending(tid0, gs.bq, gs.pq), ¬ noPendingW(tid0, gs.bq, gs.pq),
¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
pcf(tid0) = W4 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) = W(bq(tid0).head.l, bq(tid0).head.v) ∨ W(lsf(tid0).loc, lsf(tid0).val) ∈ bel ⊃ W3;W4),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → gs.rfo(tid0) = [], pcf(tid0) = W4 → gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ',
pcf(tid0) = W5 → gs.bq(tid0) = FO(lsf(tid0).loc) ' ∨ gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ' + FO(lsf(tid0).loc) ',
pcf(tid0) = W6
→ gs.bq(tid0) = SF ' ∨ gs.bq(tid0) = FO(lsf(tid0).loc) ' + SF ' ∨ gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ' + FO(lsf(tid0).loc) ' + SF ',
pcf(tid0) = W5 ∨ pcf(tid0) = W6 → FOFollowsW(tid0, gs.bq(tid0), gs.pq(lsf(tid0).loc), lsf(tid0).loc),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → lsf(tid0).val = alsf(tid0).v,
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → notMember(tid0, gs.freaders),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → oneMember(tid0, lsf(tid0).loc, gs.fwriters),
pcf(tid0) = W5
→ apcf(tid0)
= (W(lsf(tid0).loc, lsf(tid0).val) = W(bq(tid0).head.l, bq(tid0).head.v) ∨ W(lsf(tid0).loc, lsf(tid0).val) ∈ bel
⊃ W3
;(FO(lsf(tid0).loc) ∈ bel ⊃ W4;W5)
),
pcf(tid0) = W6
→ apcf(tid0)
= (W(lsf(tid0).loc, lsf(tid0).val) = W(bq(tid0).head.l, bq(tid0).head.v) ∨ W(lsf(tid0).loc, lsf(tid0).val) ∈ bel
⊃ W3
;(FO(lsf(tid0).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 → ¬ SF ∈ bel,
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → W(bq(tid0).head.l, bq(tid0).head.v) = W(lsf(tid0).loc, lsf(tid0).val)
⊦
Rule argument
Additional information
Used simplifier rules:
⊦ W(l, v).W?; (s)
⊦ W(l, v) ≠ SF; (s)
⊦ W(l, v) ≠ FO(l0); (s)
a: ⊦ (x + y) + z = x + y + z; from specification list
⊦ a ∈ a0 ' + x ↔ a = a0 ∨ a ∈ x; (s)
⊦ a ' ≠ []; (s)
⊦ x + y = [] ↔ x = [] ∧ y = []; (s)
⊦ a ' + x = a0 ' + y ↔ a = a0 ∧ x = y; (ws)
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
⊦ a + x = a ' + x; (s)
Proof step 128 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| gs.bq(tid0) = W(bq(tid0).head.l, bq(tid0).head.v) ' + bel, ags.ctr = gs.fctr, ags.mem = gs.pmem, lsf(tid0).t = tid0, alsf(tid0).t = tid0,
pcf(tid0) ≠ W1, pcf(tid0) ≠ W2, pcf(tid0) ≠ W3, pcf(tid0) ≠ W7, pcf(tid0) ≠ R1, pcf(tid0) ≠ R2, pcf(tid0) ≠ R3, pcf(tid0) ≠ R4, pcf(tid0) ≠ idle,
pcf(tid0) ≠ ready, pcf(tid0) ≠ crashed, FLITGInv(gs),
FLITInv((gs.pq:= gs.pq(bq(tid0).head.l := gs.pq(bq(tid0).head.l) + W(bq(tid0).head.v, tid0) ')).bq:= gs.bq(tid0 := bel), lsf, pcf),
FLITPSCInv(ags, alsf, apcf), reorder(ags.p, gs.pq, gs.rfo), ¬ noPending(tid0, gs.bq, gs.pq), ¬ noPendingW(tid0, gs.bq, gs.pq),
¬ pre(ags, alsf(tid0), apcf(tid0), doWritePSC(tid0, bq(tid0).head.l, bq(tid0).head.v)),
pcf(tid0) = W4 → apcf(tid0) = (W(lsf(tid0).loc, lsf(tid0).val) = W(bq(tid0).head.l, bq(tid0).head.v) ∨ W(lsf(tid0).loc, lsf(tid0).val) ∈ bel ⊃ W3;W4),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → gs.rfo(tid0) = [], pcf(tid0) = W4 → gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ',
pcf(tid0) = W5 → gs.bq(tid0) = FO(lsf(tid0).loc) ' ∨ gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ' + FO(lsf(tid0).loc) ',
pcf(tid0) = W6
→ gs.bq(tid0) = SF ' ∨ gs.bq(tid0) = FO(lsf(tid0).loc) ' + SF ' ∨ gs.bq(tid0) = W(lsf(tid0).loc, lsf(tid0).val) ' + FO(lsf(tid0).loc) ' + SF ',
pcf(tid0) = W5 ∨ pcf(tid0) = W6 → FOFollowsW(tid0, gs.bq(tid0), gs.pq(lsf(tid0).loc), lsf(tid0).loc),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → lsf(tid0).loc = alsf(tid0).l,
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → lsf(tid0).val = alsf(tid0).v,
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → notMember(tid0, gs.freaders),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → oneMember(tid0, lsf(tid0).loc, gs.fwriters),
pcf(tid0) = W5
→ apcf(tid0)
= (W(lsf(tid0).loc, lsf(tid0).val) = W(bq(tid0).head.l, bq(tid0).head.v) ∨ W(lsf(tid0).loc, lsf(tid0).val) ∈ bel
⊃ W3
;(FO(lsf(tid0).loc) ∈ bel ⊃ W4;W5)
),
pcf(tid0) = W6
→ apcf(tid0)
= (W(lsf(tid0).loc, lsf(tid0).val) = W(bq(tid0).head.l, bq(tid0).head.v) ∨ W(lsf(tid0).loc, lsf(tid0).val) ∈ bel
⊃ W3
;(FO(lsf(tid0).loc) ∈ bel ⊃ W4;(SF ∈ bel ⊃ W5;W6))
),
pcf(tid0) = W4 ∨ pcf(tid0) = W5 → ¬ SF ∈ bel,
pcf(tid0) = W4 ∨ pcf(tid0) = W5 ∨ pcf(tid0) = W6 → W(bq(tid0).head.l, bq(tid0).head.v) = W(lsf(tid0).loc, lsf(tid0).val)
⊦ |
User applied rule constructor cut
And closed the goal!
Rule argument
term: pcf(tid0)
Additional information
Used simplifier rules:
FLITPC
freely generated by R1, R2, R3, R4, W1, W2, W3, W4, W5, W6, W7, crashed, idle, ready
;;
⊦ W(l, v) = W(l0, v0) ↔ l = l0 ∧ v = v0; (ws)
in-14: ⊦ a ' + x = y → a ∈ y; (forward) from specification list
a: ⊦ (x + y) + z = x + y + z; from specification list
⊦ W6 ≠ crashed; (s)
⊦ W6 ≠ ready; (s)
⊦ W6 ≠ idle; (s)
⊦ R4 ≠ W6; (s)
⊦ R3 ≠ W6; (s)
⊦ R2 ≠ W6; (s)
⊦ R1 ≠ W6; (s)
⊦ W6 ≠ W7; (s)
⊦ W3 ≠ W6; (s)
⊦ W2 ≠ W6; (s)
⊦ W1 ≠ W6; (s)
⊦ pre(gs, ls, W3, a) ↔ a = doWritePSC(ls.t, ls.l, ls.v); (s)
⊦ doWritePSC(t, l, v) = doWritePSC(t0, l0, v0) ↔ t = t0 ∧ l = l0 ∧ v = v0; (ws)
⊦ W5 ≠ crashed; (s)
⊦ W5 ≠ ready; (s)
⊦ W5 ≠ idle; (s)
⊦ R4 ≠ W5; (s)
⊦ R3 ≠ W5; (s)
⊦ R2 ≠ W5; (s)
⊦ R1 ≠ W5; (s)
⊦ W5 ≠ W7; (s)
⊦ W3 ≠ W5; (s)
⊦ W2 ≠ W5; (s)
⊦ W1 ≠ W5; (s)
⊦ x = x + y ↔ y = []; (s)
⊦ W4 ≠ crashed; (s)
⊦ W4 ≠ ready; (s)
⊦ W4 ≠ idle; (s)
⊦ R4 ≠ W4; (s)
⊦ R3 ≠ W4; (s)
⊦ R2 ≠ W4; (s)
⊦ R1 ≠ W4; (s)
⊦ W4 ≠ W7; (s)
⊦ W3 ≠ W4; (s)
⊦ W2 ≠ W4; (s)
⊦ W1 ≠ W4; (s)
Proof step 129 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⟨fwriters := gs.fwriters, pq := gs.pq, bq := gs.bq, rfo := gs.rfo; PROP_FO(tid1, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩
(gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
doWrite(tid, bq(tid).head.l, bq(tid).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), n < # gs.bq(tid1),
FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq(tid).head.l, bq(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t))) |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 130:
⟨PROP_FO(tid1, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
doWrite(tid, bq0(tid).head.l, bq0(tid).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, n < # gs.bq(tid1), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t)))
Rule argument
Additional information
Proof step 130 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⟨PROP_FO(tid1, l, fwriters; pq, bq, rfo); gs := ((gs.pq:= pq).bq:= bq).rfo:= rfo⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
doWrite(tid, bq0(tid).head.l, bq0(tid).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, n < # gs.bq(tid1), FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t))) |
Heuristic split applied rule split left
And obtained the following new goals
- Proof step 131:
⟨gs := ((gs.pq:= pq0).bq:= bq1).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
⟨PROP_FO(tid1, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq1 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, doWrite(tid, bq0(tid).head.l, bq0(tid).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)),
fwriters = gs.fwriters, pq = gs.pq, rfo = gs.rfo, n < # gs.bq(tid1), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t)))
Rule argument
pos: left 1
Additional information
Proof step 131 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⟨gs := ((gs.pq:= pq0).bq:= bq1).rfo:= rfo0⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf),
⟨PROP_FO(tid1, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq1 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, doWrite(tid, bq0(tid).head.l, bq0(tid).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)),
fwriters = gs.fwriters, pq = gs.pq, rfo = gs.rfo, n < # gs.bq(tid1), FLITInv(gs0, lsf0, pcf0), FLITInv(gs, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t))) |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 132:
⟨PROP_FO(tid1, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq1 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, doWrite(tid, bq0(tid).head.l, bq0(tid).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)),
fwriters = gs.fwriters, gs0 = ((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf0 = lsf, pcf0 = pcf, pq = gs.pq, rfo = gs.rfo, n < # gs.bq(tid1),
FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t)))
Rule argument
Additional information
Proof step 132 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⟨PROP_FO(tid1, l, fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq1 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, doWrite(tid, bq0(tid).head.l, bq0(tid).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)),
fwriters = gs.fwriters, gs0 = ((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf0 = lsf, pcf0 = pcf, pq = gs.pq, rfo = gs.rfo, n < # gs.bq(tid1),
FLITInv(gs, lsf, pcf), FLITInv(gs0, lsf0, pcf0), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))))
∧ ags0.mem = gs0.pmem ∧ ags0.ctr = gs0.fctr ∧ reorder(ags0.p, gs0.pq, gs0.rfo) ∧ ags0.writers = gs0.fwriters
∧ (∀ t. labs(gs0, lsf0(t), pcf0(t), ags0, alsf0(t), apcf0(t))) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 133:
⟨PROP_FO(tid1, l, gs.fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq1 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, doWrite(tid, bq0(tid).head.l, bq0(tid).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), pq = gs.pq,
rfo = gs.rfo, gs.bq(tid1) ≠ [], n < # gs.bq(tid1), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, pq0, rfo0) ∧ ags0.writers = gs.fwriters
∧ (∀ t. labs(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf(t), pcf(t), ags0, alsf0(t), apcf0(t)))
Rule argument
Additional information
Used simplifier rules:
⊦ # x = 0 ↔ x = []; (s)
f: ⊦ m < n → n ≠ 0; (forward) from specification nat-basic
⊦ (gs.pq:= pq).fwriters = gs.fwriters; (s)
⊦ (gs.bq:= bq).fwriters = gs.fwriters; (s)
⊦ (gs.rfo:= bq0).fwriters = gs.fwriters; (s)
⊦ (gs.rfo:= bq0).rfo = bq0; (s)
⊦ (gs.pq:= pq).pq = pq; (s)
⊦ (gs.bq:= bq).pq = gs.pq; (s)
⊦ (gs.rfo:= bq0).pq = gs.pq; (s)
⊦ (gs.pq:= pq).fctr = gs.fctr; (s)
⊦ (gs.bq:= bq).fctr = gs.fctr; (s)
⊦ (gs.rfo:= bq0).fctr = gs.fctr; (s)
⊦ (gs.pq:= pq).pmem = gs.pmem; (s)
⊦ (gs.bq:= bq).pmem = gs.pmem; (s)
⊦ (gs.rfo:= bq0).pmem = gs.pmem; (s)
Proof step 133 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⟨PROP_FO(tid1, l, gs.fwriters; pq, bq, rfo)⟩ (pq = pq0 ∧ bq = bq1 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
bq = gs.bq, doWrite(tid, bq0(tid).head.l, bq0(tid).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), pq = gs.pq,
rfo = gs.rfo, gs.bq(tid1) ≠ [], n < # gs.bq(tid1), FLITInv(gs, lsf, pcf), FLITInv(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid, bq0(tid).head.l, bq0(tid).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, pq0, rfo0) ∧ ags0.writers = gs.fwriters
∧ (∀ t. labs(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf(t), pcf(t), ags0, alsf0(t), apcf0(t))) |
Heuristic unfold applied rule call left
And obtained the following new goals
- Proof step 134:
⟨choose n
with n < # bq(tid) ∧ isPropFO(n, l, bq(tid))
in pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)
ifnone skip⟩ (pq = pq0 ∧ bq = bq1 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
doWrite(tid0, bq0(tid0).head.l, bq0(tid0).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, tid = tid1, gs.bq(tid1) ≠ [], n < # gs.bq(tid1), FLITInv(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, pq0, rfo0) ∧ ags0.writers = gs.fwriters
∧ (∀ t. labs(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf(t), pcf(t), ags0, alsf0(t), apcf0(t)))
Rule argument
pos: left 1
Additional information
Used simplifier rules:
decl: PROP_FO(tid, l, fwriters; pq, bq, rfo)
{choose n
with n < # bq(tid) ∧ isPropFO(n, l, bq(tid))
in pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n,
rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)
ifnone skip
};
Proof step 134 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⟨choose n
with n < # bq(tid) ∧ isPropFO(n, l, bq(tid))
in pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)
ifnone skip⟩ (pq = pq0 ∧ bq = bq1 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
doWrite(tid0, bq0(tid0).head.l, bq0(tid0).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, tid = tid1, gs.bq(tid1) ≠ [], n < # gs.bq(tid1), FLITInv(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, pq0, rfo0) ∧ ags0.writers = gs.fwriters
∧ (∀ t. labs(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf(t), pcf(t), ags0, alsf0(t), apcf0(t))) |
Heuristic symbolic execution applied rule choose left
And obtained the following new goals
- Proof step 135:
⟨pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)⟩ (pq = pq0 ∧ bq = bq1 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
doWrite(tid0, bq0(tid0).head.l, bq0(tid0).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, tid = tid1, gs.bq(tid1) ≠ [], n0 < # gs.bq(tid1), n < # bq(tid), FLITInv(gs, lsf, pcf),
FLITInv(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(tid1)), isPropFO(n, l, bq(tid)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, pq0, rfo0) ∧ ags0.writers = gs.fwriters
∧ (∀ t. labs(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf(t), pcf(t), ags0, alsf0(t), apcf0(t)))
- Proof step 140:
⟨skip⟩ (pq = pq0 ∧ bq = bq1 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
doWrite(tid0, bq0(tid0).head.l, bq0(tid0).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, tid = tid1, gs.bq(tid1) ≠ [], n < # gs.bq(tid1), FLITInv(gs, lsf, pcf),
FLITInv(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid)))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, pq0, rfo0) ∧ ags0.writers = gs.fwriters
∧ (∀ t. labs(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf(t), pcf(t), ags0, alsf0(t), apcf0(t)))
Rule argument
Additional information
Proof step 135 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⟨pq(l) := pq(l) + FO(tid), bq(tid) := bq(tid) -p n, rfo(tid) := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)⟩ (pq = pq0 ∧ bq = bq1 ∧ rfo = rfo0),
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
doWrite(tid0, bq0(tid0).head.l, bq0(tid0).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, tid = tid1, gs.bq(tid1) ≠ [], n0 < # gs.bq(tid1), n < # bq(tid), FLITInv(gs, lsf, pcf),
FLITInv(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(tid1)), isPropFO(n, l, bq(tid)),
reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, pq0, rfo0) ∧ ags0.writers = gs.fwriters
∧ (∀ t. labs(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf(t), pcf(t), ags0, alsf0(t), apcf0(t))) |
Heuristic symbolic execution applied rule assign left
And obtained the following new goals
- Proof step 136:
pq(l := pq(l) + FO(tid)) = pq0, bq(tid := bq(tid) -p n) = bq1, rfo(tid := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)) = rfo0, ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
doWrite(tid0, bq0(tid0).head.l, bq0(tid0).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, tid = tid1, gs.bq(tid1) ≠ [], n < # bq(tid), n0 < # gs.bq(tid1),
FLITInv(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, bq(tid)),
isPropFO(n0, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, pq0, rfo0) ∧ ags0.writers = gs.fwriters
∧ (∀ t. labs(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf(t), pcf(t), ags0, alsf0(t), apcf0(t)))
Rule argument
Additional information
Proof step 136 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| pq(l := pq(l) + FO(tid)) = pq0, bq(tid := bq(tid) -p n) = bq1, rfo(tid := (tid ∈ fwriters(l) ⊃ rfo(tid);rfo(tid) -p n)) = rfo0, ags.ctr = gs.fctr,
ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
doWrite(tid0, bq0(tid0).head.l, bq0(tid0).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, tid = tid1, gs.bq(tid1) ≠ [], n < # bq(tid), n0 < # gs.bq(tid1),
FLITInv(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, bq(tid)),
isPropFO(n0, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, pq0, rfo0) ∧ ags0.writers = gs.fwriters
∧ (∀ t. labs(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf(t), pcf(t), ags0, alsf0(t), apcf0(t))) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 137:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
doWrite(tid0, bq0(tid0).head.l, bq0(tid0).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), gs.bq(tid1) ≠ [],
n0 < # gs.bq(tid1), n < # gs.bq(tid1), FLITInv(gs, lsf, pcf),
FLITInv
( ((gs.pq:= gs.pq(l := gs.pq(l) + FO(tid1) ')).bq:= gs.bq(tid1 := gs.bq(tid1) -p n))
.rfo:= gs.rfo(tid1 := (tid1 ∈ gs.fwriters(l) ⊃ gs.rfo(tid1);gs.rfo(tid1) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(tid1)), isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr
∧ reorder(ags0.p, gs.pq(l := gs.pq(l) + FO(tid1) '), gs.rfo(tid1 := (tid1 ∈ gs.fwriters(l) ⊃ gs.rfo(tid1);gs.rfo(tid1) -p n)))
∧ ags0.writers = gs.fwriters
∧ (∀ t.
labs
( ((gs.pq:= gs.pq(l := gs.pq(l) + FO(tid1) ')).bq:= gs.bq(tid1 := gs.bq(tid1) -p n))
.rfo:= gs.rfo(tid1 := (tid1 ∈ gs.fwriters(l) ⊃ gs.rfo(tid1);gs.rfo(tid1) -p n)),
lsf(t), pcf(t), ags0, alsf0(t), apcf0(t)))
Rule argument
Additional information
Used simplifier rules:
⊦ x + a = x + a '; (s)
Proof step 137 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
doWrite(tid0, bq0(tid0).head.l, bq0(tid0).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), gs.bq(tid1) ≠ [],
n0 < # gs.bq(tid1), n < # gs.bq(tid1), FLITInv(gs, lsf, pcf),
FLITInv
( ((gs.pq:= gs.pq(l := gs.pq(l) + FO(tid1) ')).bq:= gs.bq(tid1 := gs.bq(tid1) -p n))
.rfo:= gs.rfo(tid1 := (tid1 ∈ gs.fwriters(l) ⊃ gs.rfo(tid1);gs.rfo(tid1) -p n)),
lsf, pcf),
FLITPSCInv(ags, alsf, apcf), isPropFO(n0, l, gs.bq(tid1)), isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr
∧ reorder(ags0.p, gs.pq(l := gs.pq(l) + FO(tid1) '), gs.rfo(tid1 := (tid1 ∈ gs.fwriters(l) ⊃ gs.rfo(tid1);gs.rfo(tid1) -p n)))
∧ ags0.writers = gs.fwriters
∧ (∀ t.
labs
( ((gs.pq:= gs.pq(l := gs.pq(l) + FO(tid1) ')).bq:= gs.bq(tid1 := gs.bq(tid1) -p n))
.rfo:= gs.rfo(tid1 := (tid1 ∈ gs.fwriters(l) ⊃ gs.rfo(tid1);gs.rfo(tid1) -p n)),
lsf(t), pcf(t), ags0, alsf0(t), apcf0(t))) |
Heuristic nonsplitting cut applied rule cut formula
And obtained the following new goals
- Proof step 138:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
doWrite(tid0, bq0(tid0).head.l, bq0(tid0).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), gs.bq(tid1) ≠ [],
n < # gs.bq(tid1), n0 < # gs.bq(tid1),
FLITInv
( ((gs.pq:= gs.pq(l := gs.pq(l) + FO(tid1) ')).bq:= gs.bq(tid1 := gs.bq(tid1) -p n))
.rfo:= gs.rfo(tid1 := (tid1 ∈ gs.fwriters(l) ⊃ gs.rfo(tid1);gs.rfo(tid1) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(tid1)), isPropFO(n0, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo),
tid1 ∈ gs.fwriters(l), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr
∧ reorder(ags0.p, gs.pq(l := gs.pq(l) + FO(tid1) '), gs.rfo(tid1 := (tid1 ∈ gs.fwriters(l) ⊃ gs.rfo(tid1);gs.rfo(tid1) -p n)))
∧ ags0.writers = gs.fwriters
∧ (∀ t.
labs
( ((gs.pq:= gs.pq(l := gs.pq(l) + FO(tid1) ')).bq:= gs.bq(tid1 := gs.bq(tid1) -p n))
.rfo:= gs.rfo(tid1 := (tid1 ∈ gs.fwriters(l) ⊃ gs.rfo(tid1);gs.rfo(tid1) -p n)),
lsf(t), pcf(t), ags0, alsf0(t), apcf0(t)))
Rule argument
fma: tid1 ∈ gs.fwriters(l)
Additional information
Used simplifier rules:
⊦ oneMember(t, l, tsf) → (t ∈ tsf(l0) ↔ l = l0); (s)
⊦ doWrite(t, loc, v) ≠ propFO(t0, loc0); (s)
Used formulas: tid1 ∈ gs.fwriters(l)
Proof step 138 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
doWrite(tid0, bq0(tid0).head.l, bq0(tid0).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), gs.bq(tid1) ≠ [],
n < # gs.bq(tid1), n0 < # gs.bq(tid1),
FLITInv
( ((gs.pq:= gs.pq(l := gs.pq(l) + FO(tid1) ')).bq:= gs.bq(tid1 := gs.bq(tid1) -p n))
.rfo:= gs.rfo(tid1 := (tid1 ∈ gs.fwriters(l) ⊃ gs.rfo(tid1);gs.rfo(tid1) -p n)),
lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(tid1)), isPropFO(n0, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo),
tid1 ∈ gs.fwriters(l), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr
∧ reorder(ags0.p, gs.pq(l := gs.pq(l) + FO(tid1) '), gs.rfo(tid1 := (tid1 ∈ gs.fwriters(l) ⊃ gs.rfo(tid1);gs.rfo(tid1) -p n)))
∧ ags0.writers = gs.fwriters
∧ (∀ t.
labs
( ((gs.pq:= gs.pq(l := gs.pq(l) + FO(tid1) ')).bq:= gs.bq(tid1 := gs.bq(tid1) -p n))
.rfo:= gs.rfo(tid1 := (tid1 ∈ gs.fwriters(l) ⊃ gs.rfo(tid1);gs.rfo(tid1) -p n)),
lsf(t), pcf(t), ags0, alsf0(t), apcf0(t))) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 139:
ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
doWrite(tid0, bq0(tid0).head.l, bq0(tid0).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), # gs.fwriters(l) ≠ 0,
gs.bq(tid1) ≠ [], gs.fwriters(l) ≠ ∅, n < # gs.bq(tid1), n0 < # gs.bq(tid1),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(tid1) ')).bq:= gs.bq(tid1 := gs.bq(tid1) -p n)).rfo:= gs.rfo(tid1 := gs.rfo(tid1)), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(tid1)), isPropFO(n0, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo),
tid1 ∈ gs.fwriters(l), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, gs.pq(l := gs.pq(l) + FO(tid1) '), gs.rfo(tid1 := gs.rfo(tid1)))
∧ ags0.writers = gs.fwriters
∧ (∀ t.
labs
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(tid1) ')).bq:= gs.bq(tid1 := gs.bq(tid1) -p n)).rfo:= gs.rfo(tid1 := gs.rfo(tid1)), lsf(t), pcf(t), ags0,
alsf0(t), apcf0(t)))
Rule argument
Additional information
Used simplifier rules:
size-zero-01: ⊦ s ≠ ∅ → # s ≠ 0; (forward) from specification set-basic
ne-01: ⊦ a ∈ s → s ≠ ∅; (forward) from specification set-basic
Proof step 139 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters,
doWrite(tid0, bq0(tid0).head.l, bq0(tid0).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), # gs.fwriters(l) ≠ 0,
gs.bq(tid1) ≠ [], gs.fwriters(l) ≠ ∅, n < # gs.bq(tid1), n0 < # gs.bq(tid1),
FLITInv(((gs.pq:= gs.pq(l := gs.pq(l) + FO(tid1) ')).bq:= gs.bq(tid1 := gs.bq(tid1) -p n)).rfo:= gs.rfo(tid1 := gs.rfo(tid1)), lsf, pcf),
FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(tid1)), isPropFO(n0, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo),
tid1 ∈ gs.fwriters(l), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, gs.pq(l := gs.pq(l) + FO(tid1) '), gs.rfo(tid1 := gs.rfo(tid1)))
∧ ags0.writers = gs.fwriters
∧ (∀ t.
labs
(((gs.pq:= gs.pq(l := gs.pq(l) + FO(tid1) ')).bq:= gs.bq(tid1 := gs.bq(tid1) -p n)).rfo:= gs.rfo(tid1 := gs.rfo(tid1)), lsf(t), pcf(t), ags0,
alsf0(t), apcf0(t))) |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(tid1, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ doWrite(t, loc, v) ≠ propFO(t0, loc0); (s)
⊦ doWrite(t, loc, v) ≠ doWriteFO(t0, loc0); (s)
Used formulas: oneMember(tid1, l, gs.fwriters)
Proof step 140 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⟨skip⟩ (pq = pq0 ∧ bq = bq1 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
doWrite(tid0, bq0(tid0).head.l, bq0(tid0).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), fwriters = gs.fwriters,
pq = gs.pq, rfo = gs.rfo, tid = tid1, gs.bq(tid1) ≠ [], n < # gs.bq(tid1), FLITInv(gs, lsf, pcf),
FLITInv(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf, pcf), FLITPSCInv(ags, alsf, apcf), isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo),
∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)), ∀ n. ¬(n < # bq(tid) ∧ isPropFO(n, l, bq(tid)))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, pq0, rfo0) ∧ ags0.writers = gs.fwriters
∧ (∀ t. labs(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf(t), pcf(t), ags0, alsf0(t), apcf0(t))) |
Heuristic simplifier applied rule simplifier
And obtained the following new goals
- Proof step 141:
⟨skip⟩ (pq = pq0 ∧ bq = bq1 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
doWrite(tid0, bq0(tid0).head.l, bq0(tid0).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), pq = gs.pq, rfo = gs.rfo,
gs.bq(tid1) ≠ [], n < # gs.bq(tid1), FLITInv(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ n0. ¬ n0 < # gs.bq(tid1) ∨ ¬ isPropFO(n0, l, gs.bq(tid1))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, pq0, rfo0) ∧ ags0.writers = gs.fwriters
∧ (∀ t. labs(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf(t), pcf(t), ags0, alsf0(t), apcf0(t)))
Rule argument
Additional information
Proof step 141 from proof step-absstep-PROP_W-doWrite (previous step)
(back to tree)
| ⟨skip⟩ (pq = pq0 ∧ bq = bq1 ∧ rfo = rfo0), ags.ctr = gs.fctr, ags.mem = gs.pmem, ags.writers = gs.fwriters, bq = gs.bq,
doWrite(tid0, bq0(tid0).head.l, bq0(tid0).head.v) = (oneMember(tid1, l, gs.fwriters) ⊃ doWriteFO(tid1, l);propFO(tid1, l)), pq = gs.pq, rfo = gs.rfo,
gs.bq(tid1) ≠ [], n < # gs.bq(tid1), FLITInv(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf, pcf), FLITInv(gs, lsf, pcf), FLITPSCInv(ags, alsf, apcf),
isPropFO(n, l, gs.bq(tid1)), reorder(ags.p, gs.pq, gs.rfo), ∀ t. labs(gs, lsf(t), pcf(t), ags, alsf(t), apcf(t)),
∀ n0. ¬ n0 < # gs.bq(tid1) ∨ ¬ isPropFO(n0, l, gs.bq(tid1))
⊦ ∃ ags0, alsf0, apcf0.
(∃ t.
pre(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ ags0 = gstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))
∧ alsf0 = alsf(t := lstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v)))
∧ apcf0 = apcf(t := pcstepf(ags, alsf(t), apcf(t), doWritePSC(tid0, bq0(tid0).head.l, bq0(tid0).head.v))))
∧ ags0.mem = gs.pmem ∧ ags0.ctr = gs.fctr ∧ reorder(ags0.p, pq0, rfo0) ∧ ags0.writers = gs.fwriters
∧ (∀ t. labs(((gs.pq:= pq0).bq:= bq1).rfo:= rfo0, lsf(t), pcf(t), ags0, alsf0(t), apcf0(t))) |
Heuristic nonsplitting cut applied rule cut formula
And closed the goal!
Rule argument
fma: oneMember(tid1, l, gs.fwriters)
Additional information
Used simplifier rules:
⊦ doWrite(t, loc, v) ≠ propFO(t0, loc0); (s)
⊦ doWrite(t, loc, v) ≠ doWriteFO(t0, loc0); (s)
Used formulas: oneMember(tid1, l, gs.fwriters)
Proof Tree for step-absstep-PROP_W-doWrite
(View conclusion)
The following image shows the proof tree of sequent calculus. The
proved goal is at the bottom. You can click on the nodes to view
additional rules. See here for details on colors in a proof
tree.