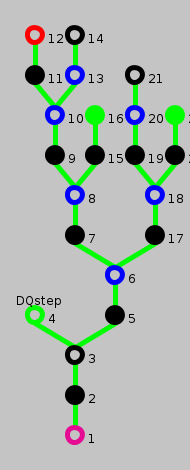
Proof Tree for DQstep-def0 (View conclusion)
The following image shows the proof tree of sequent calculus. The proved goal is at the bottom. You can click on the nodes to view additional rules. See here for details on colors in a proof tree.
| ⊦ DQstep(mkstate(gs, lsf, pcf), a, dqs0) ↔ (a = globalCrash ⊃ dqs0 = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ;∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ dqs0 = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) ) |
dqs0 = mkstate(gs0, lsf0, pcf0) ⊦ DQstep(mkstate(gs, lsf, pcf), a, dqs0) ↔ (a = globalCrash ⊃ dqs0 = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ;∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ dqs0 = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) )
Used simplifier rules: gen-DQState: ⊦ ;
| dqs0 = mkstate(gs0, lsf0, pcf0) ⊦ DQstep(mkstate(gs, lsf, pcf), a, dqs0) ↔ (a = globalCrash ⊃ dqs0 = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ;∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ dqs0 = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) ) |
⊦ DQstep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0)) ↔ (a = globalCrash ⊃ mkstate(gs0, lsf0, pcf0) = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ;∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) )
| ⊦ DQstep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0)) ↔ (a = globalCrash ⊃ mkstate(gs0, lsf0, pcf0) = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ;∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) ) |
⊦ DQstep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0)) ↔ (∃ tid, ls, pc. lstep(gs, lsf(tid), pcf(tid), a, gs0, ls, pc) ∧ lsf0 = lsf(tid; ls) ∧ pcf0 = pcf(tid; pc)) ∨ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf)
⊦ (∃ tid, ls, pc. lstep(gs, lsf(tid), pcf(tid), a, gs0, ls, pc) ∧ lsf0 = lsf(tid; ls) ∧ pcf0 = pcf(tid; pc)) ∨ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf) ↔ (a = globalCrash ⊃ mkstate(gs0, lsf0, pcf0) = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ;∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) )
Used terms: gs, lsf0, gs0, lsf, pcf0, a, pcf
| ⊦ DQstep(mkstate(gs, lsf, pcf), a, mkstate(gs0, lsf0, pcf0)) ↔ (∃ tid, ls, pc. lstep(gs, lsf(tid), pcf(tid), a, gs0, ls, pc) ∧ lsf0 = lsf(tid; ls) ∧ pcf0 = pcf(tid; pc)) ∨ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf) |
| ⊦ (∃ tid, ls, pc. lstep(gs, lsf(tid), pcf(tid), a, gs0, ls, pc) ∧ lsf0 = lsf(tid; ls) ∧ pcf0 = pcf(tid; pc)) ∨ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf) ↔ (a = globalCrash ⊃ mkstate(gs0, lsf0, pcf0) = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ;∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) ) |
⊦ (∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) ∨ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf) ↔ (a = globalCrash ⊃ mkstate(gs0, lsf0, pcf0) = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ;∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) )
Used simplifier rules: lstep: ⊦ lstep(gs, ls, pc, a, gs0, ls0, pc0) ↔ pre(gs, ls, pc, a) ∧ ls0 = lstepf(gs, ls, pc, a) ∧ gs0 = gstepf(gs, ls, pc, a) ∧ pc0 = pcstepf(gs, ls, pc, a);
| ⊦ (∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) ∨ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf) ↔ (a = globalCrash ⊃ mkstate(gs0, lsf0, pcf0) = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ;∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) ) |
(∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) ∨ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf) ⊦ (a = globalCrash ⊃ mkstate(gs0, lsf0, pcf0) = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ;∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) )
(a = globalCrash ⊃ mkstate(gs0, lsf0, pcf0) = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ;∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) ) ⊦ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))
| (∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) ∨ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf) ⊦ (a = globalCrash ⊃ mkstate(gs0, lsf0, pcf0) = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ;∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) ) |
pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a)) ∨ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf) ⊦ (a = globalCrash ⊃ mkstate(gs0, lsf0, pcf0) = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ;∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) )
| pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a)) ∨ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf) ⊦ (a = globalCrash ⊃ mkstate(gs0, lsf0, pcf0) = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ;∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) ) |
pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a)) ∨ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), a = globalCrash, mkstate(gs0, lsf0, pcf0) ≠ mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ⊦
pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a)) ∨ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), a ≠ globalCrash ⊦ ∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a)))
| pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a)) ∨ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), a = globalCrash, mkstate(gs0, lsf0, pcf0) ≠ mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ⊦ |
pre(gs, lsf(tid), pcf(tid), globalCrash) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), globalCrash) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), globalCrash)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), globalCrash)) ∨ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), mkstate(gs0, lsf0, pcf0) ≠ mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ⊦
| pre(gs, lsf(tid), pcf(tid), globalCrash) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), globalCrash) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), globalCrash)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), globalCrash)) ∨ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), mkstate(gs0, lsf0, pcf0) ≠ mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ⊦ |
gs0 = gstepf(gs, lsf(tid), pcf(tid), globalCrash), lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), globalCrash)), pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), globalCrash)), mkstate(gs0, lsf0, pcf0) ≠ mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)), pre(gs, lsf(tid), pcf(tid), globalCrash) ⊦
⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), mkstate(gs0, lsf0, pcf0) ≠ mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ⊦
| gs0 = gstepf(gs, lsf(tid), pcf(tid), globalCrash), lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), globalCrash)), pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), globalCrash)), mkstate(gs0, lsf0, pcf0) ≠ mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)), pre(gs, lsf(tid), pcf(tid), globalCrash) ⊦ |
mkstate (gstepf(gs, lsf(tid), pcf(tid), globalCrash), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), globalCrash)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), globalCrash))) ≠ mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)), pre(gs, lsf(tid), pcf(tid), globalCrash) ⊦
| mkstate (gstepf(gs, lsf(tid), pcf(tid), globalCrash), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), globalCrash)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), globalCrash))) ≠ mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)), pre(gs, lsf(tid), pcf(tid), globalCrash) ⊦ |
Used simplifier rules: gen-DQPC: ⊦ ; pre-crashed: ⊦ pre(gs, ls, crashed, a) ↔ false; pre-idle: ⊦ pre(gs, ls, idle, a) ↔ a = callRun(ls.tid); disj-callRun-globalCrash: ⊦ callRun(tid) ≠ globalCrash; pre-invDeq: ⊦ pre(gs, ls, invDeq, a) ↔ a = CheckEmp(ls.tid) ∧ gs.queue = [] ∨ a = DoDeqEmpty(ls.tid) ∧ ls.obsEmpty ∨ a = DoDeq(ls.tid) ∧ gs.queue ≠ []; disj-CheckEmp-globalCrash: ⊦ CheckEmp(tid) ≠ globalCrash; disj-DoDeqEmpty-globalCrash: ⊦ DoDeqEmpty(tid) ≠ globalCrash; disj-DoDeq-globalCrash: ⊦ DoDeq(tid) ≠ globalCrash; pre-invEnq: ⊦ pre(gs, ls, invEnq, a) ↔ a = DoEnq(ls.tid); disj-DoEnq-globalCrash: ⊦ DoEnq(tid) ≠ globalCrash; gstepf-ready: ⊦ gstepf(gs, ls, ready, a) = gs; pre-ready: ⊦ pre(gs, ls, ready, a) ↔ (∃ value. a = InvEnq(ls.tid, value)) ∨ a = InvDeq(ls.tid); disj-InvEnq-globalCrash: ⊦ InvEnq(tid, val) ≠ globalCrash; disj-InvDeq-globalCrash: ⊦ InvDeq(tid) ≠ globalCrash; pre-resDeq: ⊦ pre(gs, ls, resDeq, a) ↔ a = RetDeq(ls.tid, ls.oval); disj-RetDeq-globalCrash: ⊦ RetDeq(tid, optval) ≠ globalCrash; pre-resEnq: ⊦ pre(gs, ls, resEnq, a) ↔ a = RetEnq(ls.tid); disj-RetEnq-globalCrash: ⊦ RetEnq(tid) ≠ globalCrash;
| ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), mkstate(gs0, lsf0, pcf0) ≠ mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ⊦ |
⟨pcf := λ tid. (pcf(tid) = idle ⊃ idle;crashed)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), mkstate(gs0, lsf0, pcf0) ≠ mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ⊦
Used simplifier rules: Crash: ⊦ ;
| ⟨pcf := λ tid. (pcf(tid) = idle ⊃ idle;crashed)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), mkstate(gs0, lsf0, pcf0) ≠ mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ⊦ |
| pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a)) ∨ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), a ≠ globalCrash ⊦ ∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) |
a ≠ globalCrash, pre(gs, lsf(tid), pcf(tid), a) ⊦ ∃ tid0. pre(gs, lsf(tid0), pcf(tid0), a) ∧ mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) = mkstate(gstepf(gs, lsf(tid0), pcf(tid0), a), lsf(tid0; lstepf(gs, lsf(tid0), pcf(tid0), a)), pcf(tid0; pcstepf(gs, lsf(tid0), pcf(tid0), a)))
| a ≠ globalCrash, pre(gs, lsf(tid), pcf(tid), a) ⊦ ∃ tid0. pre(gs, lsf(tid0), pcf(tid0), a) ∧ mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) = mkstate(gstepf(gs, lsf(tid0), pcf(tid0), a), lsf(tid0; lstepf(gs, lsf(tid0), pcf(tid0), a)), pcf(tid0; pcstepf(gs, lsf(tid0), pcf(tid0), a))) |
Used terms: tid
| (a = globalCrash ⊃ mkstate(gs0, lsf0, pcf0) = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ;∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) ) ⊦ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a)) |
(a = globalCrash ⊃ mkstate(gs0, lsf0, pcf0) = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ; pre(gs, lsf(tid), pcf(tid), a) ∧ mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) ) ⊦ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))
| (a = globalCrash ⊃ mkstate(gs0, lsf0, pcf0) = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ; pre(gs, lsf(tid), pcf(tid), a) ∧ mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))) ) ⊦ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a)) |
a = globalCrash, mkstate(gs0, lsf0, pcf0) = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ⊦ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))
mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))), a ≠ globalCrash, pre(gs, lsf(tid), pcf(tid), a) ⊦ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))
| a = globalCrash, mkstate(gs0, lsf0, pcf0) = mkstate(gs, lsf, λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ⊦ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a)) |
pcf0 = (λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ⊦ ⟨Crash(; pcf)⟩ (pcf0 = pcf), ∃ tid. pre(gs, lsf(tid), pcf(tid), globalCrash) ∧ gs = gstepf(gs, lsf(tid), pcf(tid), globalCrash) ∧ lsf(tid) = lstepf(gs, lsf(tid), pcf(tid), globalCrash) ∧ (λ tid. (pcf(tid) = idle ⊃ idle;crashed)) = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), globalCrash))
Used simplifier rules: inj-mkstate: ⊦ mkstate(gstate, lsf, pcf) = mkstate(gstate0, lsf0, pcf0) ↔ gstate = gstate0 ∧ lsf = lsf0 ∧ pcf = pcf0;
| pcf0 = (λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ⊦ ⟨Crash(; pcf)⟩ (pcf0 = pcf), ∃ tid. pre(gs, lsf(tid), pcf(tid), globalCrash) ∧ gs = gstepf(gs, lsf(tid), pcf(tid), globalCrash) ∧ lsf(tid) = lstepf(gs, lsf(tid), pcf(tid), globalCrash) ∧ (λ tid. (pcf(tid) = idle ⊃ idle;crashed)) = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), globalCrash)) |
pcf0 = (λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ⊦ ⟨pcf := λ tid. (pcf(tid) = idle ⊃ idle;crashed)⟩ (pcf0 = pcf), ∃ tid. pre(gs, lsf(tid), pcf(tid), globalCrash) ∧ gs = gstepf(gs, lsf(tid), pcf(tid), globalCrash) ∧ lsf(tid) = lstepf(gs, lsf(tid), pcf(tid), globalCrash) ∧ (λ tid. (pcf(tid) = idle ⊃ idle;crashed)) = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), globalCrash))
Used simplifier rules: Crash: ⊦ ;
| pcf0 = (λ tid. (pcf(tid) = idle ⊃ idle;crashed)) ⊦ ⟨pcf := λ tid. (pcf(tid) = idle ⊃ idle;crashed)⟩ (pcf0 = pcf), ∃ tid. pre(gs, lsf(tid), pcf(tid), globalCrash) ∧ gs = gstepf(gs, lsf(tid), pcf(tid), globalCrash) ∧ lsf(tid) = lstepf(gs, lsf(tid), pcf(tid), globalCrash) ∧ (λ tid. (pcf(tid) = idle ⊃ idle;crashed)) = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), globalCrash)) |
| mkstate(gs0, lsf0, pcf0) = mkstate(gstepf(gs, lsf(tid), pcf(tid), a), lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)), pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a))), a ≠ globalCrash, pre(gs, lsf(tid), pcf(tid), a) ⊦ a = globalCrash ∧ ⟨Crash(; pcf)⟩ (gs0 = gs ∧ lsf0 = lsf ∧ pcf0 = pcf), ∃ tid. pre(gs, lsf(tid), pcf(tid), a) ∧ gs0 = gstepf(gs, lsf(tid), pcf(tid), a) ∧ lsf0 = lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) ∧ pcf0 = pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a)) |
a ≠ globalCrash, pre(gs, lsf(tid), pcf(tid), a) ⊦ ∃ tid0. pre(gs, lsf(tid0), pcf(tid0), a) ∧ gstepf(gs, lsf(tid), pcf(tid), a) = gstepf(gs, lsf(tid0), pcf(tid0), a) ∧ lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) = lsf(tid0; lstepf(gs, lsf(tid0), pcf(tid0), a)) ∧ pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a)) = pcf(tid0; pcstepf(gs, lsf(tid0), pcf(tid0), a))
Used simplifier rules: inj-mkstate: ⊦ mkstate(gstate, lsf, pcf) = mkstate(gstate0, lsf0, pcf0) ↔ gstate = gstate0 ∧ lsf = lsf0 ∧ pcf = pcf0;
| a ≠ globalCrash, pre(gs, lsf(tid), pcf(tid), a) ⊦ ∃ tid0. pre(gs, lsf(tid0), pcf(tid0), a) ∧ gstepf(gs, lsf(tid), pcf(tid), a) = gstepf(gs, lsf(tid0), pcf(tid0), a) ∧ lsf(tid; lstepf(gs, lsf(tid), pcf(tid), a)) = lsf(tid0; lstepf(gs, lsf(tid0), pcf(tid0), a)) ∧ pcf(tid; pcstepf(gs, lsf(tid), pcf(tid), a)) = pcf(tid0; pcstepf(gs, lsf(tid0), pcf(tid0), a)) |
Used terms: tid
The following image shows the proof tree of sequent calculus. The proved goal is at the bottom. You can click on the nodes to view additional rules. See here for details on colors in a proof tree.